A vector captures two pieces of information in a single mathematical object: how far and which way. This dual nature — part algebraic, part geometric — makes vectors the natural language for describing anything that requires both a size and an orientation. In R2 and R3, vectors are arrows that can be drawn, measured, and rotated. In Rn, they generalize beyond visual intuition into ordered lists of numbers that still obey the same algebraic rules. This section develops vectors from the ground up: what they are, how they behave, and the operations that give them structure.
For step-by-step results on your own numbers, use the vector calculators on CalculateMatrix.
What Is a Vector
One way to describe a displacement: draw an arrow, whose length is how far and whose direction is which way.
At its core, a vector is a mathematical object defined by two attributes: a magnitude (a non-negative number representing size) and a direction (an orientation in space). A scalar, by contrast, is fully specified by a single number — temperature, mass, or area require no directional component. A vector demands both.
Geometrically, a vector appears as a directed line segment: an arrow drawn from an initial point to a terminal point. The arrow's length encodes the magnitude, and the way it points encodes the direction. Two arrows that share the same length and orientation represent the same vector, regardless of where in space they are positioned. This is the concept of a free vector — identity is determined entirely by magnitude and direction, never by location.
Another way: list how far it goes along each axis.
"Three across, two up" is just the pair of numbers (3,2) — no drawing needed. In three dimensions the list has three numbers; in general it has n.
Arrows drawn in different places all turn into the same pair of numbers, (3, 2).
arrow from
to
across
up
as numbers
(0, 0)
(3, 2)
3
2
(3, 2)
(4, 1)
(7, 3)
3
2
(3, 2)
(−2, 5)
(1, 7)
3
2
(3, 2)
They had to agree: the numbers are exactly the arrow's movement along each axis, and nothing else.
Subtracting the tail from the tip gives the across and up amounts, so every arrow produces a list of numbers; walking those amounts from any starting point draws the arrow back. Where the arrow starts never enters — which is why the three arrows above are one vector.
The definition
A vector in Rn is an ordered list of n real numbers, its components; drawn in the plane or in space, it is an arrow with a length and a direction.
Algebraically, a vector in Rn is an ordered n-tuple of real numbers:
So v=(3,2) is the arrow "three across, two up", wherever it is drawn.
A vector is one object with two faces: a size-and-direction arrow and a list of components.
Fact: A photo is a single vector
A 12-megapixel colour photo stores three brightness values per pixel, for red, green and blue, so the whole picture is one vector in R36,000,000. Dimming it to half brightness is scalar multiplication by 21.
Each entry vi is called a component. In R2, a vector has two components and can be plotted on a coordinate plane. In R3, three components place it in three-dimensional space. For n>3, direct visualization is no longer possible, but the algebraic framework continues to function identically. The components of a vector encode both its magnitude and its direction numerically, linking the geometric and algebraic viewpoints into a single coherent object.
Which description to use: arrows to see, numbers to compute — and only numbers beyond three dimensions.
In the plane and in space, arrows show at a glance what addition or scaling does. Past three dimensions no arrow can be drawn, but the list of components works exactly the same way. The notation section shows the ways of writing both.
The rest of the page covers notation, types of vectors, their properties, the basic operations, magnitude, the dot and cross products, and linear combinations.
Notation and Representation
Notation
Notation and Representation
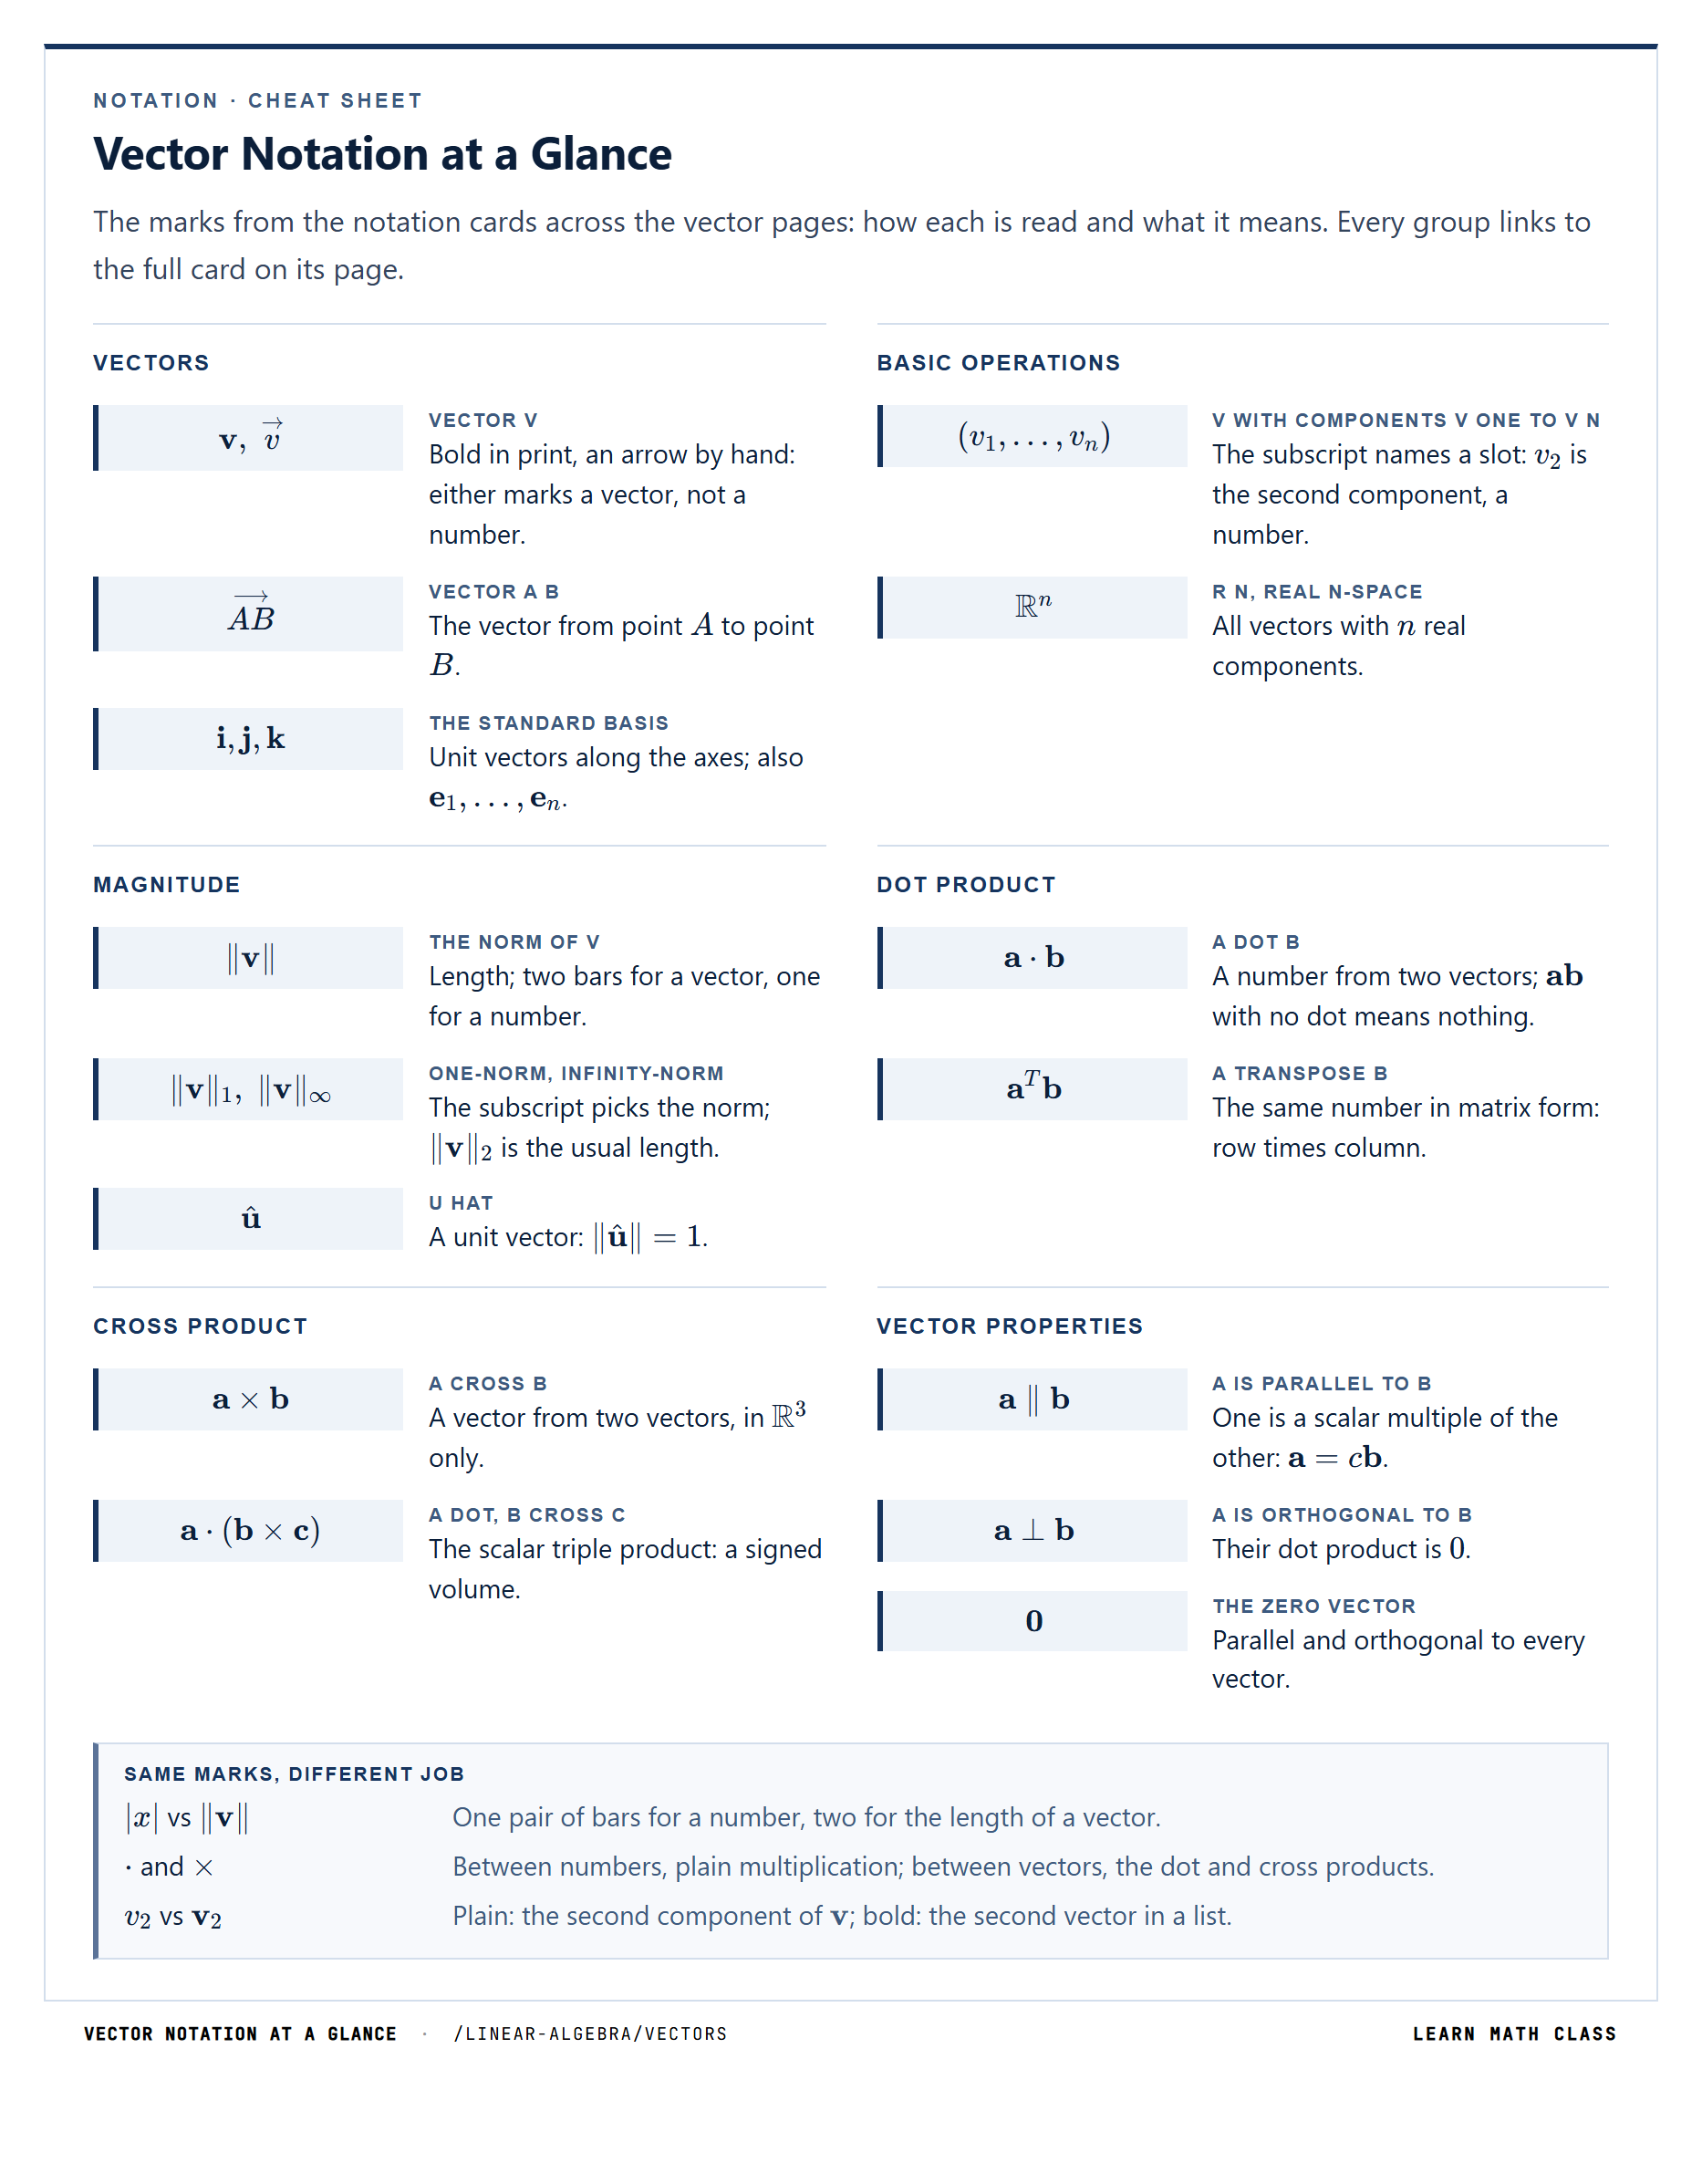
A bold letter or an arrow for the whole vector, a row or a column for its entries, and named unit vectors to build it from. All are catalogued among the linear algebra symbols.
Boldface lowercase is the printed standard. One bold letter stands for the whole list of components, so one vector equation says as much as n number equations.
CasesIn R3, a+b=c packs together a1+b1=c1, a2+b2=c2 and a3+b3=c3.
Also writtenv — the arrow is the handwritten form.
AB
vector A B
The vector from the point A to the point B: the notation records both the direction and the endpoints.
(v1,…,vn) · v1⋮vn
row form; column form
The same components listed horizontally or stacked vertically.
Do not confuseInterchangeable everywhere. With matrices the shape matters: matrix multiplication needs a column vector on the right.
i,j,k · e1,…,en
the standard basis vectors
Vectors with a 1 in one position and 0 elsewhere: i,j,k in R3, e1,…,en in general.
CasesAny vector decomposes along them: v=v1e1+v2e2+⋯+vnen — a linear combination with the components as weights.
Maxwell's 1865 theory of electromagnetism was written out component by component, 20 equations in all. In 1884 Heaviside rewrote it in vector notation, where one equation stands for three, and grouped it into the four Maxwell's equations known today.
Notation and Representation
v=(v1,v2,…,vn)
Notation and Representation
v=v1v2⋮vn
Notation and Representation
i=(1,0,0),j=(0,1,0),k=(0,0,1)
Types of Vectors
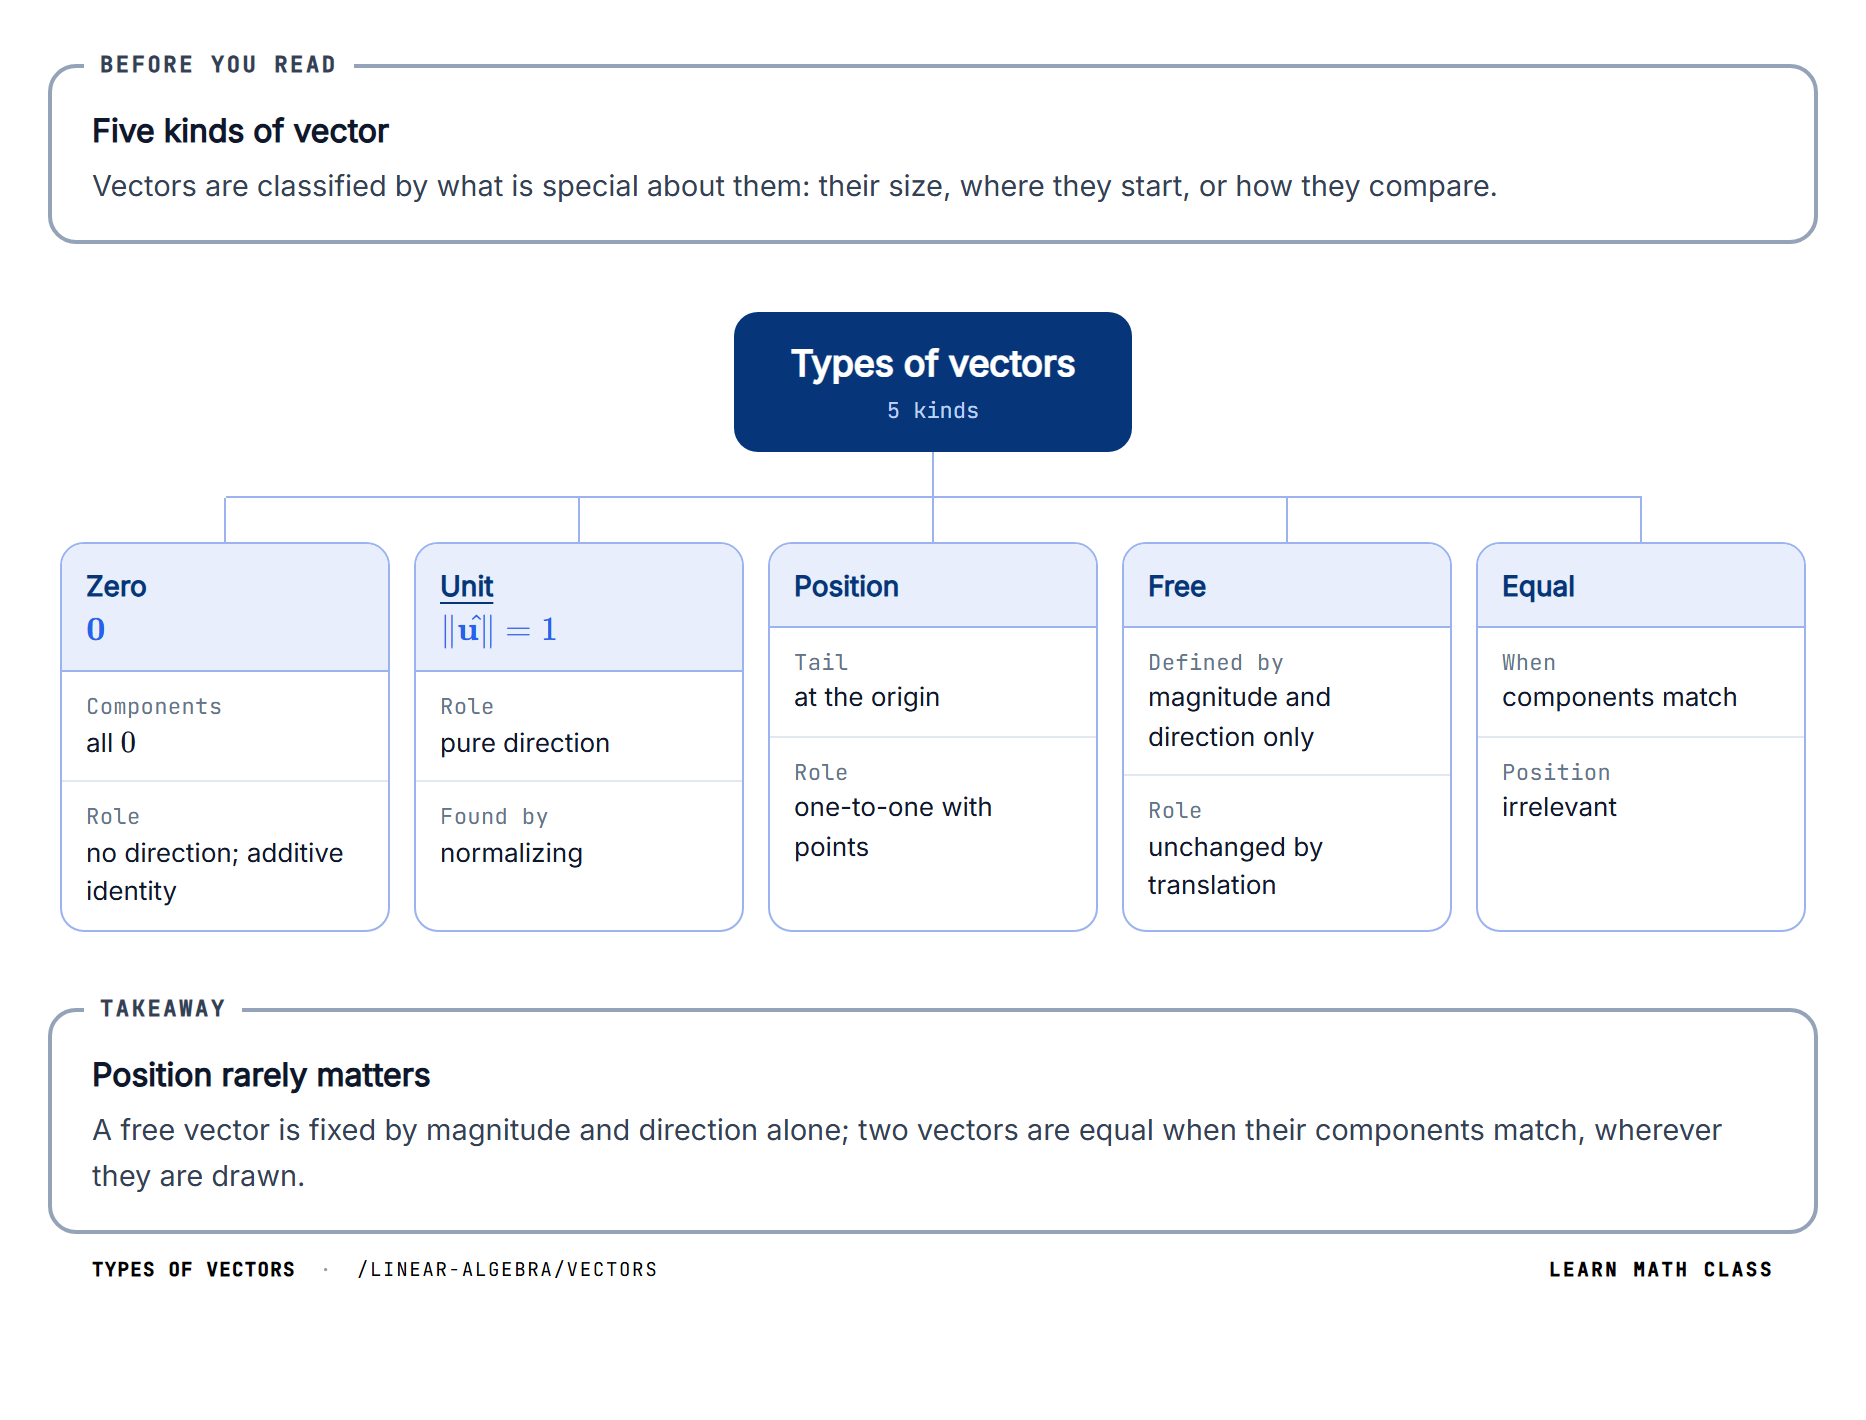
Not all vectors play the same role. Several categories appear repeatedly throughout linear algebra, and recognizing them early simplifies everything that follows.
The Zero Vector
The zero vector 0 has every component equal to zero. Its magnitude is 0, and it has no defined direction. Despite this, the zero vector is indispensable: it serves as the additive identity under vector addition, meaning v+0=v for every vector v.
Unit Vectors
A unit vector has magnitude exactly 1. It encodes pure direction with no scaling. The standard basis vectors are all unit vectors, but any nonzero vector can be converted into a unit vector through normalization — a process covered in detail on the magnitude page. Unit vectors are essential for isolating directional information from length.
Position Vectors
A position vector has its tail fixed at the origin and its head at a specific point in space. The vector p=(3,5) as a position vector points from the origin to the point (3,5). This convention establishes a one-to-one correspondence between points and vectors: every point in Rn corresponds to exactly one position vector, and every position vector identifies exactly one point.
Free Vectors
A free vector is defined solely by its magnitude and direction, with no attachment to a particular location. Translating a free vector to a different starting point does not change the vector. Two arrows in different parts of the plane that share the same length and orientation represent the same free vector. Most of the algebra in this section treats vectors as free — their behavior under operations depends only on their components, not on where they happen to be drawn.
Equal Vectors
Two vectors are equal when all their corresponding components match: a=b if and only if ai=bi for every i. Geometrically, equal vectors have the same magnitude and the same direction. Position plays no part — a vector drawn at one corner of a diagram is identical to a vector drawn at another corner, provided the components agree.
One vector, three places
The three blue arrows start at different points, yet each runs 3 across and 2 up — the dashed legs show it — so all three are the single vector v = (3, 2). The one whose tail sits at the origin is the position vector of the point (3, 2). The red arrow is exactly as long as v, but it runs 2 across and 3 up: a different direction, so a different vector.
Moving an arrow never changes the vector it represents; changing a component always does.
Every vector carries intrinsic attributes — magnitude, direction, and dimensionality — that exist independently of any operation. Magnitude measures how large a vector is, direction specifies where it points, and dimensionality records how many components it contains. These are not consequences of addition or multiplication; they belong to the vector itself.
Beyond what individual vectors possess, vectors also relate to one another through structural relationships. Two vectors are equal when their components match exactly. They are parallel when one is a scalar multiple of the other, meaning they share the same or opposite direction. They are orthogonal when their dot product equals zero, indicating that they meet at a right angle in the geometric interpretation.
The properties page collects both the intrinsic and relational attributes in a single reference, with each property developed fully on the page where it naturally belongs.
Basic Vector Operations
Three operations form the algebraic backbone of everything in this section: addition, subtraction, and scalar multiplication. Each operates component by component, each produces a vector in the same Rn, and each has a geometric interpretation that reinforces the algebra.
Vector addition combines two vectors into a third by summing their corresponding components. Geometrically, this is the tip-to-tail construction — place the tail of the second vector at the head of the first, and the sum runs from the starting tail to the ending head. The parallelogram method provides an equivalent picture: the sum is the diagonal of the parallelogram formed by the two vectors.
Subtraction reverses the process: a−b adds a to the negation of b, producing the vector that points from the tip of b to the tip of a.
Scalar multiplication scales a vector by a real number. Multiplying by a positive scalar stretches or compresses the vector without changing its direction; multiplying by a negative scalar also reverses it. These three operations satisfy a collection of algebraic rules — commutativity, associativity, distributivity — that make structured computation possible.
Addition finished, component by component
Addition, subtraction and scaling all share this shape: the operation is applied to each slot on its own and the slots never talk to each other. That is why addition and subtraction need two vectors of the same length, why scaling acts on a single vector, and why all three return a vector of that same length. See the same run for subtraction on the vector addition visualizer.
The products that follow break this pattern deliberately — both of them mix components together rather than keeping them apart.
Magnitude and the Norm
The magnitude of a vector quantifies its length as a single non-negative number. In R2, this is the hypotenuse of the right triangle formed by the components. In R3, the same idea extends through a second application of the Pythagorean theorem. The general formula for any Rn is:
Magnitude and the Norm
∥v∥=v12+v22+⋯+vn2
Pitfall: Adding the lengths
Taking ∥a+b∥ to be ∥a∥+∥b∥ gives 3+4=7 for a=(3,0) and b=(0,4). But a+b=(3,4), whose length is 9+16=5.
This quantity is called the Euclidean norm, and it satisfies three fundamental properties: it is never negative, it scales predictably under scalar multiplication (∥cv∥=∣c∣∥v∥), and it obeys the triangle inequality (∥a+b∥≤∥a∥+∥b∥).
The norm also provides a natural notion of distance: the distance between two vectors a and b is ∥a−b∥. Closely tied to magnitude is the concept of a unit vector — a vector whose norm equals 1. Any nonzero vector can be rescaled to unit length through normalization, a process that extracts pure direction by dividing out the magnitude.
The Dot Product
The dot product is the first operation in this section that does not return a vector. It takes two vectors and produces a scalar, computed by multiplying corresponding components and summing the results:
The Dot Product
a⋅b=a1b1+a2b2+⋯+anbn
Pitfall: Keeping the products as a vector
Stopping after the multiplications turns (1,2,3)⋅(4,−5,6) into the vector (4,−10,18). The products must be added: 4−10+18=12, a single number.
This algebraic formula has a geometric equivalent: a⋅b=∥a∥∥b∥cosθ, where θ is the angle between the two vectors. The geometric form reveals what the dot product actually measures — how much two vectors align directionally. When the dot product is positive, the vectors point roughly the same way. When it is negative, they point roughly in opposite directions. When it equals zero, the vectors are orthogonal: perpendicular in the geometric sense.
This connection to angles makes the dot product the gateway to projection: decomposing one vector into a component along another and a component perpendicular to it.
The dot product turns the angle between two vectors into plain arithmetic on their components.
The Cross Product
Where the dot product takes two vectors and returns a scalar, the cross product takes two vectors and returns a new vector. This returned vector is perpendicular to both inputs, giving the cross product a geometric role that the dot product cannot fill: it finds directions orthogonal to a given plane.
The cross product is defined exclusively in R3. For vectors a=(a1,a2,a3) and b=(b1,b2,b3):
Pitfall: Flipping the sign of the middle component
Writing the middle entry as a1b3−a3b1 turns (1,2,3)×(4,5,6) into (−3,−6,−3), which is not perpendicular to (1,2,3). The middle entry is a3b1−a1b3=12−6=6, so the product is (−3,6,−3).
The magnitude ∥a×b∥=∥a∥∥b∥sinθ equals the area of the parallelogram that the two vectors span. The direction is determined by the right-hand rule, which introduces the concept of orientation — a handedness to three-dimensional space that has no analogue in the dot product. Unlike most operations encountered so far, the cross product is anti-commutative: swapping the order of the inputs reverses the direction of the result.
Linear Combinations
Every operation covered so far — addition, subtraction, scalar multiplication — is a special case of a single unifying idea: the linear combination. Given vectors v1,v2,…,vk and scalars c1,c2,…,ck, the expression
is a linear combination of those vectors. Adding two vectors is the special case where k=2 and both scalars equal 1. Scalar multiplication is the case k=1.
Each card fixes the number of vectors k, and the scalars where needed, and shows which earlier operation the combination becomes.
Adding two vectors is the special case where k=2 and both scalars equal 1.
Setk=1
c1v1
Scalar multiplication
Scalar multiplication is the case k=1.
Earlier operations as linear combinationsLearn Math Class
Addition and scalar multiplication are both linear combinations; only k and the scalars are fixed in advance.
The set of all possible linear combinations of a given collection of vectors is called the span of that collection. The span of a single nonzero vector is a line through the origin. The span of two non-parallel vectors is a plane. The span of three non-coplanar vectors in R3 fills the entire space. Asking whether a particular vector lies in the span of a given set turns out to be equivalent to asking whether a certain system of equations has a solution — a connection that links vectors directly to the machinery of matrices and row reduction.
Linear combinations also set the stage for two concepts developed in the vector spaces section: linear independence, which identifies when no vector in a set is redundant, and basis, which captures the minimal spanning set needed to reach every point in a space.
Every vector built by scaling and adding lies in the span, and testing membership means solving a linear system.
Summary: All Vector Operations at a Glance
This summary lists the seven vector operations of the page, one per row. Each row names the operation, gives its formula and says what it takes in and what it returns, with a line under the name on its geometric meaning and a link to the section that explains it.
Addition, subtraction and scalar multiplication work component by component and return a vector of the same size. The magnitude turns one vector into a length, the dot product turns two vectors into a single number, and the cross product, defined only in three dimensions, returns a vector perpendicular to both. The linear combination closes the list as the idea behind all of them.
Before using an operation, check what it returns. Sums, differences, scalar multiples and cross products are vectors, while the magnitude and the dot product are plain numbers, and mixing the two up is behind many wrong answers with vectors.
Common Pitfalls
Three slips come up again and again when these operations are first met. Each one is marked where it happens in the sections above; here each is worked through in full, with the wrong and the right working side by side.
The length of a sum is found by adding the lengths of the two vectors, as if magnitudes combined the way the vectors do.
Start
For a=(3,0) and b=(0,4),
Wrong turn
Error here
∥a+b∥=∥a∥+∥b∥=3+4=7
Right path
Add the vectors first, then take the length.
a+b=(3,4),
∥a+b∥=9+16=5
The triangle inequality only promises 5≤7. The two sides are equal only when one vector is a non-negative multiple of the other.
Why it happensFor numbers of the same sign, ∣x+y∣=∣x∣+∣y∣, and the same habit is carried over to vectors that point in different directions.
How to checkDraw the two vectors tip-to-tail. Here they form the legs of a 3–4–5 right triangle, and the sum is the hypotenuse, shorter than the two legs together.
2Keeping the products as a vector
The dot product is computed by multiplying corresponding components, and the work stops there, leaving a vector instead of a number.
Wrong turn
Error here
(1,2,3)⋅(4,−5,6)=(4,−10,18)
Right path
The products are added.
(1,2,3)⋅(4,−5,6)
=4−10+18=12
Why it happensAddition, subtraction and scalar multiplication all work slot by slot and return a vector, so the first step of the dot product looks like one more operation of the same kind.
How to checkThe dot product is always a single number. Dotting a vector with itself must give its squared length: (1,2,3)⋅(1,2,3)=1+4+9=14=∥(1,2,3)∥2.
3Flipping the sign of the middle component
The middle component of the cross product is written as a1b3−a3b1 instead of a3b1−a1b3. In the determinant layout with i, j, k, this is the minus sign in front of the j term being dropped.
Start
For a=(1,2,3) and b=(4,5,6),
Wrong turn
Error here
Component by component,
first: 2⋅6−3⋅5=−3
middle: 1⋅6−3⋅4=−6
last: 1⋅5−2⋅4=−3
a×b=(−3,−6,−3)
Right path
Component by component,
first: 2⋅6−3⋅5=−3
middle: 3⋅4−1⋅6=6
last: 1⋅5−2⋅4=−3
a×b=(−3,6,−3)
Why it happensThe first and third components open with the smaller index on a, a2b3 and a1b2, and the middle one is written the same way, opening with a1b3. The components actually follow the cyclic order 1→2→3→1, which puts a3b1 first in the middle.
How to checkThe result must be perpendicular to both inputs. (−3,6,−3)⋅(1,2,3)=−3+12−9=0 and (−3,6,−3)⋅(4,5,6)=−12+30−18=0. The wrong answer gives (−3,−6,−3)⋅(1,2,3)=−24, not 0.
Each slip combines vectors with the wrong rule. Lengths do not add, a dot product is a single number, and the middle component of a×b is a3b1−a1b3. Drawing the vectors tip-to-tail, dotting a vector with itself, or checking that a cross product is perpendicular to both inputs catches each slip.
Skills You Should Learn
Each skill opens its step-by-step method page.
Vector methods
Compute the cross productExpand a 3×3 determinant with i, j, k in the top row; mind the minus sign on the middle term.
Compute the dot productMultiply matching components and add; or use the two lengths and the angle between them.
Yes. A vector in Rn is an ordered list of n real numbers, and nothing limits n. A 12-megapixel colour photo stores a red, a green and a blue value for every pixel, so the whole picture is one vector in R36,000,000. No arrow can be drawn past three dimensions, but the algebra works exactly the same: dimming the photo to half brightness is multiplying that vector by 21.Read more →
Why is a whole vector written as one bold letter?
+
Because one symbol then stands for the whole list of components, so one vector equation says as much as n equations between numbers. In R3, a+b=c packs together a1+b1=c1, a2+b2=c2 and a3+b3=c3. The saving is large: Maxwell's theory of electromagnetism filled 20 equations written component by component, and Heaviside's vector notation regrouped it into the four Maxwell's equations known today. By hand, an arrow v replaces the bold.Read more →
Does it matter whether a vector is written as a row or a column?
+
Not for the vector itself: (v1,…,vn) and the same entries stacked vertically are the same vector, and the two forms are interchangeable in sums, scaling, lengths and products. The shape starts to matter once matrices enter. In a matrix-vector product Av the vector must be a column standing to the right of the matrix, and the dot product in matrix form, aTb, is a row times a column.Read more →
What do vector addition, subtraction and scalar multiplication have in common?
+
All three work component by component: the operation is applied to each slot on its own, and the slots never interact. That is why adding or subtracting needs two vectors of the same length, and why all three return a vector in the same Rn. All three are also special cases of a linear combination c1v1+⋯+ckvk. The dot and cross products break this pattern on purpose: both mix the components together.Read more →
Which vector operations give a number instead of a vector?
+
Two of them: the magnitude ∥v∥, which is never negative, and the dot product a⋅b, which can be positive, negative or zero. Addition, subtraction, scalar multiplication and linear combinations return a vector, and so does the cross product, though it exists only in R3. A common slip is stopping the dot product after the multiplications: (1,2,3)⋅(4,−5,6) is 4−10+18=12, not the vector (4,−10,18).Read more →
How can you check a cross product answer?
+
Dot the result with both inputs: each dot product must be 0, because a×b is perpendicular to both a and b. For (1,2,3)×(4,5,6)=(−3,6,−3) the checks give −3+12−9=0 and −12+30−18=0. The usual error is in the middle component, which is a3b1−a1b3; writing a1b3−a3b1 gives (−3,−6,−3), whose dot product with (1,2,3) is −24.Read more →