Visual Tools
Calculators
Tables
Mathematical Keyboard
Converters
Other Tools


Span


Everything Reachable by Linear Combinations

The span of a set of vectors is the collection of all their linear combinations — every vector that can be built by adding scaled copies of the given vectors. It is always a subspace, and it is the smallest subspace containing the original set. Span is the other half of what makes a basis: the half that guarantees complete coverage.


Definition

Given vectors v1,v2,,vk\mathbf{v}_1, \mathbf{v}_2, \dots, \mathbf{v}_k in a vector space VV, their span is the set of all linear combinations:

Span (Set Definition)
Span{v1,,vk}={c1v1+c2v2++ckvkciF}\text{Span}\{\mathbf{v}_1, \ldots, \mathbf{v}_k\} = \left\{c_1\mathbf{v}_1 + c_2\mathbf{v}_2 + \cdots + c_k\mathbf{v}_k \mid c_i \in \mathbb{F}\right\}
Learn more about this formula: Span (Set Definition) →


Every choice of scalars c1,,ckc_1, \dots, c_k produces one vector in the span. As the scalars range over all real numbers, the span sweeps out an entire subspace of VV.

The span is always a subspace — in fact, the smallest subspace of VV that contains all of v1,,vk\mathbf{v}_1, \dots, \mathbf{v}_k:

Span Is Smallest Subspace
Span(K)=W subspaceKWW\text{Span}(K) = \bigcap_{\substack{W \text{ subspace} \\ K \subseteq W}} W
Learn more about this formula: Span Is Smallest Subspace →


Adding two linear combinations of these vectors produces another linear combination, and scaling a linear combination by a scalar produces another, so both closure conditions hold automatically.

By convention, the span of the empty set is {0}\{\mathbf{0}\}. With no vectors to combine, the only reachable point is the zero vector (the combination with no terms).

Span Notation

Notation

Span Notation

Braces or parentheses after the operator, the angle-bracket rival from algebra, and the hollow letter that stands for whichever field you brought.
Bold vectors, subscripts and Rn\mathbb{R}^nvector notation; the set braces and the such-that bar — set notation.
Span{v1,,vk}\text{Span}\{\mathbf{v}_1, \ldots, \mathbf{v}_k\} · Span(K)\text{Span}(K)
The span of the vectors; the span of the set K
Two delimiter habits for one operator, both in the Definition above: braces when the vectors are listed — the braces literally build the set being spanned — and parentheses when the set already has a name. Lowercase span\operatorname{span} and capitalized Span\text{Span} circulate equally.
CasesThe convention pays off at the edge: Span{}={0}\text{Span}\{\} = \{\mathbf{0}\} reads cleanly — the braces show the empty list, and the answer is the zero subspace, not the empty set.
Also writtenspan(v1,,vk)\operatorname{span}(\mathbf{v}_1, \ldots, \mathbf{v}_k) — parentheses around a list, common in applied texts; harmless, since the operator deduplicates anyway.
Do not confuseThe set itself. {v1,v2}\{\mathbf{v}_1, \mathbf{v}_2\} has two elements; Span{v1,v2}\text{Span}\{\mathbf{v}_1, \mathbf{v}_2\} has infinitely many — dropping the operator collapses a plane to two points.
v1,,vk\langle \mathbf{v}_1, \ldots, \mathbf{v}_k \rangle
The subspace generated by the vectors
The algebraist's spelling: angle brackets for “generated by”, imported from group and ring theory where g\langle g \rangle generates a subgroup. Same object as the span — different tribe.
CasesLinear algebra texts mostly avoid it for exactly one reason: the same brackets carry the inner product u,v\langle \mathbf{u}, \mathbf{v} \rangle — and with two vectors inside, u,v\langle \mathbf{u}, \mathbf{v} \rangle is genuinely ambiguous between a subspace and a scalar.
Also writtenK\langle K \rangle for a whole set, mirroring Span(K)\text{Span}(K).
Do not confuseAngle-bracket components 3,4\langle 3, 4 \rangle from American calculus texts — a third job for the same brackets, noted at vector notation. Three meanings, one glyph pair: components, span, inner product.
ciFc_i \in \mathbb{F}
The scalars come from the field F
Hollow F\mathbb{F} is a placeholder: whatever field the space is built overR\mathbb{R} in this section, C\mathbb{C} in complex spaces. Writing F\mathbb{F} instead of R\mathbb{R} signals that nothing in the statement depends on which one.
CasesThe definition above quietly uses it: scalars range over F\mathbb{F}, so the same line defines real and complex spans at once. Concrete pages instantiate it; abstract ones leave it hollow.
Also writtenKK or kk — the algebraists' field letters (from German Körper); Fp\mathbb{F}_p with a subscript names the finite fields.
Do not confuseA specific number system. F\mathbb{F} joins the blackboard family N,Z,Q,R,C\mathbb{N}, \mathbb{Z}, \mathbb{Q}, \mathbb{R}, \mathbb{C} — but unlike them it names no fixed set; it is a variable wearing the family's typeface.

Geometric Interpretation

In R2\mathbb{R}^2 and R3\mathbb{R}^3, the span of a set of vectors is a flat subspace whose shape depends on how many independent vectors the set contains.

The span of a single nonzero vector v\mathbf{v} is the line {tv:tR}\{t\mathbf{v} : t \in \mathbb{R}\} — a one-dimensional subspace passing through the origin in the direction of v\mathbf{v}.

The span of two non-parallel vectors is a plane through the origin — a two-dimensional subspace. If the two vectors happen to be parallel, one is a scalar multiple of the other, and the span collapses to a line.

The span of three vectors in R3\mathbb{R}^3 that do not all lie in a single plane is all of R3\mathbb{R}^3. If the three vectors are coplanar, the span is a plane. If two of the three are parallel, the span may be only a line.

The pattern is consistent: the dimension of the span equals the number of independent vectors in the set, regardless of how many total vectors are present. Redundant vectors — those already in the span of the others — add nothing to the reach.
Set in ℝⁿ Span dimension Geometric shape Note
1 nonzero vector 1 line through the origin basis for the line
2 parallel vectors 1 line through the origin one is a scalar multiple of the other — the pair is redundant
2 non-parallel vectors 2 plane through the origin basis for the plane
3 coplanar vectors in ℝ³ 2 plane through the origin the third vector lies in the span of two — redundant
3 non-coplanar vectors in ℝ³ 3 all of ℝ³ basis for ℝ³
φabspan = ℝ²φabspan = line
A span filling the plane, then collapsing to a line

Above, the shaded region reaches every point because the two arrows supply two genuinely different directions. Below, the second arrow lies along the first, and the span has shrunk to the line they share — two vectors, but only one direction between them. What a span can reach is fixed by directions, never by how many vectors are listed. Drag the arrows and watch the region change on the span and independence explorer.

Line, plane or the whole space — the span is always one of these, and it always contains the origin.

Spanning Sets

A set of vectors spans a vector space VV if Span{v1,,vk}=V\text{Span}\{\mathbf{v}_1, \dots, \mathbf{v}_k\} = V — every vector in VV can be written as a linear combination of the set. When this holds, the set is called a spanning set for VV.

In Rn\mathbb{R}^n, a spanning set must contain at least nn vectors. Fewer than nn vectors cannot reach every direction — their span is a proper subspace of dimension less than nn. A spanning set with exactly nn independent vectors is a basis. A spanning set with more than nn vectors contains redundancies that can be removed.

The standard basis {e1,,en}\{\mathbf{e}_1, \dots, \mathbf{e}_n\} spans Rn\mathbb{R}^n with no redundancy. The set {e1,e2,e1+e2}\{\mathbf{e}_1, \mathbf{e}_2, \mathbf{e}_1 + \mathbf{e}_2\} also spans R2\mathbb{R}^2, but the third vector is redundant — it lies in the span of the first two. Removing it leaves a basis.

Testing Whether a Vector Is in a Span

The question "Is b\mathbf{b} in Span{v1,,vk}\text{Span}\{\mathbf{v}_1, \dots, \mathbf{v}_k\}?" asks whether there exist scalars c1,,ckc_1, \dots, c_k such that c1v1++ckvk=bc_1\mathbf{v}_1 + \cdots + c_k\mathbf{v}_k = \mathbf{b}. This is a linear system: arrange the vectors as columns of a matrix A=[v1    vk]A = [\mathbf{v}_1 \; \cdots \; \mathbf{v}_k] and check whether Ac=bA\mathbf{c} = \mathbf{b} is consistent:

Span Membership Criterion
bSpan{v1,,vk}    Ac=b is consistent\mathbf{b} \in \text{Span}\{\mathbf{v}_1, \ldots, \mathbf{v}_k\} \iff A\mathbf{c} = \mathbf{b} \text{ is consistent}
Learn more about this formula: Span Membership Criterion →


Row reduce the augmented matrix [Ab][A \mid \mathbf{b}]. If a row of the form [0  0    0d][0 \; 0 \; \cdots \; 0 \mid d] with d0d \neq 0 appears, the system is inconsistent and b\mathbf{b} is not in the span.

Example: In the Span


Is b=(5,3,7)\mathbf{b} = (5, 3, 7) in Span{(1,0,1),(0,1,2)}\text{Span}\{(1, 0, 1), (0, 1, 2)\}? Form and reduce:

(105013127)R3R1(105013022)R32R2(105013004)\begin{pmatrix} 1 & 0 & 5 \\ 0 & 1 & 3 \\ 1 & 2 & 7 \end{pmatrix} \xrightarrow{R_3 - R_1} \begin{pmatrix} 1 & 0 & 5 \\ 0 & 1 & 3 \\ 0 & 2 & 2 \end{pmatrix} \xrightarrow{R_3 - 2R_2} \begin{pmatrix} 1 & 0 & 5 \\ 0 & 1 & 3 \\ 0 & 0 & -4 \end{pmatrix}


The last row reads 0=40 = -4, a contradiction. So b\mathbf{b} is not in the span.

Example: Not in the Span Versus In the Span


Changing the target to b=(5,3,11)\mathbf{b} = (5, 3, 11) and repeating:

(1050131211)R3R1(105013026)R32R2(105013000)\begin{pmatrix} 1 & 0 & 5 \\ 0 & 1 & 3 \\ 1 & 2 & 11 \end{pmatrix} \xrightarrow{R_3 - R_1} \begin{pmatrix} 1 & 0 & 5 \\ 0 & 1 & 3 \\ 0 & 2 & 6 \end{pmatrix} \xrightarrow{R_3 - 2R_2} \begin{pmatrix} 1 & 0 & 5 \\ 0 & 1 & 3 \\ 0 & 0 & 0 \end{pmatrix}


No contradiction. The solution is c1=5c_1 = 5, c2=3c_2 = 3, so (5,3,11)=5(1,0,1)+3(0,1,2)(5, 3, 11) = 5(1, 0, 1) + 3(0, 1, 2).
[V | w]3×3102013115rref3×3102013000
Solving for the weights that reach b

The candidate vector has been placed as the right-hand side and the spanning vectors as the columns, turning "is b in the span" into a system to solve. A consistent system means a set of weights exists and b is reachable; an inconsistent one means no combination lands on it. Try a vector that misses, and watch the contradiction row appear, on the span membership tester.

Every later question about spanning sets reduces to running this same test on a different right-hand side.

Testing Whether a Set Spans Rⁿ

The question "Does {v1,,vk}\{\mathbf{v}_1, \dots, \mathbf{v}_k\} span Rn\mathbb{R}^n?" asks whether Ac=bA\mathbf{c} = \mathbf{b} is consistent for every possible right-hand side bRn\mathbf{b} \in \mathbb{R}^n, where AA is the matrix with the vectors as columns.

Row reduce AA. The columns span Rn\mathbb{R}^n if and only if every row of the echelon form contains a pivot. If any row is entirely zero, then for some choices of b\mathbf{b} the augmented system will produce a [0    0d][0 \; \cdots \; 0 \mid d] contradiction, meaning those b\mathbf{b} are unreachable.

For the square case — nn vectors in Rn\mathbb{R}^n — spanning reduces to a determinant test: the columns span Rn\mathbb{R}^n if and only if det(A)0\det(A) \neq 0. This is equivalent to independence when the count matches the dimension, which is why the spanning and independence conditions coincide for sets of exactly nn vectors in Rn\mathbb{R}^n.

Fewer than nn vectors can never span Rn\mathbb{R}^n. An n×kn \times k matrix with k<nk < n has at most kk pivots, so at least nkn - k rows of the echelon form will be zero. More than nn vectors can span Rn\mathbb{R}^n, but only if the set contains at least nn independent vectors among them — the extras are redundant.

Span and Column Space

The column space of a matrix AA is exactly the span of its columns:

Col(A)=Span{a1,a2,,an}\text{Col}(A) = \text{Span}\{\mathbf{a}_1, \mathbf{a}_2, \dots, \mathbf{a}_n\}


This identity connects the abstract concept of span to the concrete question of system solvability. The system Ax=bA\mathbf{x} = \mathbf{b} has a solution if and only if b\mathbf{b} lies in the column space of AA — that is, if and only if b\mathbf{b} is in the span of the columns.

The rank of AA equals the dimension of the column space, which equals the number of independent columns. The pivot columns of the echelon form identify which original columns form a basis for the column space. The non-pivot columns are redundant — they lie in the span of the pivot columns.

This also explains why row reduction is the universal computational tool for span questions. Every question about span — membership, spanning, independence — translates into a question about the column space of some matrix, and row reduction answers all of them.

Redundancy and Reduction

A spanning set may contain more vectors than necessary. A vector vj\mathbf{v}_j in a spanning set is redundant if removing it does not shrink the span:

Span{v1,,vk}=Span{v1,,vj1,vj+1,,vk}\text{Span}\{\mathbf{v}_1, \dots, \mathbf{v}_k\} = \text{Span}\{\mathbf{v}_1, \dots, \mathbf{v}_{j-1}, \mathbf{v}_{j+1}, \dots, \mathbf{v}_k\}


This happens exactly when vj\mathbf{v}_j is already a linear combination of the other vectors — it contributes no new directions.

Removing all redundant vectors from a spanning set produces a basis: a minimal spanning set with no waste. The process can be carried out systematically via row reduction. Arrange the vectors as columns, reduce, and identify the pivot columns. The original vectors corresponding to pivot positions form a basis for the span. The non-pivot columns are the redundant ones.

For example, if four vectors in R3\mathbb{R}^3 are given and row reduction reveals pivots in columns 11, 22, and 44, then the original first, second, and fourth vectors form a basis for the span. The third vector is a combination of the first two.

This reduction process is always possible in finite-dimensional spaces: every spanning set can be trimmed to a basis, and every independent set can be extended to one. The basis sits at the exact boundary between "too few vectors to span" and "too many vectors to be independent."

Span in Abstract Vector Spaces

The definition of span — the set of all linear combinations — applies in any vector space, not just Rn\mathbb{R}^n.

In the polynomial space P2\mathcal{P}_2, the span of {1,x,x2}\{1, x, x^2\} is all of P2\mathcal{P}_2, since every polynomial a+bx+cx2a + bx + cx^2 of degree at most 22 is a linear combination of these three. The set is independent and has the right count (3=dim(P2)3 = \dim(\mathcal{P}_2)), so it is the standard basis.

A subtler example is Span{1,sin2x,cos2x}\text{Span}\{1, \sin^2 x, \cos^2 x\} in the space of continuous functions. This set has three elements, but the identity sin2x+cos2x=1\sin^2 x + \cos^2 x = 1 provides a dependence relation: 11+(1)sin2x+(1)cos2x=01 \cdot 1 + (-1)\sin^2 x + (-1)\cos^2 x = 0. The span is therefore two-dimensional, not three-dimensional. Any two of the three functions form a basis for the span — the third is redundant.

In abstract spaces, the column-matrix approach is unavailable. Testing whether a specific vector lies in a span, or whether a set spans the whole space, requires working directly from the definition: write the target as a combination and check whether the resulting equation has a solution. The algebraic structure of the particular space — polynomial coefficients, function identities, matrix entries — determines how this check proceeds.
Vector space Spanning set Result Reason
𝒫₂ (polynomials of degree ≤ 2) {1, x, x²} spans all of 𝒫₂; dimension 3 three independent vectors — no relations among them; standard basis
C(ℝ) (continuous real-valued functions) {1, sin²x, cos²x} spans a 2-dimensional subspace the identity sin²x + cos²x = 1 forces 1 to be a combination of the others

Summary: Diagnostic Questions about Span

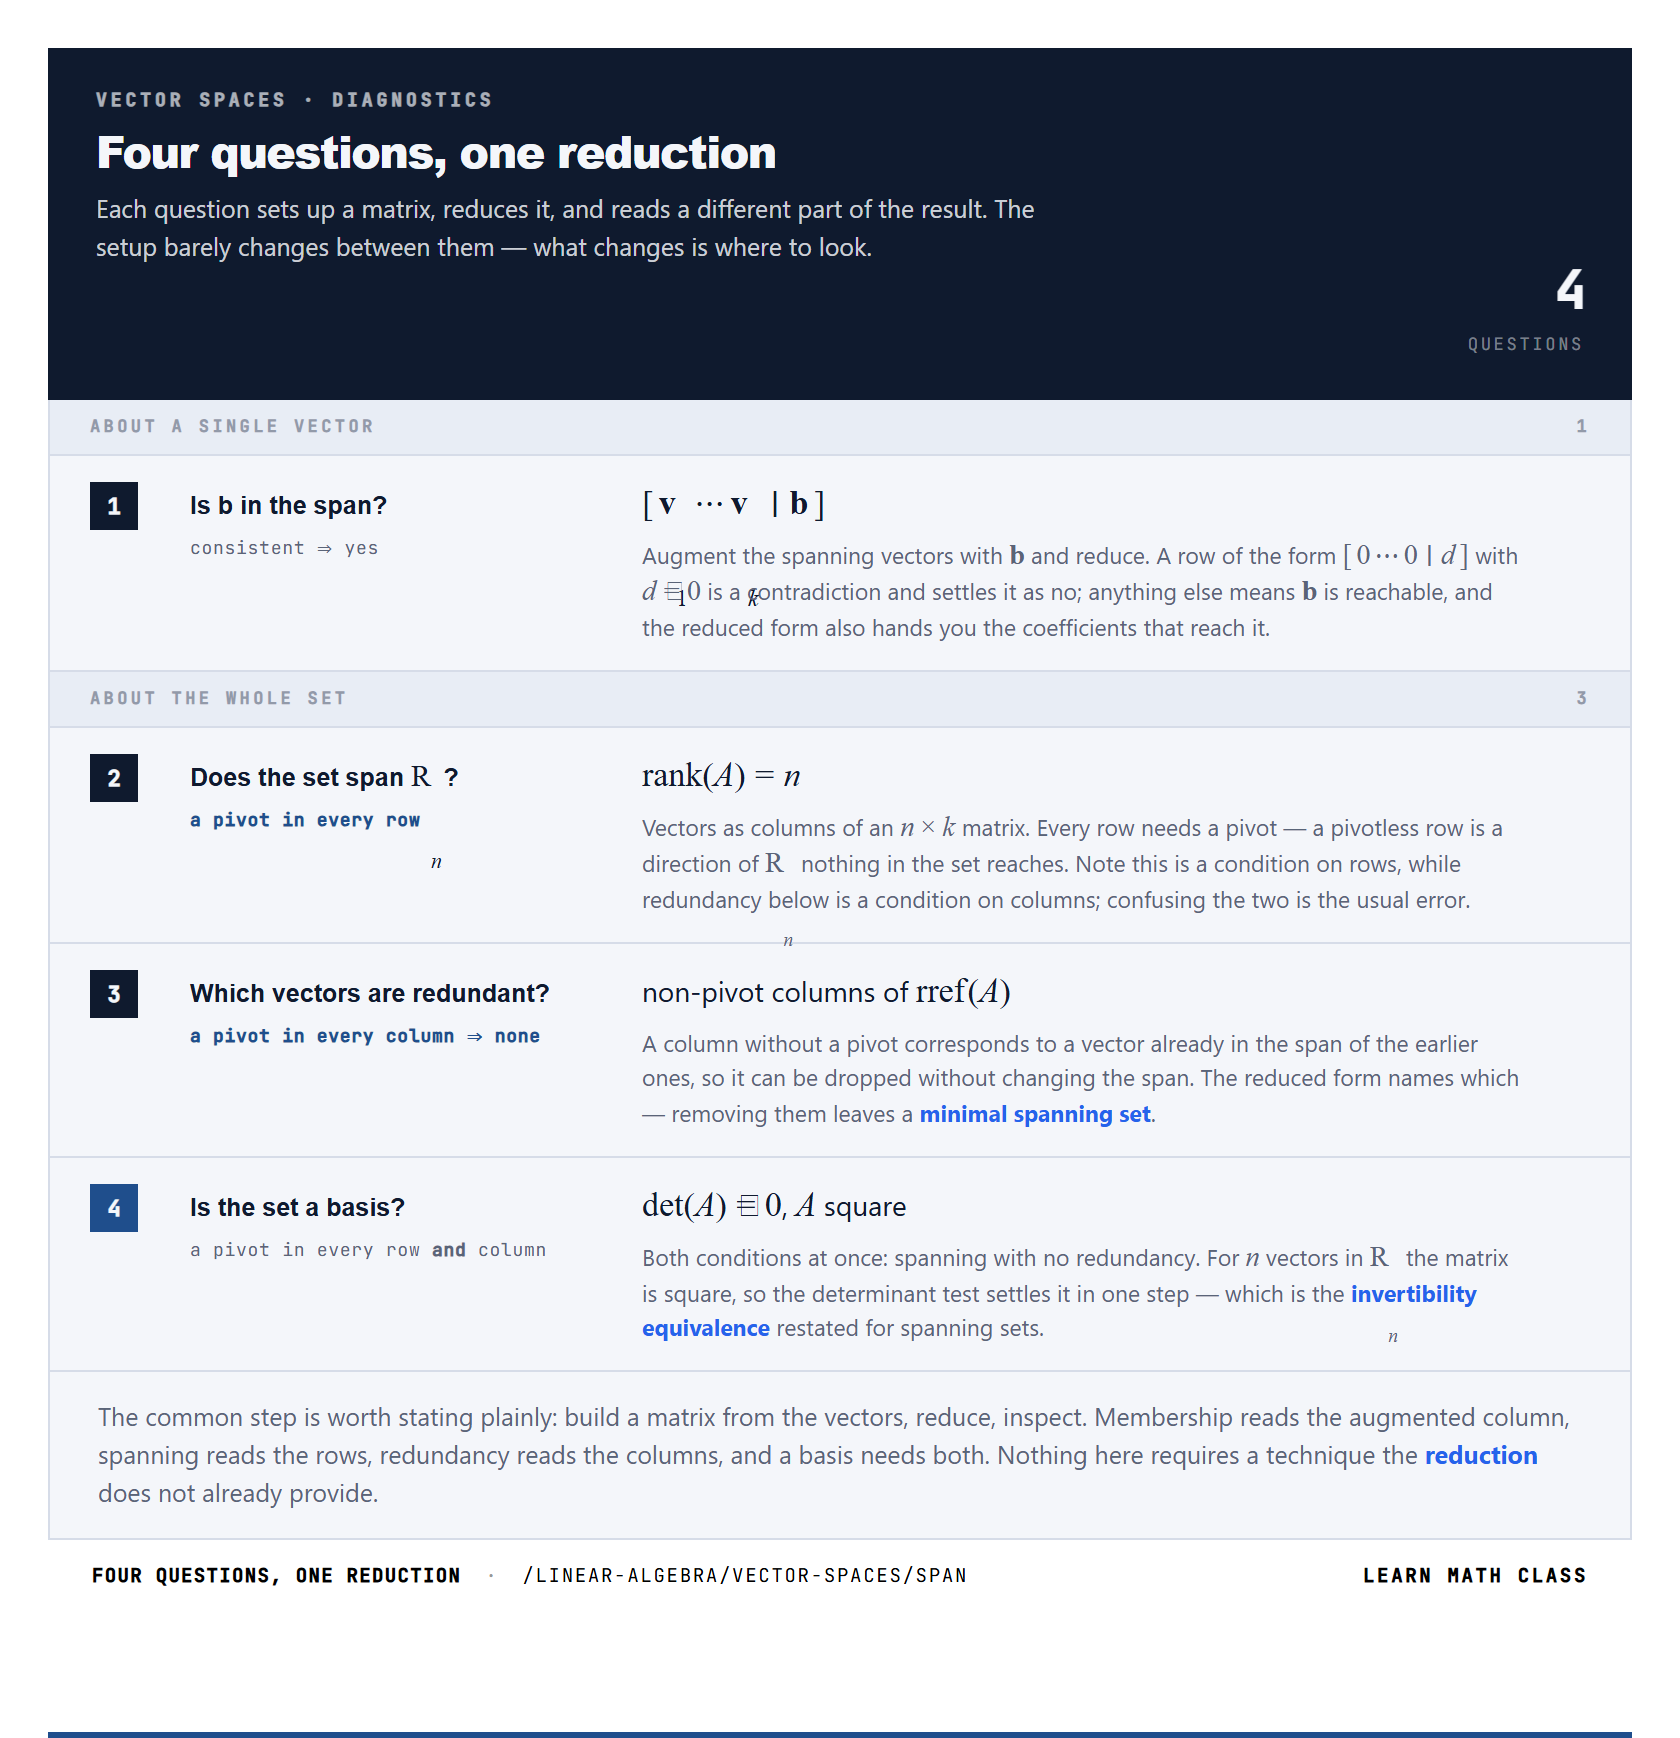
Every span question — whether a given vector is reachable, whether a set covers Rn\mathbb{R}^n, which vectors are redundant, whether a set is a basis — reduces to building a matrix from the given vectors, row-reducing it, and inspecting the result. What changes between questions is which part of the reduced form to look at: the augmented column for membership, the rows for spanning, the columns for redundancy, both for a basis. The table below collects these questions side by side, showing what to set up, what to look for in the reduced form, and what a positive answer means in each case.
Each of the four questions below is answered by the same procedure: arrange the vectors as the columns of a matrix, reduce, and read the result. What differs is only which feature of the reduced form carries the answer — a contradiction row, a pivotless row, a pivotless column, or the absence of both. Grouping the questions by what they interrogate makes that overlap visible: one asks about a single vector against the set, three ask about the set itself.
Vector spaces · diagnostics

Four questions, one reduction

Each question sets up a matrix, reduces it, and reads a different part of the result. The setup barely changes between them — what changes is where to look.

4questions
About a single vector1
1
consistent ⇒ yes
[v1vkb][\,\mathbf{v}_1 \cdots \mathbf{v}_k \mid \mathbf{b}\,]
Augment the spanning vectors with b\mathbf{b} and reduce. A row of the form [00d][\,0 \cdots 0 \mid d\,] with d0d \neq 0 is a contradiction and settles it as no; anything else means b\mathbf{b} is reachable, and the reduced form also hands you the coefficients that reach it.
About the whole set3
2
rank(A)=n\operatorname{rank}(A) = n
Vectors as columns of an n×kn \times k matrix. Every row needs a pivot — a pivotless row is a direction of Rn\mathbb{R}^n nothing in the set reaches. Note this is a condition on rows, while redundancy below is a condition on columns; confusing the two is the usual error.
3
a pivot in every column ⇒ none
non-pivot columns of rref(A)\operatorname{rref}(A)
A column without a pivot corresponds to a vector already in the span of the earlier ones, so it can be dropped without changing the span. The reduced form names which — removing them leaves a minimal spanning set.
4
a pivot in every row and column
det(A)0\det(A) \neq 0, AA square
Both conditions at once: spanning with no redundancy. For nn vectors in Rn\mathbb{R}^n the matrix is square, so the determinant test settles it in one step — which is the invertibility equivalence restated for spanning sets.
The common step is worth stating plainly: build a matrix from the vectors, reduce, inspect. Membership reads the augmented column, spanning reads the rows, redundancy reads the columns, and a basis needs both. Nothing here requires a technique the reduction does not already provide.
Four questions, one reduction·/linear-algebra/vector-spaces/spanLearn Math Class
Two of these deserve to be held apart deliberately. Spanning is a condition on rows — a row without a pivot names a direction of Rn\mathbb{R}^n that nothing in the set reaches. Redundancy is a condition on columns — a column without a pivot names a vector the others already reach. Both are read from the same echelon form and they answer opposite questions, which is why they are the pair most often confused.
A set passing both is a basis, and for nn vectors in Rn\mathbb{R}^n the square determinant test collapses the two checks into one. Where the count is wrong no determinant exists and the conditions must be checked separately — fewer than nn vectors cannot span, more than nn cannot be independent, and the reduction says which failure has occurred.
Span FAQ

Is Span{v1,v2}\text{Span}\{\mathbf{v}_1, \mathbf{v}_2\} the same as {v1,v2}\{\mathbf{v}_1, \mathbf{v}_2\}?

+
Not remotely. The braces alone name a set with exactly two elements; wrapping them in the span operator produces a subspace with infinitely many. Dropping the word collapses an entire plane down to two points, which is why the operator has to be written even though the braces beside it look like the whole story.Read more →

Does u,v\langle \mathbf{u}, \mathbf{v} \rangle mean a span or an inner product?

+
With two vectors inside, genuinely either, which is why linear algebra texts mostly avoid angle brackets for span. The same pair of glyphs carries three jobs across mathematics: components in some calculus texts, span in some algebra texts, and the inner product almost everywhere else. Only surrounding context resolves it.Read more →

What is F\mathbb{F} in these definitions?

+
A placeholder for whichever field the scalars come from, usually R\mathbb{R} or C\mathbb{C}. It joins the blackboard-bold family in appearance but differs in kind: R\mathbb{R} and Z\mathbb{Z} name fixed sets, whereas F\mathbb{F} names none. Writing definitions over F\mathbb{F} states the real and complex cases in a single line.Read more →