A real matrix can have complex eigenvalues — this happens when the characteristic polynomial has no real roots. Geometrically, no real direction is mapped to a scalar multiple of itself; the transformation involves rotation. Complex eigenvalues of real matrices always come in conjugate pairs, and each pair corresponds to a rotation-scaling action on a two-dimensional subspace.
For step-by-step results on your own numbers, use the eigenvalue and eigenvector calculators on CalculateMatrix.
When Complex Eigenvalues Appear
An eigenvector is a direction that a matrix only stretches. Look for one in a rotation.
Take R=(01−10), the rotation by 90°, and test a few vectors.
Every vector comes out at right angles to itself, so no real direction survives.
v
Rv
a multiple of v?
(1, 0)
(0, 1)
no
(1, 1)
(−1, 1)
no
(1, 2)
(−2, 1)
no
(a, b)
(−b, a), at right angles to v
never, unless v = 0
Rv is always perpendicular to v, so it is never a multiple of v. Yet the equation det(R−λI)=λ2+1=0 still has solutions: λ=±i.
The characteristic polynomial has no real roots, so the eigenvalues leave the real numbers.
For a 2×2 matrix, the discriminant of the characteristic polynomial determines the eigenvalue type:
Discriminant Classification 2x2
Δ=tr(A)2−4det(A)⎩⎨⎧Δ>0:Δ=0:Δ<0:two distinct real eigenvaluesone repeated real eigenvaluecomplex conjugate pair
Complex eigenvalues appear in the Δ<0 case: the quadratic formula produces λ=2tr(A)±negative, which involves −1=i.
The definition
A complex eigenvalue of a real matrix A is a non-real root λ of its characteristic polynomial; it comes with a complex eigenvectorv satisfying Av=λv.
A real matrix with real entries can have complex eigenvalues. This occurs when the characteristic polynomial — a polynomial with real coefficients — has roots that are not real.
So the 90° rotation has eigenvalues ±i, and v=(1,−i) satisfies Rv=iv.
Complex eigenvalues are the algebra's signal of rotation.
The geometric interpretation is clear: no real direction in R2 is mapped to a scalar multiple of itself. Every vector is rotated, not just stretched or compressed. The simplest example is rotation by 90°, with matrix (01−10) and characteristic polynomial λ2+1=0. The eigenvalues are ±i — purely imaginary, reflecting pure rotation with no scaling.
A rotation has no real eigenvector
The rotation preset: a real 2 × 2 matrix whose characteristic polynomial has a negative discriminant. Its roots are a complex conjugate pair, and (A − λI)v = 0 has no nonzero real solution — every real vector is turned off its own line, so no real direction is merely stretched. Compare it with the real cases on the eigenvalues and eigenvectors visualizer.
Complex eigenvalues are the algebra's way of reporting that the transformation turns every real direction.
They come in pairs: a real matrix never has just one.
The characteristic polynomial has real coefficients, so if λ=a+bi is a root, so is λˉ=a−bi. For the rotation these are i and −i. The pairing is the subject of conjugate pairs.
The rest of the page covers notation, conjugate pairs, the 2×2 case in detail, complex eigenvectors, the real canonical form, larger matrices, dynamical systems, the link with the fundamental theorem of algebra, and a summary.
Complex Eigenvalue Notation
Notation
Complex Eigenvalue Notation
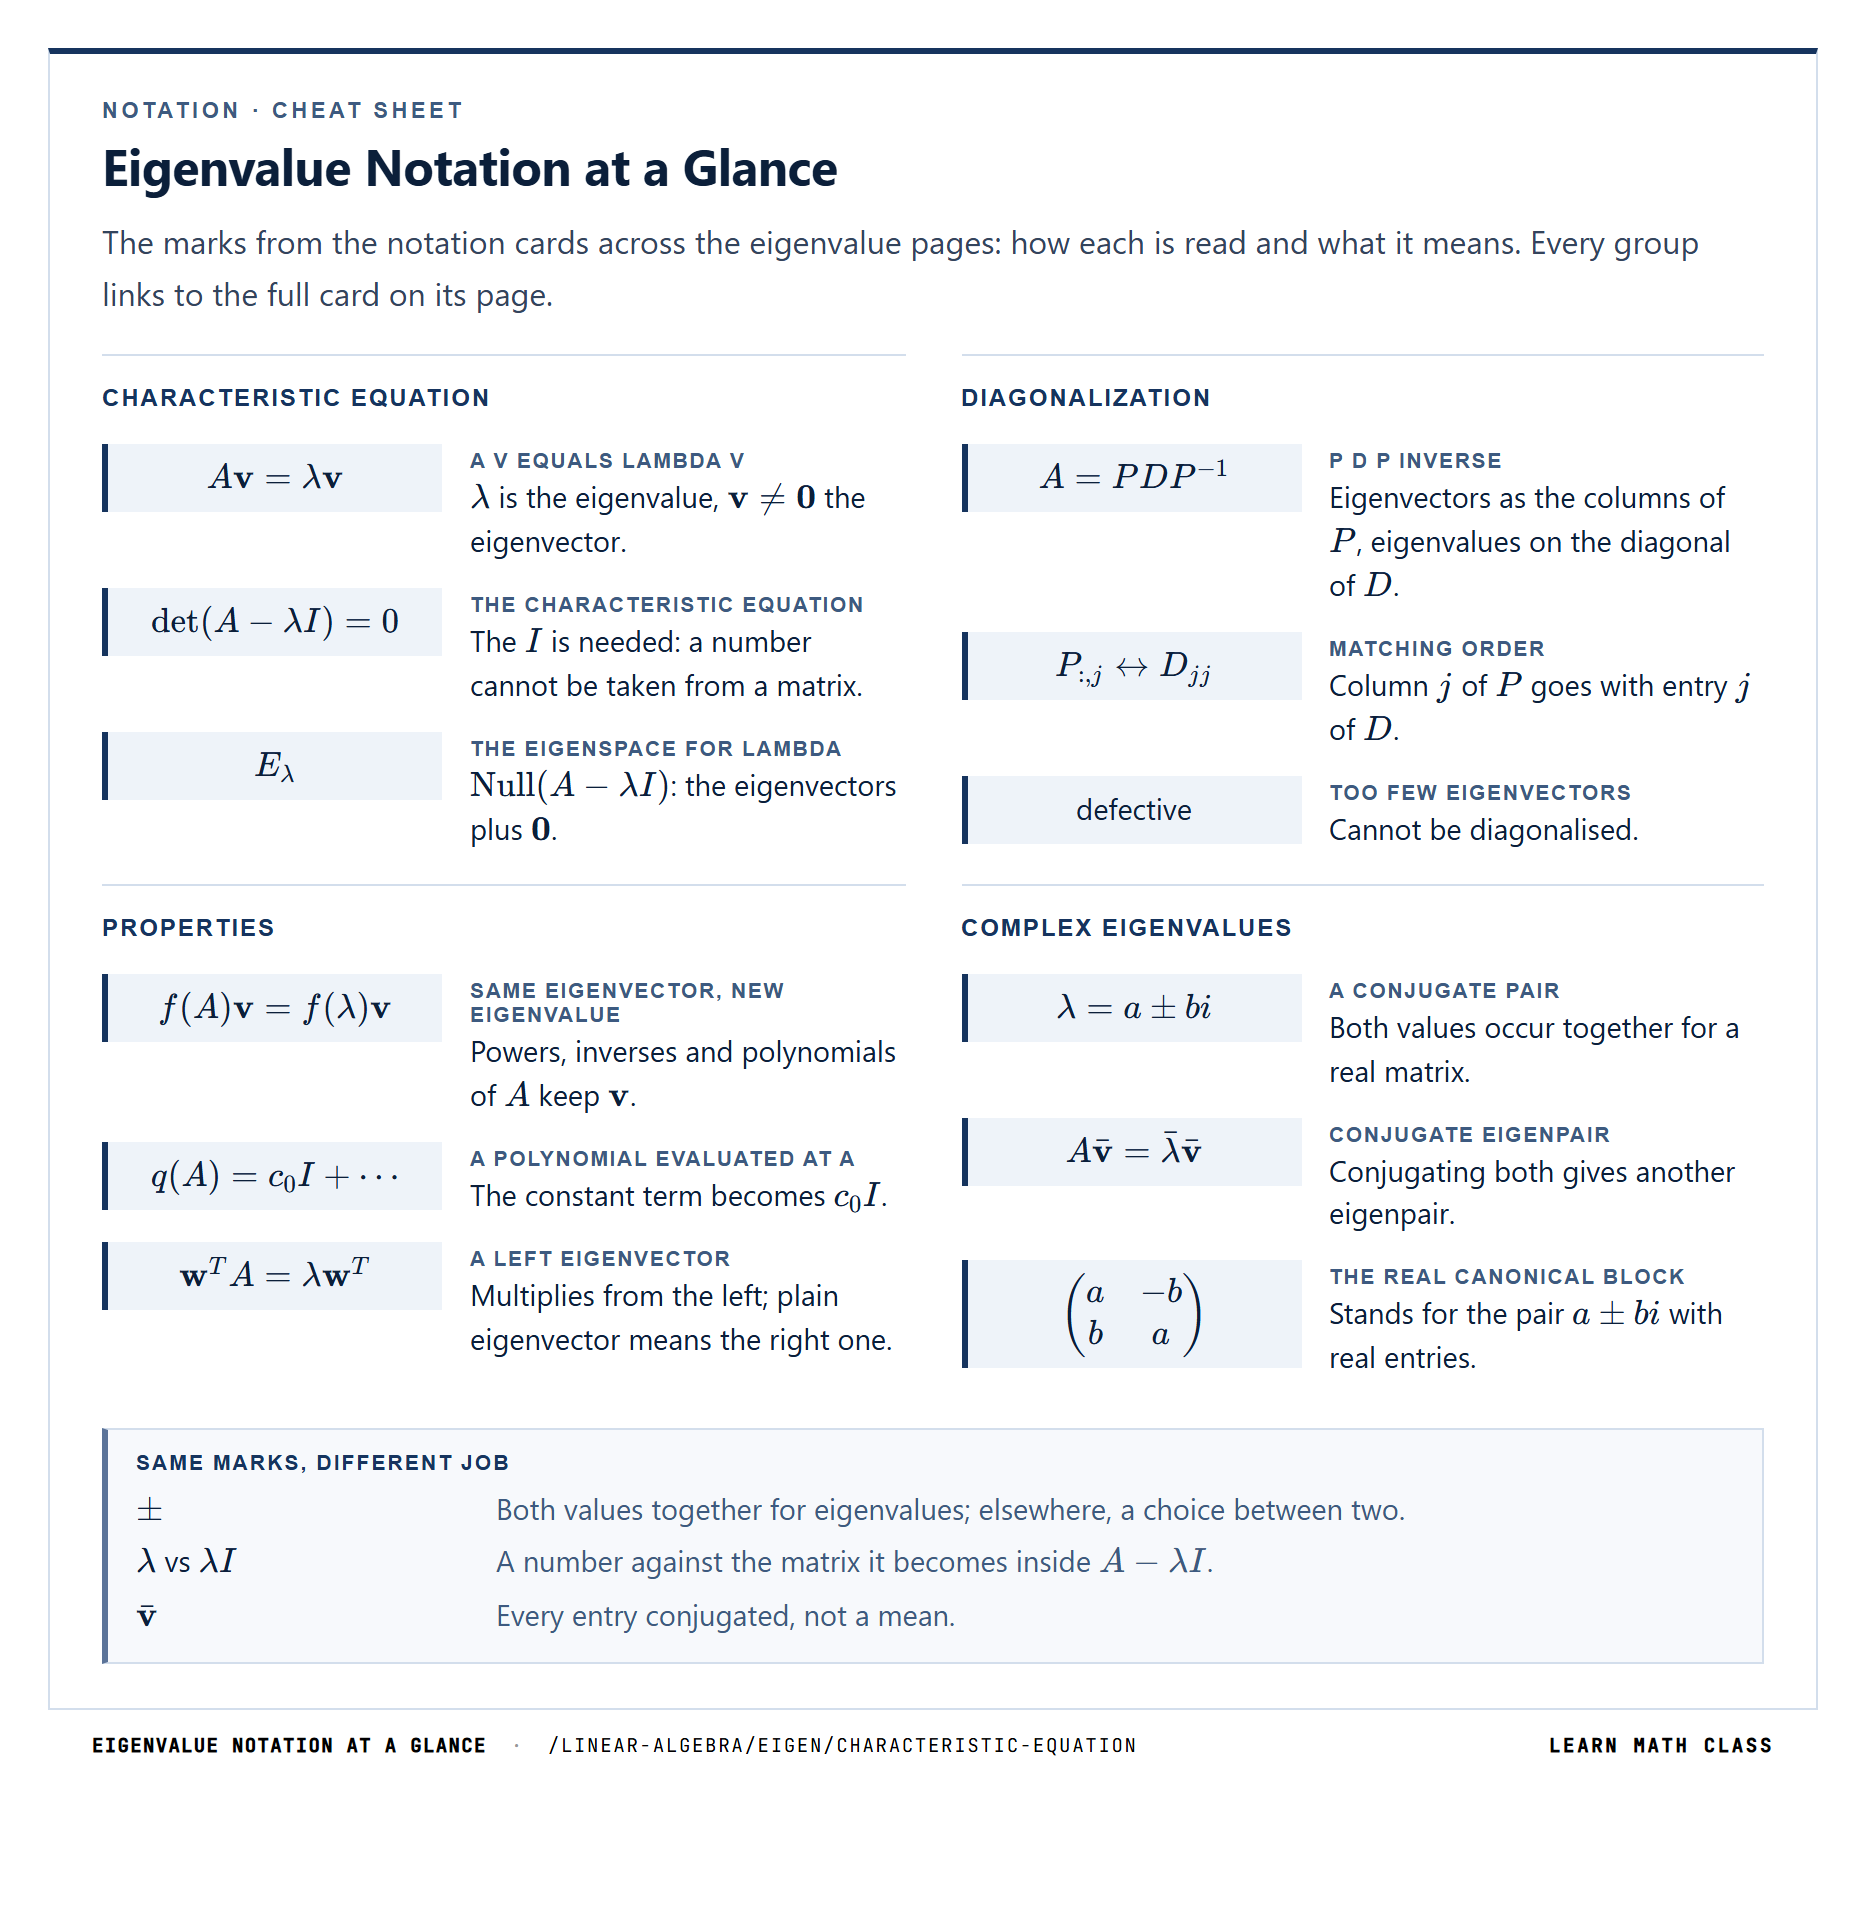
A bar that has to be applied twice — once to a number and once to a whole vector — plus a ± that is a statement about pairing rather than a shorthand for two options, and a normal form whose block is chosen so that no complex number has to be written down at all. All catalogued among the linear algebra symbols.
conjugating both the eigenvalue and the eigenvector gives another eigenpair
The overbar works at two levels here: over λ it conjugates a single number, over v it conjugates every entry of a vector. The same mark, applied to objects of different type — and the implication only holds because A is real, as Conjugate Pairs below proves.
CasesPhysics and much of numerical linear algebra prefer A∗ or AH for the conjugate transpose of a matrix, reserving the plain bar for entrywise conjugation without the transpose; the two differ, and on a real matrix the distinction disappears, which is why it goes unnoticed until complex entries arrive.
Do not confuseConjugating only the eigenvalue. λˉ pairs with vˉ, not with v — the original eigenvector does not belong to the conjugate eigenvalue, and dropping the bar on the vector produces a statement that is simply false.
λ=a±bi
a pair of eigenvalues, not a choice between two
Elsewhere ± offers alternatives; here it asserts that both values occur, together, as a package — a real matrix cannot have one without the other. The compression is honest because the pair always appears in full, which is what makes the single line a complete description of two eigenvalues.
CasesThe sign convention runs through the geometry: b is the rotation rate and its sign fixes the direction of turning, so writing a±bi records a rotation together with its mirror image; b=0 collapses the pair to a single real eigenvalue and the notation degenerates gracefully.
Do not confuseThe ± of the quadratic formula, where the two signs are two candidate roots you may pick between. Here selecting one is not an option — the eigenvalues are both present in the matrix.
(ab−ba)
the real canonical block standing in for the pair a plus or minus b i
A 2×2 block that represents a conjugate pair without writing any complex number — the whole point of Real Canonical Form below. The off-diagonal sign asymmetry is the notation: −b above the diagonal and b below is what encodes rotation.
CasesScaled out, the block reads r(cosθsinθ−sinθcosθ) with r=∣λ∣ and θ=argλ — the modulus and argument of the eigenvalue reappearing as a scaling factor and a rotation angle.
Do not confuseA diagonal matrix. The whole reason this form exists is that a real matrix with complex eigenvalues cannot be diagonalised over R; the block is the closest real substitute, and treating it as diagonal loses the rotation it was built to carry.
For a real matrix, complex eigenvalues always come in conjugate pairs. If λ=a+bi is an eigenvalue (with b=0), then λˉ=a−bi is also an eigenvalue. The corresponding eigenvectors are also conjugates:
The proof uses the fact that the characteristic polynomial has real coefficients. If p(λ)=0 and every coefficient of p is real, then p(λˉ)=p(λ)=0=0. Complex conjugation passes through the polynomial because the coefficients are their own conjugates.
For the eigenvector identity: applying complex conjugation to Av=λv and using that A has real entries gives Avˉ=λˉvˉ.
One consequence for odd-dimensional real matrices: at least one eigenvalue must be real. Complex roots pair up, consuming an even number of the n roots. When n is odd, at least one root is left unpaired, and an unpaired root of a real polynomial must be real.
Real entries force complex eigenvalues, and their eigenvectors, to arrive in conjugate pairs.
The 2×2 Case in Detail
Fact: No crystal has fivefold symmetry
A rotation that maps a plane lattice onto itself has integer entries in a basis of lattice vectors, so its trace 2cosθ is an integer (in space, 1+2cosθ). For a complex pair that leaves only θ=60°, 90° or 120°: crystals allow 6-, 4- and 3-fold turns, never the 72° turn of 5-fold symmetry.
A 2×2 real matrix with complex eigenvalues λ=a±bi (where b=0) acts, in a suitable real basis, as a rotation composed with a scaling. The eigenvalues have modulus r=a2+b2 and argument θ with cosθ=a/r, sinθ=b/r (this is arctan(b/a) only when a>0).
When r=1 (equivalently, det(A)=a2+b2=1), the transformation is, in that basis, a pure rotation by angle θ. When r>1, it is a rotation with outward spiraling. When r<1, it is a rotation with inward spiraling.
Worked Example
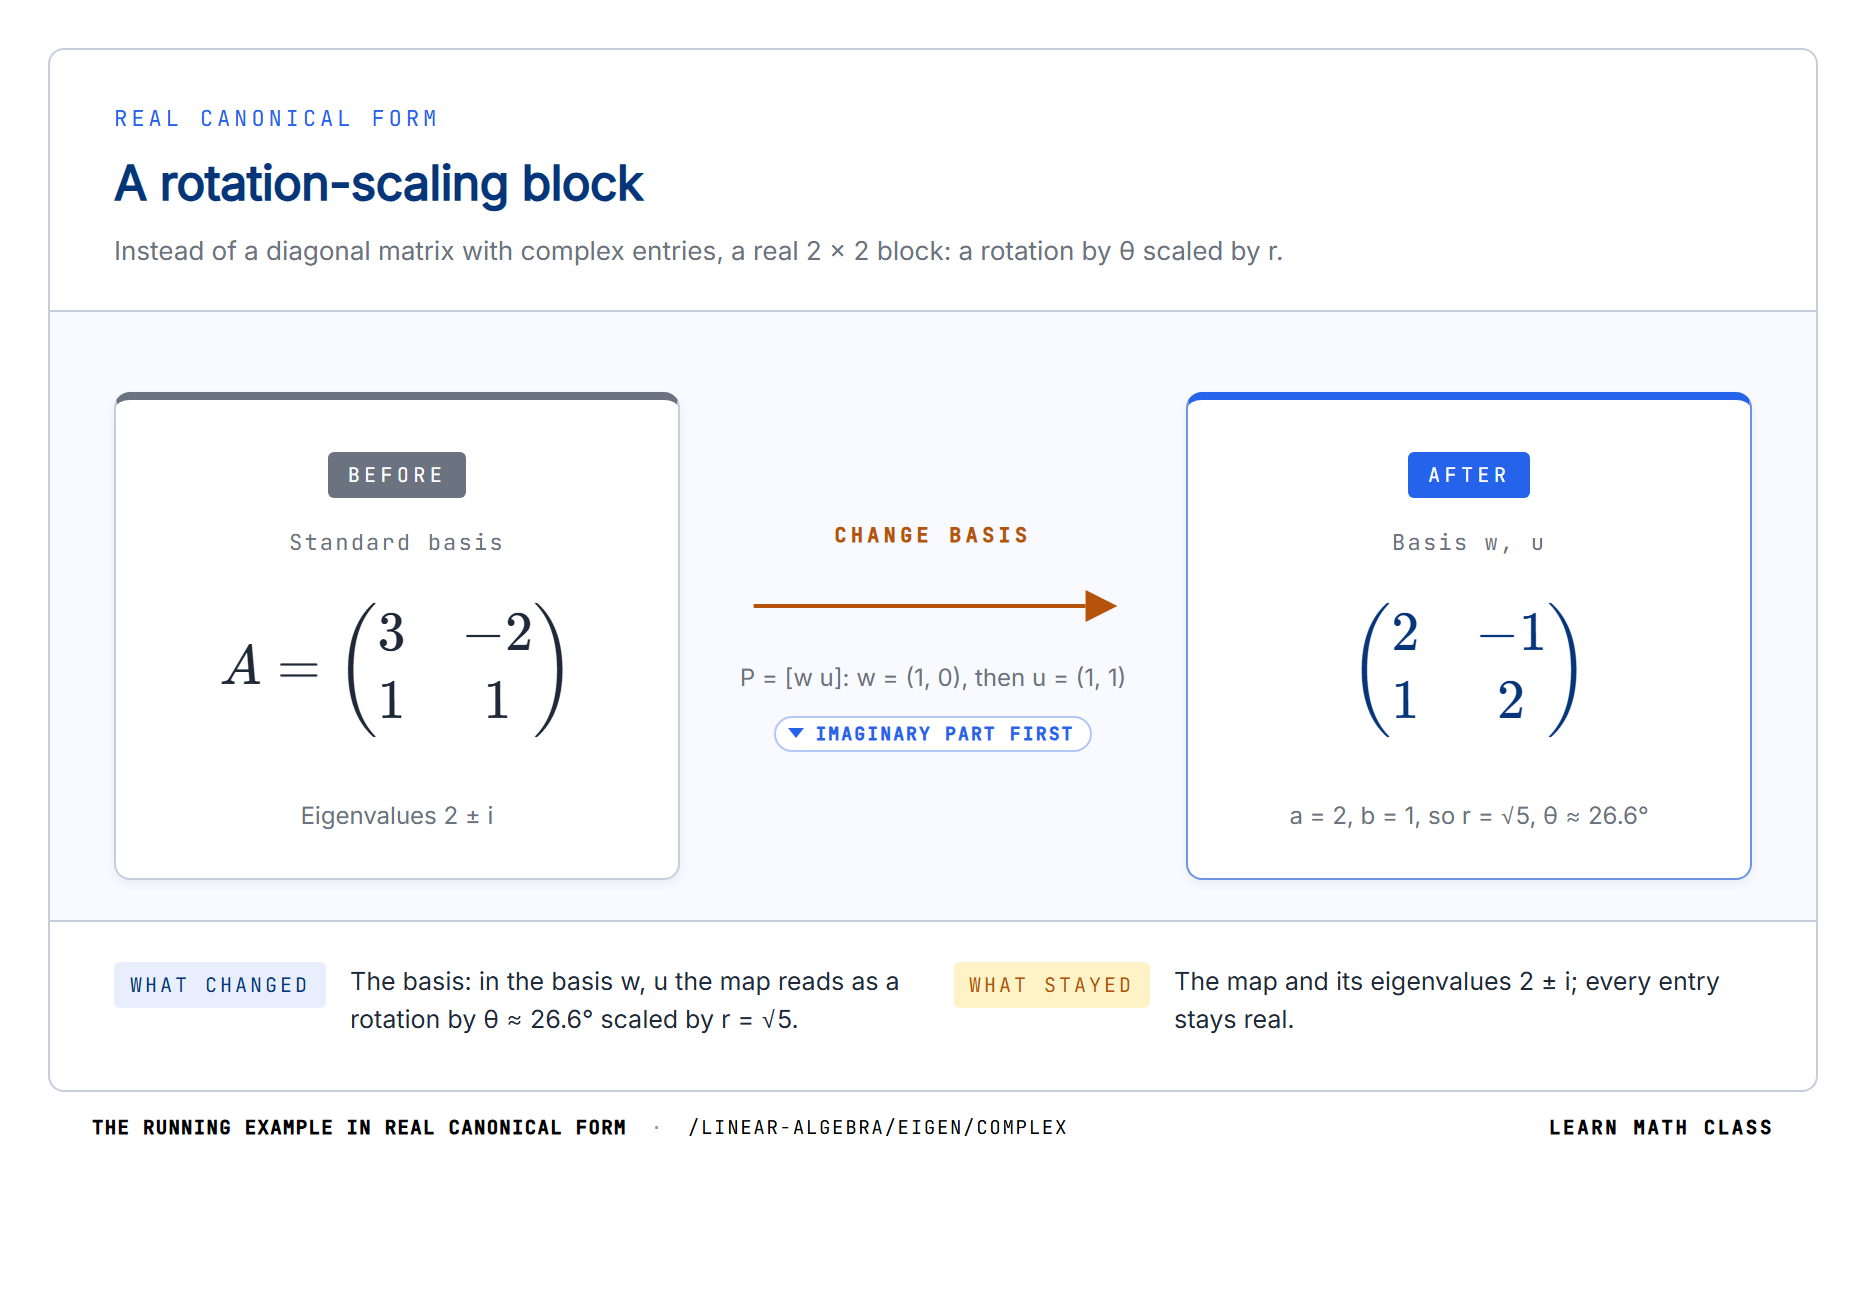
For A=(31−21): tr(A)=4, det(A)=5, discriminant =16−20=−4. The eigenvalues are
The 2×2 Case in Detail
λ=24±−4=2±i
Pitfall: Taking the determinant as the modulus
Reading det(A)=5 as the modulus says distances are scaled by 5. But det(A)=a2+b2=r2, so r=5≈2.24; the factor 5 belongs to areas.
The modulus is r=4+1=5 and the argument is θ=arctan(1/2). In the basis of the real canonical form, the transformation rotates by arctan(1/2)≈26.6° while scaling distances by 5≈2.24. Since r>1, repeated application spirals outward.
The argument θ fixes how fast the plane turns and never affects whether it grows. That is decided entirely by the modulus, and the three cases below are the only ones there are.
geometric actionpure rotation by θ in the basis of the real canonical form, no scaling
det of the 2×2 blockdetA=1
orbit of a pointpoints on a closed ellipse (a circle in the basis of the real canonical form)
In the basis of the real canonical form, lengths are preserved exactly and the block is orthogonal; A itself need not be. Every orbit closes if θ is a rational multiple of 2π and fills the circle densely otherwise — the boundary case in every stability argument.
geometric actionrotation with outward scaling by r
det of the 2×2 blockdetA>1
orbit of a pointa spiral outward
Each application turns by θ and stretches by r, so iterates diverge while circling. In a discrete system this is instability — and the divergence is geometric, so it is fast.
The stable case for iteration: every orbit converges to the origin, still turning as it goes. This is what ∣λ∣<1 means geometrically, and why the condition is stated on the modulus rather than on the real part.
The determinant of the 2×2 block is a2+b2=r2, so the area scaling and the modulus are the same fact stated twice — which is why the determinant can be read as a stability marker without computing an eigenvalue at all.
The three cases exhaust the possibilities because r is a positive real and can only be less than, equal to, or greater than one. The argument θ plays no part in the classification — it sets the speed of rotation and nothing else, which is why two systems can spiral at completely different rates and be equally stable.
Every direction turned, none left fixed
No arrow survives this matrix pointing where it started: every direction is rotated. That is what a complex eigenvalue looks like from the real plane — not an exotic number but the absence of any invariant line. The rotation angle is the argument of the eigenvalue. Turn the matrix and watch the fixed directions vanish on the complex eigenvalue explorer.
The conjugate partner of this eigenvalue describes the same rotation turning the other way, which is why the pair always arrives together.
Complex Eigenvectors
The eigenvectors corresponding to complex eigenvalues have complex entries. To find them, solve (A−λI)v=0 using complex arithmetic.
Continuing the example with A=(31−21) and λ=2+i:
Complex Eigenvectors
A−(2+i)I=(1−i1−2−1−i)
The second row gives v1+(−1−i)v2=0, so v1=(1+i)v2. Setting v2=1: v=(1+i,1)T.
This eigenvector splits into real and imaginary parts: v=u(1,1)T+iw(1,0)T. The real vectors u and w encode the rotation — they span the two-dimensional subspace on which the rotation-scaling acts. The conjugate eigenvector for λˉ=2−i is vˉ=(1−i,1)T.
A complex eigenvector is two real vectors in disguise, spanning the plane on which the matrix rotates and scales.
Real Canonical Form
A 2×2 real matrix with eigenvalues a±bi is similar (over R) to a rotation-scaling block:
where r=a2+b2 and θ satisfies cosθ=a/r, sinθ=b/r. This is a rotation by θ scaled by r.
The similarity is achieved by the real matrix P=[wu] — imaginary part first, then real part — where v=u+iw is the complex eigenvector for λ=a+bi. Then P−1AP=(ab−ba).
Pitfall: Putting the real part first
Taking P=[uw]=(1110) gives P−1AP=(2−112), a rotation the other way. With P=[wu]=(1011) the result is (21−12).
For the running example, λ=2+i and v=(1+i,1)T from the previous section, so u=(1,1)T and w=(1,0)T. These two real vectors become the columns of P, and P−1AP should come out as the block with a=2 and b=1. Computing it is a direct check on the eigenvector found above.
This is the real alternative to diagonalization: instead of a diagonal matrix with complex entries (which is valid over C but not over R), we get a real 2×2 rotation-scaling block. The transformation is expressed in its simplest real form.
The check the section sets up: the columns w and u of P turn A into its rotation-scaling block.
P⁻¹AP comes out as the block with a = 2 and b = 1, which confirms the eigenvector (1 + i, 1) found above.
Complex Eigenvalues in Larger Matrices
For an n×n real matrix, complex eigenvalues still come in conjugate pairs. When A is diagonalizable over C, each pair contributes a 2×2 rotation-scaling block to the real canonical form, and each real eigenvalue contributes a 1×1 block (just the eigenvalue itself).
A 4×4 matrix with eigenvalues 2±3i and −1±i has real canonical form
Complex Eigenvalues in Larger Matrices
2300−320000−1100−1−1
A 3×3 matrix with eigenvalues 5 and 1±2i has real canonical form
Complex Eigenvalues in Larger Matrices
5000120−21
Fact: Only 8 of 100 eigenvalues are real
A 100×100 matrix with independent, normally distributed entries has on average only about 8.4 real eigenvalues; the other 90 or so pair off into 2×2 blocks. The expected number of real eigenvalues grows only like 2n/π (Edelman, Kostlan and Shub, 1994).
The real canonical form is the real analogue of diagonalization: for a matrix diagonalizable over C it achieves the simplest possible real matrix that is similar to A, with the block structure directly reflecting the eigenvalue spectrum; otherwise larger real Jordan blocks appear.
How the n eigenvalues split between the two kinds of block depends on the matrix. A symmetric matrix has only real eigenvalues, so its real canonical form is made of 1×1 blocks alone, while a rotation of R4 in two separate planes is made of two 2×2 blocks and nothing else. A matrix whose entries are chosen at random falls somewhere between these extremes.
Dynamical Systems Interpretation
Complex eigenvalues produce oscillatory behavior in dynamical systems.
In the discrete system xn+1=Axn, an eigenvalue λ=a+bi with modulus r=∣λ∣=a2+b2 generates a spiraling trajectory. When r>1, the spiral grows outward — the system is unstable. When r<1, the spiral decays inward — the system converges to the origin. When r=1, the points stay on a closed curve — perpetual oscillation without growth or decay.
Pitfall: Using the real-part test on a discrete system
Judging xn+1=Axn by the sign of the real part calls λ=21±21i unstable, since Re(λ)>0. Here the modulus decides: ∣λ∣=22≈0.71<1, so the iterates spiral in to 0.
In the continuous system x′=Ax, an eigenvalue λ=a+bi contributes a term eat(cosbt,sinbt) to the solution. The real part a determines exponential growth (a>0) or decay (a<0). The imaginary part b determines the oscillation frequency. When a=0, the oscillation is sustained. When a<0, it is damped. When a>0, it grows without bound.
THEOREM
Stability of a linear system reduces to eigenvalue analysis: the system is stable if and only if every eigenvalue has negative real part (continuous) or modulus less than 1 (discrete).
Regime
Discrete: xn+1 = A xn
Continuous: x′ = A x
Stable (converging)
|λ| < 1 → trajectory spirals inward to the origin
Re(λ) < 0 → damped oscillation decaying to zero
Marginally stable
|λ| = 1 → trajectory stays on a closed curve
Re(λ) = 0 → sustained oscillation at constant amplitude
Unstable (diverging)
|λ| > 1 → trajectory spirals outward without bound
Re(λ) > 0 → oscillation with exponentially growing amplitude
Spiralling in, then spiralling out
The rotation is the same in both; what differs is the modulus of the eigenvalue. Below one, repeated application pulls everything towards the origin; above one, it throws everything outward. The argument sets how fast it turns and the modulus sets whether it survives, which is the whole stability story for a discrete system. Tune both on the complex eigenvalue explorer.
Whether a system settles, oscillates forever or blows up is therefore read off a single number: the modulus.
The Fundamental Theorem of Algebra Connection
THEOREMFundamental Theorem of Algebra
Over C, every polynomial of degree n factors completely into n linear factors.
This means every n×n matrix — real or complex — has exactly n eigenvalues counted with algebraic multiplicity when the characteristic polynomial is factored over C.
Over R, some factors may be irreducible quadratics rather than linear, corresponding to conjugate pairs of complex eigenvalues. The characteristic polynomial of a real matrix factors into linear terms (real eigenvalues) and irreducible quadratic terms (complex conjugate pairs).
Working over C simplifies the theory considerably. Every matrix is triangularizable over C (Schur decomposition): A=UTU∗ where U is unitary and T is upper triangular with eigenvalues on the diagonal. Diagonalizability depends only on whether the geometric multiplicities match the algebraic multiplicities, with no additional complications from irreducible quadratics.
The choice between working over R and C is a recurring theme. Real matrices are the natural objects of computation, but complex eigenvalues are the natural objects of spectral theory. Both perspectives are needed.
Summary: Complex Eigenvalues at a Glance
The behavior of complex eigenvalues for a real matrix is governed by a handful of formulas and statements that connect the discriminant, the modulus, the argument, and the real part to specific geometric and dynamical consequences. The table below collects each one alongside what it produces and what it means, providing a single reference for the page's key facts.
A complex eigenvalue is often met as a nuisance — the characteristic polynomial refuses to factor over the reals and the calculation appears to have failed. It has not. The pair is describing a rotation, and once that is granted the two numbers it carries are exactly the two things a rotation has: an angle and a scale. The grouping below is recognition first, then those two numbers, then what they predict.
A complex pair is not a failure of the real case — it is a rotation, and its two parts say by how much and through what angle. The modulus and argument are the whole content, and everything below is one of them applied.
The discriminant settles it before any solving. A negative value means no real direction is mapped to a multiple of itself — the transformation turns every vector, so no real eigenvector can exist.
Complex roots of a real polynomial arrive in pairs, and the eigenvectors pair with them: v and vˉ. Nothing has to be computed twice — finding one half of the pair gives the other by conjugation.
Complex roots come in pairs, so an odd number of them cannot pair off entirely and at least one must be real. This is why a rotation in R3 has an axis while a rotation in R2 has none — the eigenvector of the leftover real eigenvalue spans the axis.
How much the transformation stretches the plane per application. Since r2=det of the 2×2 block, the determinant is the area scaling and the modulus is its square root — consistent with the geometric reading.
How far the plane turns per application. A pair with a=0 is a quarter turn; the sign of b picks the direction, and the two conjugates give the two orientations of the same rotation.
The pair does not have to be handled in C at all. Over R the matrix is similar to a scaled rotation block, so the whole analysis stays real — which is what makes complex eigenvalues usable in applied work.
The modulus alone decides whether iteration spirals inward or outward; the argument only sets how fast it turns. Note ∣λ∣=1 is the boundary case — in the basis of the real canonical form, a pure rotation that neither grows nor decays.
A different criterion for a different system, and confusing the two is the usual error. Discrete systems compare the modulus against one; continuous systems compare the real part against zero — because the solution is eλt and its growth is governed by Re(λ).
The single idea underneath: a real matrix with eigenvalues re±iθ acts on the corresponding real plane, in the basis of the real canonical form, as a rotation by θ scaled by r. Recognition, canonical form and stability are all that statement read at different moments — which is why the modulus and argument are worth computing before anything else.
The real canonical form is what keeps this practical. A conjugate pair can be handled entirely in R: the matrix is similar to a block [ab−ba], which is a rotation by θ scaled by r, and no complex arithmetic is required at any point. The complex numbers are a route to the answer rather than a property of it.
The two stability criteria are worth separating carefully, because they look alike and are not. A discrete system xk+1=Axk is stable when every ∣λ∣<1 — the modulus decides, since each step multiplies by it. A continuous system x′=Ax is stable when every Re(λ)<0 — the real part decides, since the solution behaves as eλt. Applying the wrong test gives a confidently wrong answer.
Common Pitfalls
Four mistakes come up again and again when working with complex eigenvalues. Three are marked with a box where they happen in the sections above, and the first, the formula for the angle, is flagged in the text of the 2×2 section. Here each is worked through in full, with the wrong and the right working side by side.
Reading the angle from the arctangent alone
The argument θ of a+bi is computed as arctan(b/a) whatever the sign of a. The arctangent only returns angles between −90° and 90°, so when a<0 the angle lands in the wrong half of the plane.
Wrong working: for the pair −1±i of the 4×4 example, r=2 and
Right working: use cosθ=a/r and sinθ=b/r together.
cosθ=−21,sinθ=21⇒θ=135°
2(cos135°sin135°−sin135°cos135°)=(−11−1−1)
Why it happens: most worked examples, including 2±i on this page, have a>0, where arctan(b/a) is correct, so the shortcut is remembered as the rule.
How to check: the signs of cosθ and sinθ must match the signs of a and b. Here a<0 and b>0, so θ lies between 90° and 180°.
Taking the determinant as the modulus
The determinant det(A)=a2+b2 is read as the modulus r of the eigenvalues, so the scaling factor comes out squared.
Wrong working: for A=(31−21),
det(A)=3⋅1−(−2)⋅1=5⇒r=5
and the rotation-scaling is said to stretch distances by 5.
Right working: the eigenvalues are 2±i, and
r=∣2+i∣=22+12=5≈2.24,det(A)=(2+i)(2−i)=5=r2
In the basis of the real canonical form, distances are scaled by 5; the factor 5 is how much areas grow.
Why it happens: the determinant is often described as the scaling factor of a transformation. It is the factor for areas, and in the plane that is the square of the factor for lengths.
How to check: for a real 2×2 matrix with a complex pair, r=det(A). The verdict on growth is the same either way, since r>1 exactly when det(A)>1, so only the rate gives the slip away.
Putting the real part first
The matrix P is built with the real part u of the eigenvector as its first column and the imaginary part w second. The result is still a rotation-scaling block, but the sign of b is flipped, so it turns the other way.
Wrong working: with v=(1+i,1)T, u=(1,1)T and w=(1,0)T,
P=[uw]=(1110),P−1=(011−1)
P−1AP=(011−1)(1231)=(2−112)
the block for a=2 and b=−1, a rotation by −θ.
Right working: imaginary part first.
P=[wu]=(1011),P−1=(10−11)
P−1AP=(10−11)(3112)=(21−12)
Why it happens: v=u+iw lists the real part first, and that order is carried into P. Some textbooks do use [uw], but pair it with the eigenvalue a−bi, and the two conventions get mixed.
How to check: Aw must equal aw+bu. Here Aw=(3,1)T=2(1,0)T+1⋅(1,1)T, so w belongs in the first column, and the entry below the diagonal of P−1AP must be b=1.
Using the real-part test on a discrete system
The stability of xn+1=Axn is judged by the sign of Re(λ), the test for continuous systems, or the other way round: x′=Ax is judged by ∣λ∣.
Wrong working: A=21(11−11) has tr(A)=1 and det(A)=21, so
λ=21±1−2=21±21i,Re(λ)=21>0
and the discrete system is declared unstable.
Right working: for a discrete system the modulus decides.
∣λ∣=41+41=22≈0.71<1
Starting from x0=(1,0)T, the iterates (21,21)T and (0,21)T have lengths 0.71 and 0.5: the trajectory spirals in to 0. For x′=Ax with the same matrix the verdict reverses: ∣λ∣<1, but Re(λ)>0, and the solutions grow like et/2.
Why it happens: both tests compare an eigenvalue with a boundary, the unit circle for discrete systems and the imaginary axis for continuous ones, and the two boundaries are easily swapped.
How to check: ask what the system does to the part of x along an eigenvector. A discrete step multiplies it by λ, so after n steps its size is ∣λ∣n; a continuous solution behaves like eλt, whose size is eat.
Complex Eigenvalues FAQ
Does λˉ pair with v or with vˉ?
+
With vˉ. Conjugating the whole eigenvalue equation conjugates the vector as well, so the conjugate eigenvalue belongs to the conjugate eigenvector. The original v does not satisfy the equation for λˉ, and writing it that way produces a statement that is simply false rather than merely imprecise.Read more →
Is the ± in a±bi like the one in the quadratic formula?
+
It looks identical but does a different job. In the quadratic formula the two signs offer two candidate roots and you pick whichever the problem needs. Here selecting one is not an option: both eigenvalues genuinely belong to the matrix at the same time, and the mark is recording a pair rather than a choice.Read more →
Is the real canonical block just a diagonal matrix?
+
No, and that is exactly why it exists. A real matrix with complex eigenvalues cannot be diagonalised over the reals at all, so the block is the closest real substitute. Written out, it is a scaled rotation, with the eigenvalue's modulus setting the scale and its argument the angle. Treating it as diagonal discards the rotation.Read more →
Does every real matrix have at least one real eigenvalue?
+
No, but every real matrix of odd size does. Complex eigenvalues of a real matrix come in conjugate pairs, so they use up an even number of the n roots; when n is odd one root is left over, and it must be real. That is why a rotation of R3 always has an axis, while the 90° rotation of the plane has eigenvalues ±i and no real eigenvector at all.Read more →
How do you find the rotation angle of a complex eigenvalue?
+
Use cosθ=a/r and sinθ=b/r together, with r=a2+b2. The shortcut θ=arctan(b/a) only returns angles between −90° and 90°, so it is right only when a>0. For λ=−1+i it gives −45°, but the cosine is negative and the sine positive, so the angle is 135°, and only 135° rebuilds the matrix's rotation-scaling block.Read more →
Why can crystals not have fivefold symmetry?
+
Because a rotation that maps a lattice onto itself has integer entries in a basis of lattice vectors, so its trace is an integer. In the plane its eigenvalues are e±iθ and the trace is 2cosθ, which must be one of −2,−1,0,1,2. That leaves only 2-, 3-, 4- and 6-fold turns. A 72° turn would need 2cos72°≈0.618, which is not an integer.Read more →