The common derivatives cover polynomials, trigonometric functions, exponentials, and logarithms. Beyond these lie function families whose derivatives are less immediately obvious and harder to rederive on the spot. Inverse trigonometric functions produce algebraic expressions involving square roots. Hyperbolic functions mirror their trigonometric counterparts with subtle sign differences. Piecewise functions demand separate treatment on each interval with careful attention at boundaries.
Most of these derivatives are established through implicit differentiation or the inverse function formula rather than direct computation from the limit definition. Understanding the derivation builds insight; memorizing the result builds speed. Both matter.
Key Terms
Derivative— the formulas here extend the common derivatives to inverse trig, hyperbolic, and piecewise functions
The two derivatives differ only by sign. This follows from the identity arcsinx+arccosx=2π: differentiating both sides gives (arcsinx)′+(arccosx)′=0.
To derive the arcsine formula: let y=arcsinx, so siny=x with y∈[−π/2,π/2]. Differentiating implicitly: cosy⋅dxdy=1. Since y lies in the first or fourth quadrant, cosy≥0, so cosy=1−sin2y=1−x2. Solving gives dxdy=1−x21.
The domain restriction ∣x∣<1 reflects the range of siny on [−π/2,π/2]. At x=±1, the denominator vanishes—the graph of arcsinx has vertical tangents at its endpoints.
Pitfall: Forgetting the chain rule
Writing 1−4x21 for the derivative of arcsin(2x) leaves out the derivative of the inner 2x. The chain rule gives dxd[arcsin(2x)]=1−4x22.
The formulas are stated for the bare variable x, but in practice the argument of arcsin or arccos is often an expression such as 2x, x2 or ex. The formula is then evaluated at that inner expression, and the chain rule links the result to the rate at which the inner expression changes. The same holds for every formula on this page.
arcsin x and its derivative
The blue curve is arcsin x on its domain [−1, 1]; the amber curve is its derivative 1/√(1 − x²). In the middle the derivative is close to 1 and the graph rises like a line through the origin. Toward x = ±1 the denominator √(1 − x²) shrinks to 0, the derivative grows without bound, and the graph of arcsin x turns vertical at its endpoints.
arccos x has the same picture turned over: its derivative is the negative of this one.
Inverse Trigonometric Functions — Arctangent and Arccotangent
Again the derivatives are negatives of each other, following from arctanx+arccotx=2π.
Fact: π hides in the arctangent slope
Writing 1+x21=1−x2+x4−⋯ and undoing the derivative gives arctanx=x−3x3+5x5−⋯, so 4π=arctan1=1−31+51−⋯. The Kerala school credited this to Madhava, around 1400, long before Gregory and Leibniz found it in the 1670s.
To derive the arctangent formula: let y=arctanx, so tany=x. Differentiating: sec2y⋅dxdy=1. Using the identity sec2y=1+tan2y=1+x2 gives dxdy=1+x21.
Unlike arcsine and arccosine, arctangent is defined for all real x—no domain restriction. The derivative 1+x21 is always positive, confirming that arctanx is strictly increasing. As x→±∞, the derivative approaches zero, reflecting the horizontal asymptotes y=±2π. The function rises everywhere but flattens out at the extremes.
This derivative appears prominently in integration: ∫1+x21dx=arctanx+C.
arctan x and its derivative
The derivative 1/(1 + x²) is positive for every x, so arctan x rises everywhere. It is largest, 1, at x = 0, where the graph is steepest, and it fades toward 0 in both directions, so the graph flattens against the dashed asymptotes y = ±π/2 without ever reaching them.
The same 1/(1 + x²) is the integrand whose antiderivative is arctan x + C.
Inverse Trigonometric Functions — Arcsecant and Arccosecant
The derivation for arcsecant: let y=arcsecx, so secy=x. Differentiating: secytany⋅dxdy=1. Since secy=x and tany=±sec2y−1=±x2−1, the sign depends on the quadrant. The absolute value ∣x∣ in the formula resolves this: secytany=∣x∣x2−1 across the full domain.
These derivatives are less frequently encountered than the arcsine and arctangent versions. They appear primarily in integrals of the form ∫xx2−11dx and in problems involving trigonometric substitution.
The domain ∣x∣>1 reflects the range of secant: secy never takes values between −1 and 1.
Patterns in Inverse Trigonometric Derivatives
The six inverse trigonometric derivatives organize into three pairs, each pair summing to zero:
(arcsinx)′+(arccosx)′=0, both involving 1−x21
(arctanx)′+(arccotx)′=0, both involving 1+x21
(arcsecx)′+(arccscx)′=0, both involving ∣x∣x2−11
Each pair shares the same magnitude because the two functions in each pair sum to a constant (2π). The cofunction always carries the negative sign—the same pattern seen in the common trigonometric derivatives where cos, cot, and csc derivatives are negative.
Three distinct algebraic forms appear: 1−x2 for the sine/cosine pair, 1+x2 for the tangent/cotangent pair, and ∣x∣x2−1 for the secant/cosecant pair. These three expressions reappear in integration, where recognizing them triggers the corresponding inverse trigonometric antiderivative. The table below collects the three algebraic forms alongside their cofunction pairs and the identity that explains why each pair shares the same magnitude.
Algebraic form (magnitude)
Cofunction pair
Why they share the same magnitude
1 ⁄ √(1 − x2)
arcsin x ↔ arccos x
arcsin x + arccos x = π ⁄ 2, so the two derivatives sum to zero
1 ⁄ (1 + x2)
arctan x ↔ arccot x
arctan x + arccot x = π ⁄ 2, so the two derivatives sum to zero
1 ⁄ (|x| √(x2 − 1))
arcsec x ↔ arccsc x
arcsec x + arccsc x = π ⁄ 2, so the two derivatives sum to zero
Two functions that add up to a constant have opposite derivatives, so the six formulas are really three.
Hyperbolic Functions
The hyperbolic functions are defined through exponentials:
Hyperbolic Functions
sinhx=2ex−e−xcoshx=2ex+e−xtanhx=coshxsinhx
Their derivatives parallel the trigonometric pattern:
The critical difference from trigonometric derivatives: (coshx)′=sinhx carries no negative sign, whereas (cosx)′=−sinx does. This single sign difference propagates through all six formulas.
Pitfall: Copying the sign of sec x
Taking over (secx)′=secxtanx gives (sechx)′=sechxtanhx, positive for x>0. But sechx=coshx1 falls there as coshx grows; the derivative is −sechxtanhx.
Each derivative is verified directly by differentiating the exponential definitions. For sinhx: dxd[2ex−e−x]=2ex+e−x=coshx. No special limits or implicit differentiation are needed—the exponential derivative does all the work.
Inverse Hyperbolic Functions
The inverse hyperbolic functions have derivatives that resemble the inverse trigonometric ones with sign changes under the radical:
A Mercator map draws latitude φ at height arctanh(sinφ), in Earth radii. Its rate of growth, 1−sin2φcosφ=secφ, matches the map's east-west stretch at that latitude, which is why small shapes keep their angles.
Compare with inverse trigonometric derivatives: 1−x2 becomes x2+1 or x2−1, and 1+x2 becomes 1−x2. The signs inside the expressions flip.
These derivatives can be established through implicit differentiation or through the logarithmic representations. For instance, arcsinhx=ln(x+x2+1). Differentiating this logarithmic form directly using the chain rule confirms x2+11.
Inverse hyperbolic derivatives appear in integration: ∫x2+11dx=arcsinhx+C and ∫x2−11dx=arccoshx+C provide alternatives to trigonometric substitution for certain radical integrals.
Piecewise Functions
A piecewise function uses different formulas on different intervals. On each interval's interior, standard differentiation rules apply to the governing formula. The derivative of the piecewise function is itself piecewise—computed piece by piece.
The challenge lies at the boundaries.
RULE
At a point x=c where the formula changes, the derivative exists only if three conditions hold: the function is continuous at c (the pieces connect), the left-hand derivative exists, and the right-hand derivative exists and equals the left-hand derivative.
Consider f(x)=x2 for x≤1 and f(x)=2x−1 for x>1. Continuity at x=1: f(1)=1 from the left, 2(1)−1=1 from the right—they match. Left derivative at 1: dxd[x2]x=1=2. Right derivative at 1: dxd[2x−1]x=1=2. Both derivatives match, so f′(1)=2.
Pitfall: Comparing slopes without checking continuity
For f(x)=x2 when x≤1 and f(x)=2x when x>1, both pieces have slope 2 at x=1, which suggests f′(1)=2. But the pieces give the values 1 and 2 there: the graph jumps, and f′(1) does not exist.
If either continuity fails or the one-sided derivatives disagree, the function is not differentiable at that boundary. The absolute value function ∣x∣ is the canonical example: continuous at x=0, but left derivative −1 and right derivative +1 do not match. The table below names each of the three boundary conditions, what it requires, and the failure mode that appears when it is violated.
A boundary where the pieces join smoothly
The section’s f(x) = x² for x ≤ 1 and 2x − 1 for x > 1. Both pieces give the value 1 at x = 1, so the graph is unbroken, and both have slope 2 there. The dashed lines continue each piece past the boundary: the line 2x − 1 is exactly the tangent to x² at x = 1. Same value and same slope from both sides means f′(1) = 2 exists.
Replacing 2x − 1 by 3x − 2 keeps the value 1 at x = 1 but gives slope 3: a corner.
Condition at boundary x = c
What it requires
Failure mode if violated
Continuity at c
the two pieces meet: the left and right values both equal f(c)
jump discontinuity — no tangent line possible
One-sided derivatives exist
both the left-hand and right-hand derivatives at c are finite
vertical tangent or cusp — slope is infinite or undefined on one side
One-sided derivatives agree
left derivative at c equals right derivative at c
corner — e.g., |x| at 0, where the slopes are −1 and +1
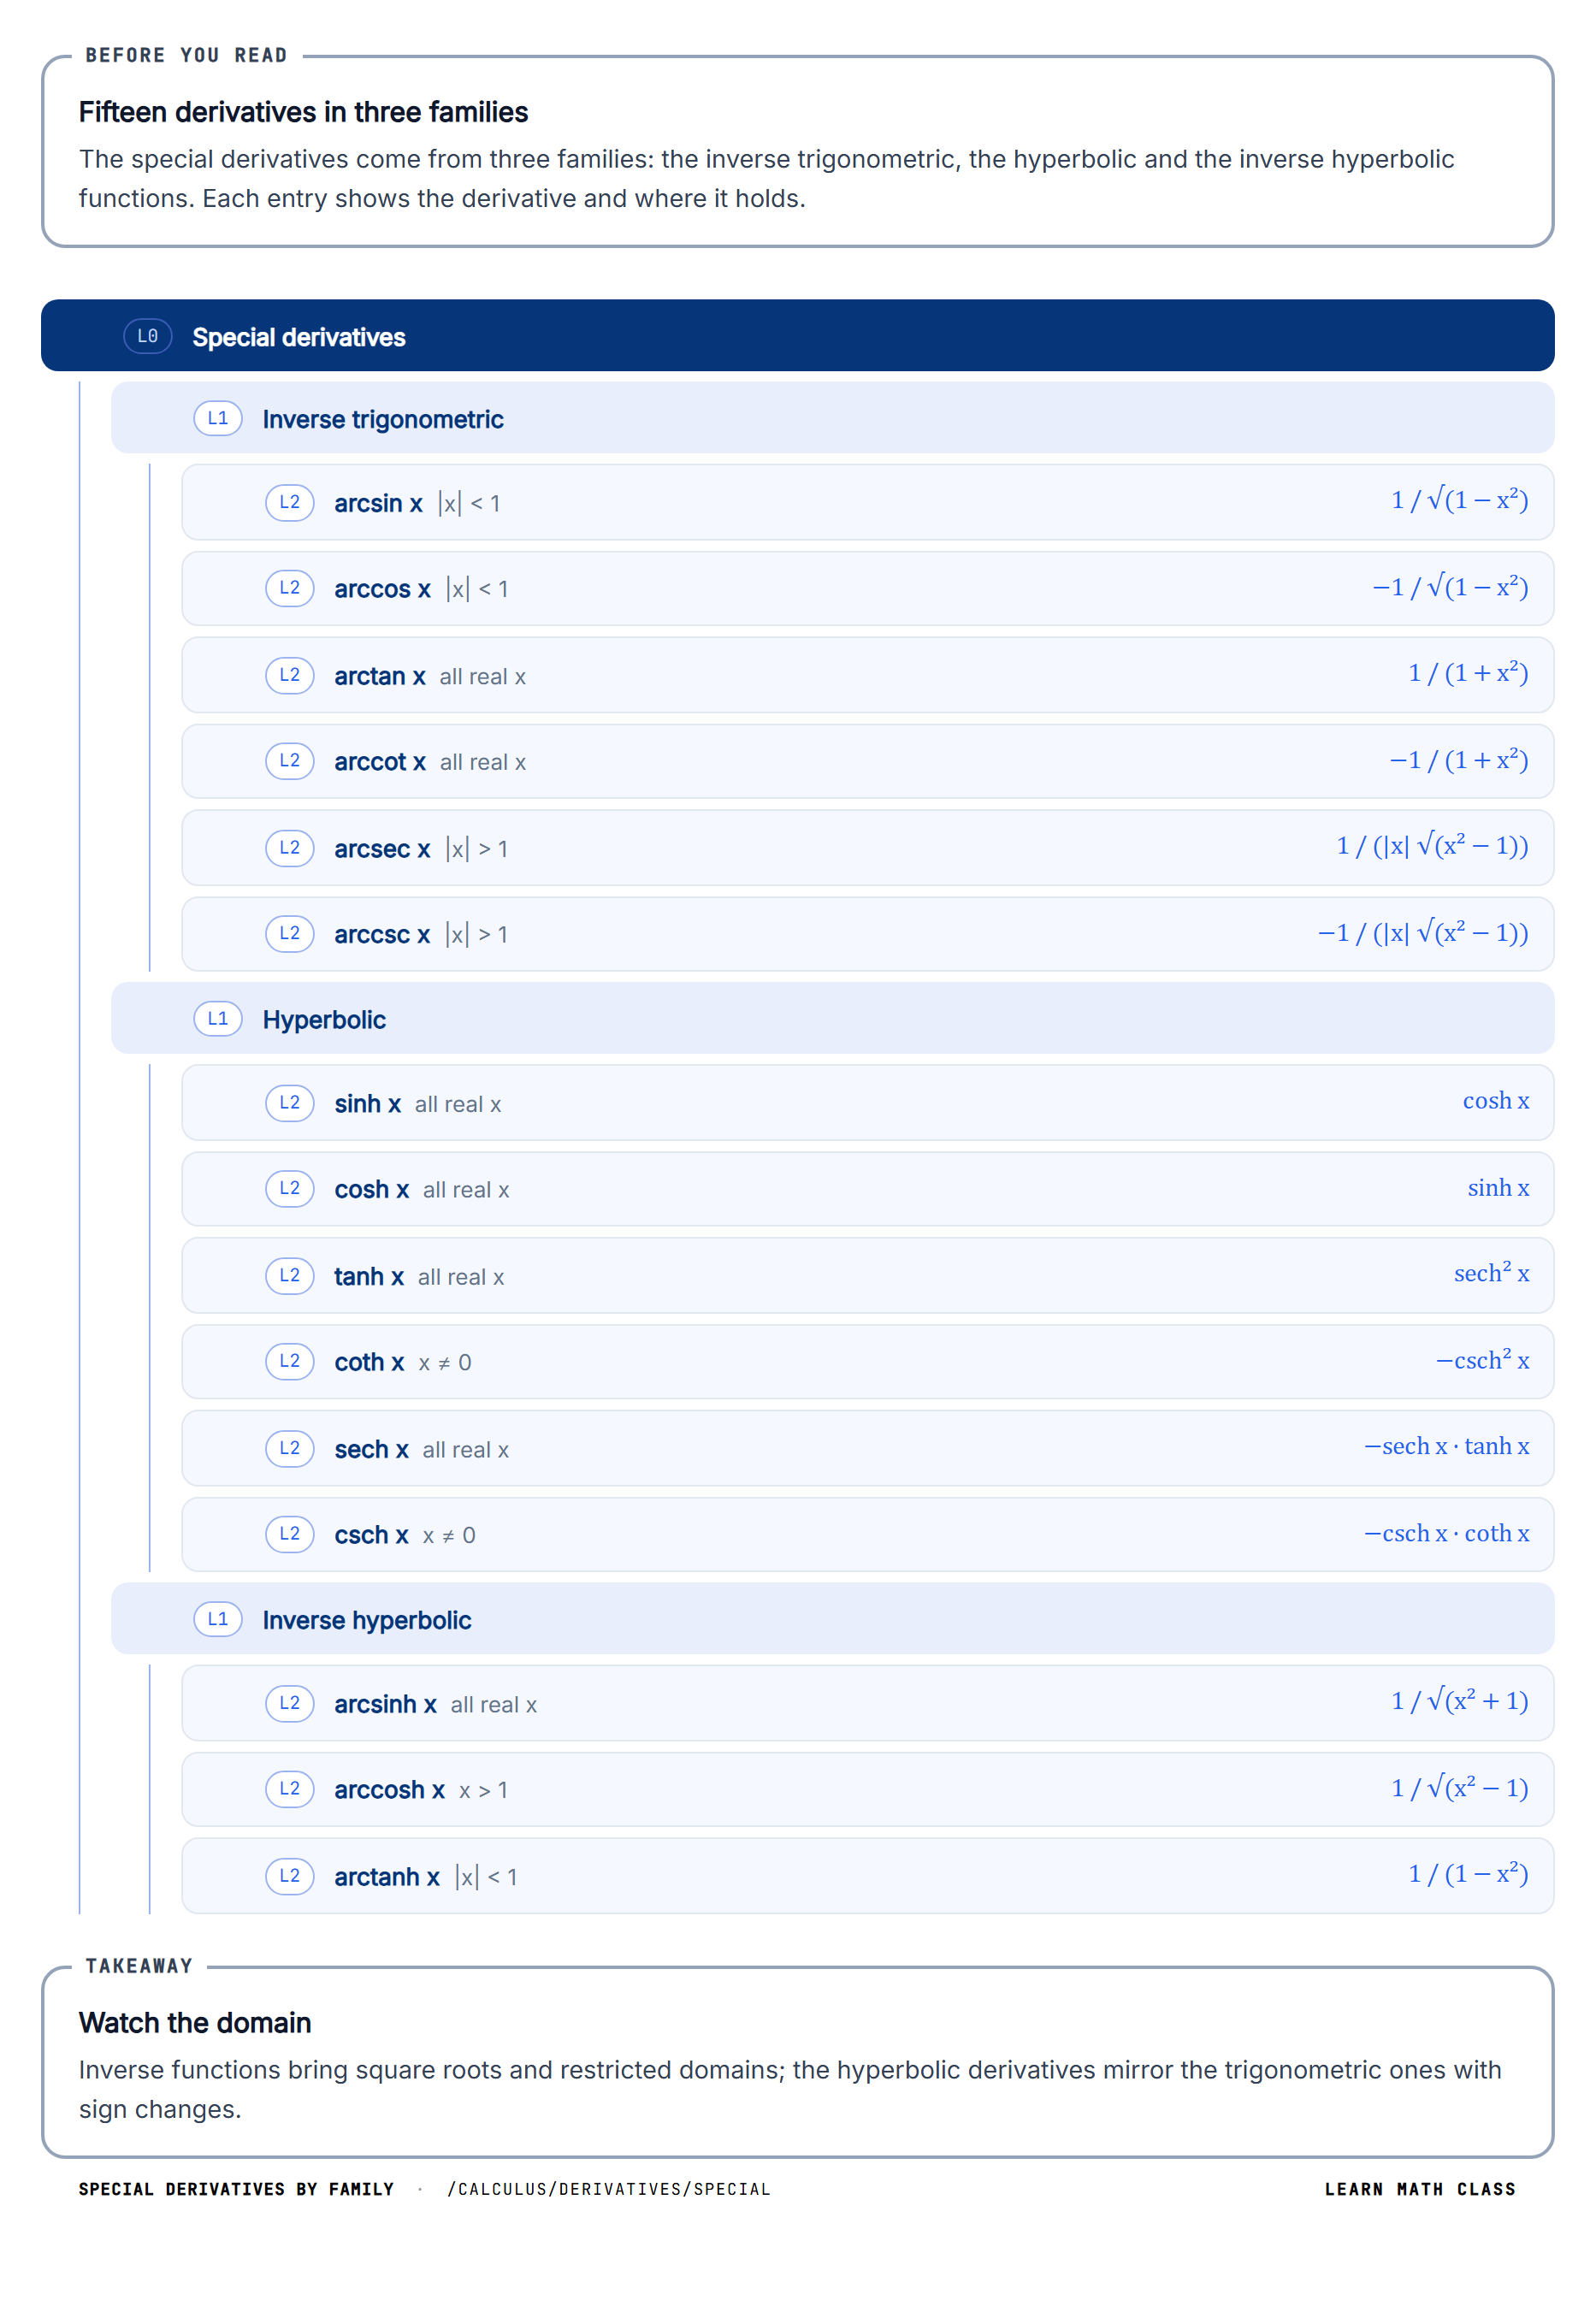
Together with the common derivatives, these formulas cover every standard function encountered in calculus. Recognizing the algebraic forms—1−x2, 1+x2, x2±1, 1−x2—is equally important for integration, where these expressions signal inverse trigonometric or inverse hyperbolic antiderivatives. The table below assembles all 15 formulas as a single reference card, organized by category and including the domain on which each derivative is valid.
The special derivatives come from three families: the inverse trigonometric, the hyperbolic and the inverse hyperbolic functions. Each entry shows the derivative and where it holds.
L0Special derivatives
L1Inverse trigonometric
L2arcsin x|x| < 11 / √(1 − x²)
L2arccos x|x| < 1−1 / √(1 − x²)
L2arctan xall real x1 / (1 + x²)
L2arccot xall real x−1 / (1 + x²)
L2arcsec x|x| > 11 / (|x| √(x² − 1))
L2arccsc x|x| > 1−1 / (|x| √(x² − 1))
L1Hyperbolic
L2sinh xall real xcosh x
L2cosh xall real xsinh x
L2tanh xall real xsech² x
L2coth xx ≠ 0−csch² x
L2sech xall real x−sech x · tanh x
L2csch xx ≠ 0−csch x · coth x
L1Inverse hyperbolic
L2arcsinh xall real x1 / √(x² + 1)
L2arccosh xx > 11 / √(x² − 1)
L2arctanh x|x| < 11 / (1 − x²)
Takeaway
Watch the domain
Inverse functions bring square roots and restricted domains; the hyperbolic derivatives mirror the trigonometric ones with sign changes.
Four mistakes cause many of the wrong answers when these formulas are used. Each is marked where it happens in the sections above; here each is worked through in full, with the wrong and the right working side by side.
Forgetting the chain rule
The formulas on this page are stated for the bare variable x. When the argument is an expression such as 2x, that expression is put into the formula, but the derivative of the inside is left out.
Right working: with u=2x and u′=2, dxd[arcsinu]=1−u2u′=1−4x22.
Why it happens: the inner expression is copied into the formula correctly, so the result looks complete. The missing factor is invisible when the inside is a plain x, which is the only case the formulas show.
How to check: compare with the slope measured from the graph. At x=0.25 the slope of arcsin(2x) is about 2.309, which matches 0.752≈2.309; the wrong formula gives 0.751≈1.155, half as much.
Dropping the absolute value
The arcsecant derivative is written as xx2−11, without the absolute value. For x>1 this agrees with the formula, but for x<−1 it has the wrong sign.
Wrong working: at x=−2, xx2−11=−231≈−0.289.
Right working: at x=−2, ∣x∣x2−11=231≈0.289.
Why it happens: the derivation gives secytany1, and replacing secy by x and tany by x2−1 looks natural. On the branch where x<−1, both secy and tany are negative, so their product is positive, and the absolute value records exactly that.
How to check: compare nearby values of the function. arcsec(−2.1)≈2.067 and arcsec(−1.9)≈2.125, so the function rises near x=−2, at a rate of about 0.22.125−2.067≈0.29. The slope must be positive.
Copying the sign of sec x
The hyperbolic derivatives are written by analogy with the trigonometric ones, sign included. Since (secx)′=secxtanx has no minus sign, none is expected for sechx either.
Wrong working: dxd[sechx]=sechxtanhx.
Right working: sechx=(coshx)−1, so dxd[sechx]=−(coshx)−2sinhx=−coshx1⋅coshxsinhx=−sechxtanhx.
Why it happens: differentiating a reciprocal always produces a minus sign. For secx it is cancelled by the minus sign in (cosx)′=−sinx, which leaves secxtanx positive. For sechx there is nothing to cancel it, because (coshx)′=sinhx has no minus sign.
How to check: sech0=1 and sech1≈0.648, so the function falls for x>0, where tanhx>0. A derivative of sechxtanhx would be positive there; the right formula gives about −0.494 at x=1.
Comparing slopes without checking continuity
At a boundary, the two pieces are differentiated and their slopes at the boundary are compared, but nobody checks that the pieces meet. Matching slopes are then taken as the derivative.
Wrong working: for f(x)=x2 when x≤1 and f(x)=2x when x>1, the slopes are dxd[x2]x=1=2 and dxd[2x]=2, so f′(1)=2.
Right working: check the values first. From the left f(1)=1; from the right 2x→2 as x→1+. The pieces do not meet, f is not continuous at 1, and f′(1) does not exist.
Why it happens: differentiating removes a constant term, so two pieces that differ by a constant have the same derivative. Here 2x and the section's 2x−1 both have slope 2; only their values at x=1 tell them apart.
How to check: compute the difference quotient from the right. hf(1+h)−f(1)=h2(1+h)−1=h1+2h, which is 102 at h=0.01 and grows without bound as h→0+.
Special Derivatives FAQ
What is the derivative of arcsin x?
+
The derivative of arcsin x is 1/√(1 − x²), valid for |x| < 1. Set y = arcsin x so that sin y = x, differentiate implicitly to get cos y · dy/dx = 1, and use cos y = √(1 − sin²y), positive because y lies in [−π/2, π/2]. At x = ±1 the denominator vanishes, which is why the graph has vertical tangents at its endpoints.Read more →
What is the derivative of arctan x?
+
The derivative of arctan x is 1/(1 + x²), valid for every real x — unlike arcsine, there is no domain restriction. Set y = arctan x so tan y = x, differentiate to get sec²y · dy/dx = 1, then use sec²y = 1 + tan²y = 1 + x². The result is always positive, so arctan x is strictly increasing.Read more →
Why does the derivative of arcsec x have an absolute value?
+
Because the sign of tan y depends on the quadrant. Setting y = arcsec x gives sec y · tan y · dy/dx = 1, and tan y = ±√(x² − 1) — positive on one branch of the domain, negative on the other. Writing sec y · tan y as |x|√(x² − 1) makes a single formula correct across the whole domain |x| > 1.Read more →
Why is the derivative of cosh x positive when the derivative of cos x is negative?
+
Because the hyperbolic functions are built from e^x and e^(−x) rather than from rotation. Differentiating cosh x = (e^x + e^(−x))/2 gives (e^x − e^(−x))/2, which is sinh x — no sign flip appears anywhere. The trigonometric minus sign comes from the circle; the hyperbola produces none. That one difference propagates through all six hyperbolic formulas.Read more →
What is the derivative of arcsinh x?
+
The derivative of arcsinh x is 1/√(x² + 1), valid for all real x. Compare arcsin, whose derivative is 1/√(1 − x²): the signs inside the radical flip, which is the general relationship between inverse trigonometric and inverse hyperbolic derivatives. It follows from the logarithmic form arcsinh x = ln(x + √(x² + 1)) differentiated by the chain rule.Read more →