Most functions resist direct antidifferentiation. The integral of ex2 has no elementary formula. Even innocuous-looking expressions like 1+x3 lack closed-form antiderivatives.
Integration techniques transform difficult integrals into tractable ones. Substitution reverses the chain rule. Integration by parts reverses the product rule. Partial fractions decompose rational functions. Trigonometric methods handle roots and powers.
No single algorithm covers all cases—unlike differentiation, which follows systematic rules. Success requires recognizing which technique applies and executing it correctly. This pattern-matching skill develops through practice.
Key Terms
Integrand— the expression being transformed into a recognizable form
Differentiation follows mechanical rules: the derivative of any elementary function can be computed by applying chain, product, and quotient rules systematically.
Integration has no such universal algorithm.
THEOREM
Some elementary functions have no elementary antiderivative.
Others have antiderivatives that are difficult to find without insight.
Techniques bridge this gap. They transform integrands into forms matching known formulas. The transformation might involve changing variables, splitting products, or decomposing fractions—whatever reveals the underlying structure.
Substitution (u-Substitution)
Substitution reverses the chain rule. If the integrand contains a function and its derivative, substitution simplifies.
Method: Let u=g(x), so du=g′(x)dx. Replace all x-expressions with u-expressions and integrate.
The bounds of a definite integral are values of the variable of integration. In ∫022xcos(x2)dx the numbers 0 and 2 are values of x; after the substitution u=x2 the integral runs over values of u, and the antiderivative sinu is a function of u. Converting the bounds at the moment of substitution means the evaluation never has to return to x.
Notation Inside the Techniques
Notation
Notation Inside the Techniques
Substitution's paired equations, the four-slot ledger of parts, and the substitution that runs backwards — the bookkeeping is the technique.
Let u equal g of x, so d u equals g prime of x, d x
A change of name recorded as two equations — and the second is real differential algebra, not ritual. Everything must convert: integrand, dx, all of it, as in Substitution above.
CasesIn a definite integral the bounds convert too, and the transition is often labelled on the sign itself: ∫x=ax=b becomes ∫u=g(a)u=g(b) — after which there is no going back to x. The alternative workflow keeps the x-bounds and back-substitutes u=g(x) before evaluating; both are legal, mixing them is not.
Also writtenw or t when u is spoken for; the final return to x is the “back-substitution” step.
Do not confuseA partial conversion. ∫cosudx — one variable in the integrand, another in the differential — is meaningless; a leftover x under a du means the substitution was not completed.
∫udv=uv−∫vdu
The integral of u d v equals u v minus the integral of v d u
Parts factors the integrand into two slots: u, destined for differentiation, and dv, destined for integration — and dv swallows the dx. The four-slot ledger u,du,dv,v organises the whole computation in Integration by Parts below.
CasesChoosing u follows LIATE — logarithmic, inverse trig, algebraic, trigonometric, exponential — a classroom mnemonic, not a theorem; it fails often enough to keep judgment in the loop.
Also written∫uv′dx=uv−∫u′vdx — the prime form, standard in European texts, where the differential never appears bare.
Do not confuseSubstitution's u. Same letter, different job: substitution's urenames the variable; parts' ulabels a factor and x remains the variable throughout. Writing dv without its dx is the commonest ledger slip.
x=asinθ
Let x equal a sine theta
Substitution running backwards: the old variable is expressed through the new one, opposite in direction to u=g(x). The radical collapses through a Pythagorean identity, as in Trigonometric Substitution below.
CasesThree radical shapes, three choices: a2−x2→x=asinθ; a2+x2→x=atanθ; x2−a2→x=asecθ. The answer returns to x through θ=arcsinax and a reference triangle.
Also writtenHyperbolic versions — x=asinht — in analysis and European texts, trading the identity 1−sin2=cos2 for cosh2−sinh2=1.
Do not confuseThe u-direction. Here the new variable is not a function of x you can read off — inverting requires the inverse trig functions, and the domain restriction on θ is what makes the inversion legal.
Method: Identify factors u and dv in the integrand. Differentiate u to get du; integrate dv to get v. Apply the formula.
Example
∫xexdx
Let u=x and dv=exdx. Then du=dx and v=ex:
=xex−∫exdx=xex−ex+C=ex(x−1)+C
Pitfall: Dropping the minus sign
Adding the second integral instead of subtracting it gives ∫xexdx=xex+ex+C, whose derivative is xex+2ex. Subtracting gives xex−ex+C, whose derivative is xex.
The formula comes from integrating the product rule (uv)′=u′v+uv′ and solving for ∫udv, which is why the second integral is subtracted. In the example, u=x and v=ex give uv=xex, and the integral left over, ∫vdu=∫exdx, is simple enough to finish at once.
The formula accepts any split of the integrand, even an odd one. For ∫x1dx, take u=x1 and dv=dx; then du=−x21dx and v=x, and the formula gives ∫x1dx=x⋅x1−∫x(−x21)dx=1+∫x1dx. The split is legal, but it only returns the integral it started from.
Fact: Parts seems to prove 0=1
Subtracting ∫x1dx from both sides of ∫x1dx=1+∫x1dx leaves 0=1. Nothing is broken: each indefinite integral stands for the whole family ln∣x∣+C, and two members of that family may differ by 1.
Choosing the first factor: LIATE guides selection—Logarithmic, Inverse trig, Algebraic, Trigonometric, Exponential. Earlier types typically make better choices for u.
The two splits above show what the choice decides. In both, the formula moves the derivative from v to u: with u=x in ∫xexdx the integral left behind is ∫exdx, simpler than the original, while u=x1 in ∫x1dx leaves the original integral unchanged. A choice is good when the factor chosen as u becomes simpler after differentiation and dv can still be integrated.
Integration by parts moves the derivative from one factor to the other, and it pays off only when the integral left behind is simpler.
Trigonometric Integrals
Integrals involving powers of sine and cosine require strategic use of identities.
Odd power of sine: Save one sinx, convert remaining sin2x=1−cos2x, substitute u=cosx.
Odd power of cosine: Save one cosx, convert remaining cos2x=1−sin2x, substitute u=sinx.
Both powers even: Use half-angle identities:
Trigonometric Integrals
sin2x=21−cos2xcos2x=21+cos2x
Example
∫sin3xdx=∫sinx(1−cos2x)dx
Let u=cosx:
=−∫(1−u2)du=−u+3u3+C=−cosx+3cos3x+C
Pitfall: Losing the sign of du
Taking du=sinxdx for u=cosx gives ∫sin3xdx=cosx−3cos3x+C, whose derivative is −sin3x. With du=−sinxdx the answer is −cosx+3cos3x+C.
The saved factor sinx is what makes the substitution possible: together with dx it is matched against du for u=cosx, and the remaining even power becomes a polynomial in u. For an odd power of cosine the roles swap, and cosxdx is matched against du for u=sinx. In both cases the answer can be checked by differentiating it back to the integrand.
Power pattern
Strategy
Substitution
Odd power of sin x
save one sin x, rewrite the rest using sin²x = 1 − cos²x
u = cos x, du = −sin x dx
Odd power of cos x
save one cos x, rewrite the rest using cos²x = 1 − sin²x
u = sin x, du = cos x dx
Both powers even
apply half-angle identities to lower the powers
none directly — reduce, then integrate term by term
Trigonometric Substitution
Square roots of quadratics suggest trigonometric substitutions.
Fora2−x2: Let x=asinθ, so a2−x2=acosθ
Fora2+x2: Let x=atanθ, so a2+x2=asecθ
Forx2−a2: Let x=asecθ, so x2−a2=atanθ
Example
∫1−x21dx
Let x=sinθ, so dx=cosθdθ and 1−x2=cosθ:
=∫cosθcosθdθ=∫dθ=θ+C=arcsinx+C
Pitfall: Replacing dx with dθ
Swapping dx for dθ without the factor cosθ leaves ∫cosθdθ=ln∣secθ+tanθ∣+C, a different function. With dx=cosθdθ the cosines cancel and the answer is arcsinx+C.
The substitution x=sinθ is applied to the whole integral. It rewrites the radical 1−x2 as cosθ, and differentiating it gives the differential dx in terms of dθ; the integrand in θ is built from both. At the end, θ=arcsinx returns the answer to the original variable.
Radical in integrand
Substitution
Radical simplifies to
√(a² − x²)
x = a sin θ
a cos θ
√(a² + x²)
x = a tan θ
a sec θ
√(x² − a²)
x = a sec θ
a tan θ
A trigonometric substitution trades a square root for a Pythagorean identity, and the radical collapses to a single trigonometric factor.
Partial Fractions
Rational functions—polynomials divided by polynomials—decompose into simpler fractions.
Method: Factor the denominator. Write the fraction as a sum of terms with linear or irreducible quadratic denominators. Solve for coefficients. Integrate each term.
Example
∫x2−11dx=∫(x−1)(x+1)1dx
Decompose:
(x−1)(x+1)1=x−1A+x+1B
Solving gives A=1/2, B=−1/2:
=21∫x−11dx−21∫x+11dx=21ln∣x−1∣−21ln∣x+1∣+C
Pitfall: Taking the log of the whole denominator
Writing ln∣x2−1∣+C for ∫x2−11dx gives a function whose derivative is x2−12x, not x2−11. The decomposition gives 21ln∣x−1∣−21ln∣x+1∣+C.
Each simple fraction integrates on its own: a constant over a linear factor x−r gives that constant times ln∣x−r∣, because the derivative of x−r is 1. The two logarithms can be combined at the end into 21lnx+1x−1+C, a single term with the same derivative.
A fraction taken apart
The section’s 1/(x² − 1) (blue) has two vertical asymptotes, at x = −1 and x = 1. The decomposition writes it as (1/2)/(x − 1) (amber dashes), which carries only the asymptote at 1, plus −(1/2)/(x + 1) (navy dashes), which carries only the one at −1. Adding the two dashed curves point by point gives the blue curve, and each simple piece integrates to a logarithm.
Each factor of the denominator contributes one simple fraction with its own asymptote.
Choosing the Right Technique
Pattern recognition guides technique selection.
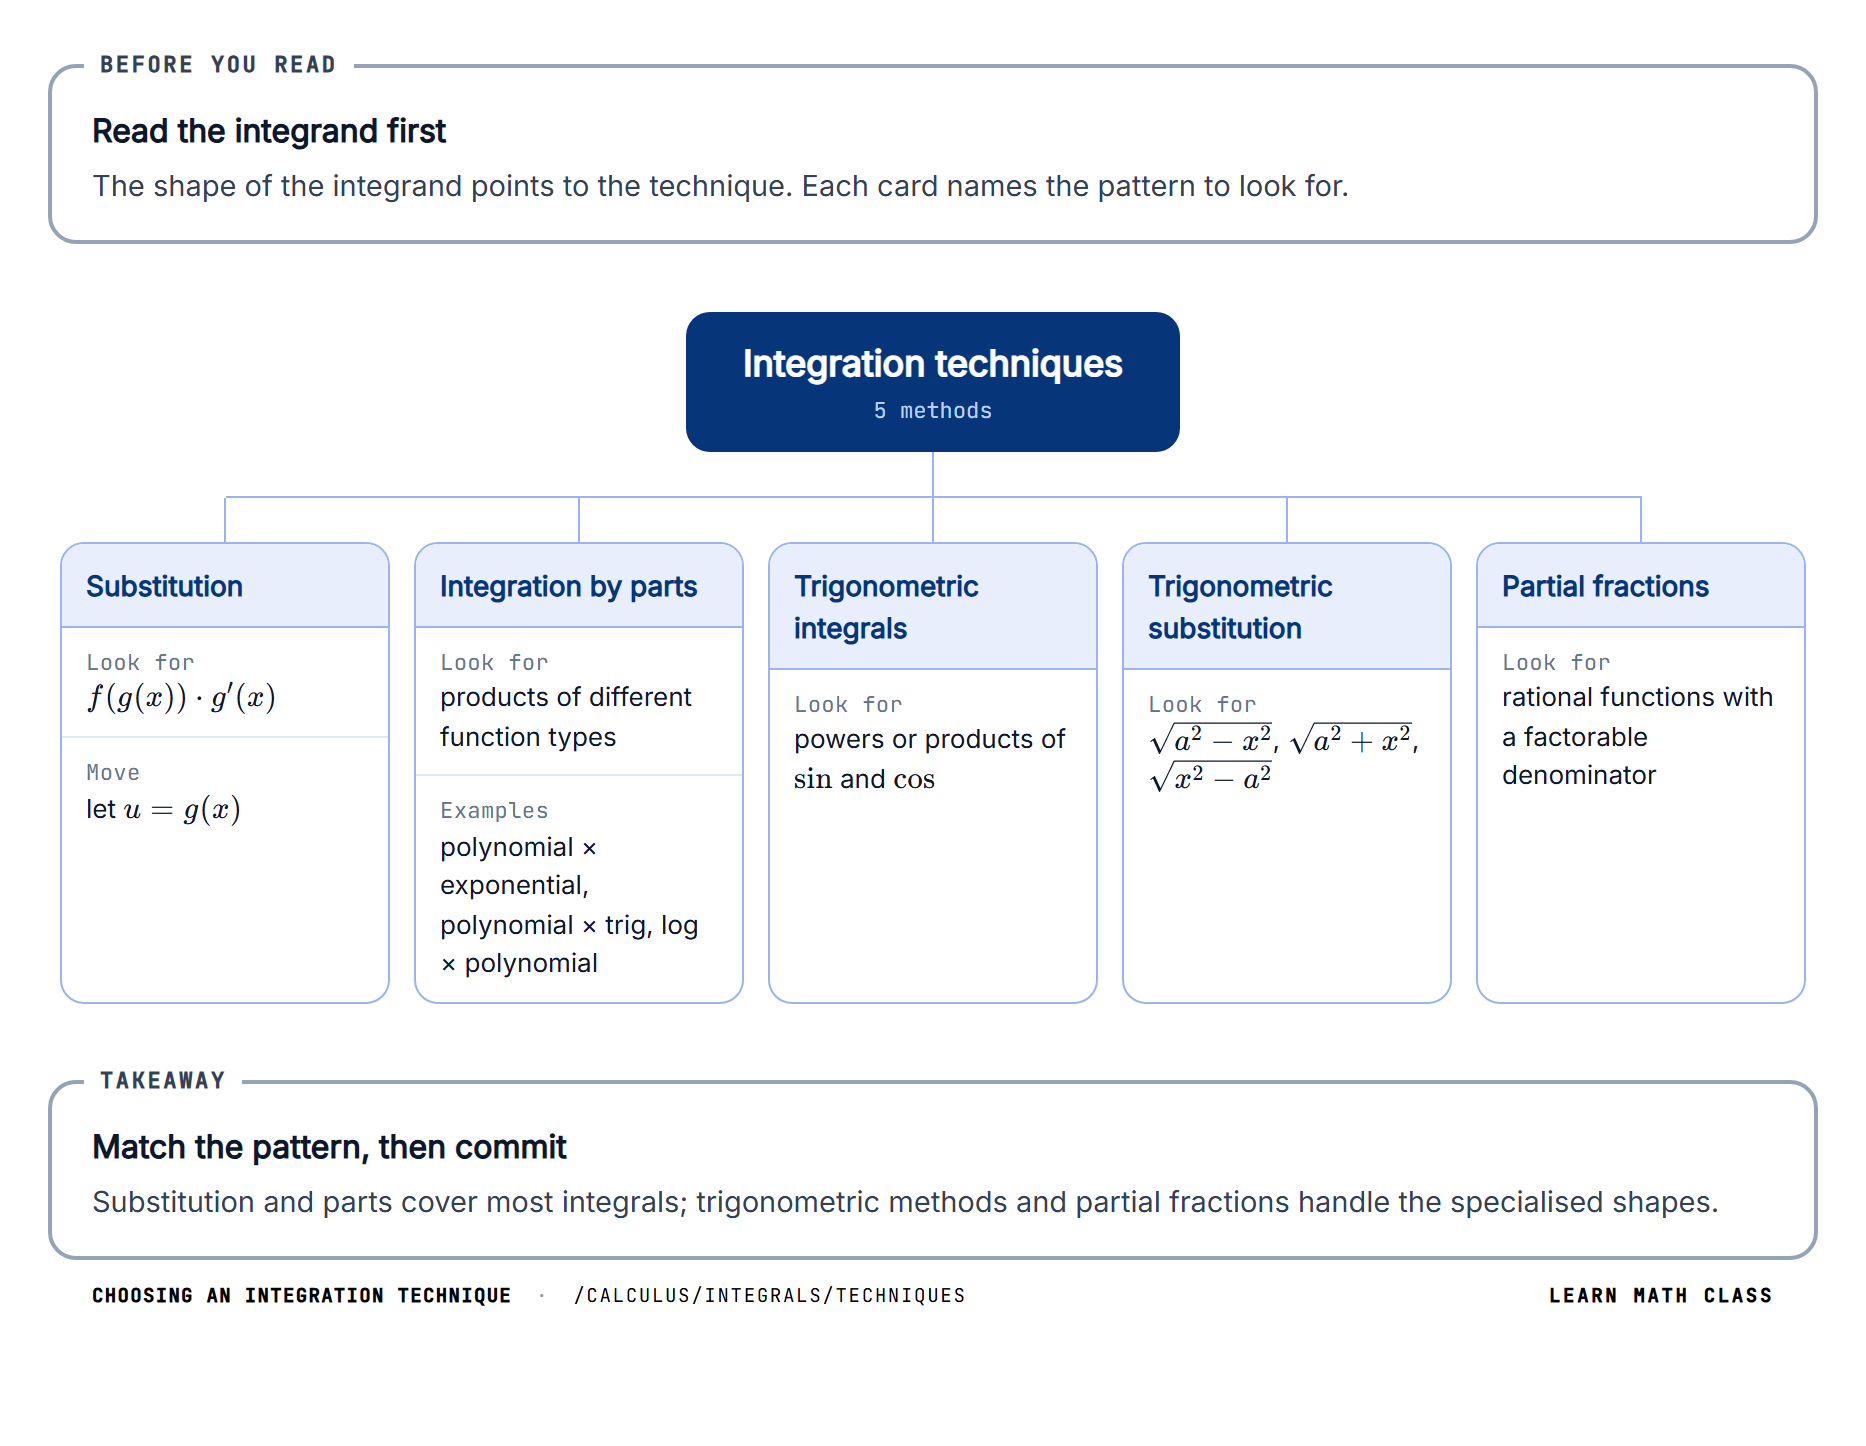
Substitution: Look for a function paired with its derivative. Expressions like f(g(x))⋅g′(x) signal substitution with u=g(x).
Parts: Products of different function types—polynomial times exponential, polynomial times trigonometric, logarithm times polynomial.
Trigonometric integrals: Powers of sinx and cosx, products of trigonometric functions.
Trigonometric substitution: Square roots of a2−x2, a2+x2, or x2−a2.
Partial fractions: Rational functions with factorable denominators.
Fact: One substitution for every trig fraction
With t=tan2x, sinx=1+t22t, cosx=1+t21−t2 and dx=1+t22dt. Every rational expression in sinx and cosx becomes a rational function of t, so partial fractions can always finish it.
Multiple techniques often combine. A problem might require substitution followed by parts, or partial fractions followed by a trigonometric integral.
Some combinations are planned from the start. An integrand such as 2+cosx1 is a fraction built from cosx, with no odd power to save and no radical to replace, so none of the trigonometric patterns above fits it directly. A substitution can still turn it into a rational function of a new variable, and partial fractions take over from there.
The techniques covered above all share the same goal—reshape the integrand until it matches a known formula—but each one reverses a different differentiation rule and is triggered by a different signal in the integrand. The table below collects all five in one place, pairing each technique with what it reverses, the pattern that signals it, the standard setup, and a canonical example. Read the "Recognize when…" column first when scanning an unfamiliar integral; read across the row once a match is found.
Technique
What it reverses
Recognize when…
Setup
Example trigger
u-substitution
chain rule
integrand contains a function and its derivative
u = g(x), du = g'(x) dx; rewrite and integrate in u
x = a sin θ, a tan θ, or a sec θ depending on the radical
∫ 1 / √(1 − x²) dx
Partial fractions
addition of rational fractions
rational function with a factorable denominator
decompose into A/(x − r) + B/(x − s) + … and integrate each piece
∫ 1 / (x² − 1) dx
Common Pitfalls
Five mistakes cause many of the wrong answers when these techniques are carried out. Each is marked where it happens in the sections above; here each is worked through in full, with the wrong and the right working side by side.
Keeping the x-bounds after substituting
In a definite integral, the integrand and dx are rewritten in u, but the bounds are left as they were. The antiderivative in u is then evaluated at numbers that are values of x.
Wrong working: with u=x2, ∫022xcos(x2)dx becomes ∫02cosudu=sin2−sin0≈0.909.
Right working: when x=0, u=0; when x=2, u=4. So the integral is ∫04cosudu=sin4−sin0≈−0.757.
Why it happens: the bounds are written once, at the start, and are read as part of the integral sign rather than as values of a particular variable.
How to check: take the other route. Back-substitute to get the antiderivative sin(x2) and evaluate it at the x-bounds: sin(22)−sin(02)=sin4. The two routes must agree.
Dropping the minus sign
In integration by parts, uv−∫vdu is written with a plus sign, so the second integral is added instead of subtracted.
Wrong working: ∫xexdx=xex+∫exdx=xex+ex+C.
Right working: ∫xexdx=xex−∫exdx=xex−ex+C=ex(x−1)+C.
Why it happens: the product rule has a plus sign, and the parts formula is remembered by its shape. The minus only appears when ∫vdu is moved to the other side of the integrated product rule.
How to check: differentiate the answer. (xex+ex)′=xex+2ex, which is not the integrand; (xex−ex)′=ex+xex−ex=xex, which is.
Losing the sign of du
With u=cosx, the differential is taken as du=sinxdx instead of du=−sinxdx, and the whole answer comes out with the wrong sign.
Right working: sinxdx=−du, so the integral is −∫(1−u2)du=−cosx+3cos3x+C.
Why it happens: the derivative of sinx is cosx with no sign, and the same is expected the other way round.
How to check: on [0,π] the integrand sin3x is never negative, so ∫0πsin3xdx must be positive. The right answer gives (1−31)−(−1+31)=34; the wrong one gives −34.
Replacing dx with dθ
In a trigonometric substitution, the radical is rewritten in θ, but dx is replaced by dθ alone, without the factor that comes from differentiating x=sinθ.
Right working: dx=cosθdθ, so ∫cosθcosθdθ=θ+C=arcsinx+C.
Why it happens: in u-substitution the new differential is often just du, and the habit carries over to a substitution that runs the other way, where x is the function of θ.
How to check: differentiate the answer in x. The wrong answer has derivative 1−x21, not 1−x21; at x=0.6 these are 1.5625 and 1.25.
Taking the log of the whole denominator
The rule ∫x1dx=ln∣x∣+C is stretched to any denominator, so x2−11 is integrated straight to a logarithm of x2−1 without being decomposed.
Wrong working: ∫x2−11dx=ln∣x2−1∣+C.
Right working: decompose first. x2−11=x−11/2−x+11/2, so the integral is 21ln∣x−1∣−21ln∣x+1∣+C.
Why it happens: the rule ∫f(x)f′(x)dx=ln∣f(x)∣+C is remembered without its condition. It needs the derivative of the denominator in the numerator, here 2x, and the numerator is 1.
How to check: differentiate. dxdln∣x2−1∣=x2−12x, which at x=2 is 34, while the integrand at x=2 is 31.
Integration Techniques FAQ
Do you have to change the limits when you use u-substitution?
+
You have two legal options, and the only mistake is mixing them. Either convert the bounds — when x = a, u = g(a) — and finish entirely in u, never returning to x; or keep the original x-bounds, back-substitute u = g(x) to get the answer in x, and only then evaluate. Evaluating u-bounds against an x-expression is the error.Read more →
What does it mean if there's a leftover x after substituting?
+
It means the substitution is incomplete, and the expression is meaningless as written. Something like ∫cos u dx mixes one variable in the integrand with another in the differential. Every x must convert, the integrand and the dx alike. A stray x usually signals that the chosen u does not have its derivative present.Read more →
Is the u in integration by parts the same as the u in u-substitution?
+
No — same letter, different job. In substitution, u renames the variable: everything converts and x disappears. In integration by parts, u labels one factor of the integrand and x remains the variable throughout; the ledger is u, du, dv, v. Reading a parts problem as a substitution, or the reverse, is a common source of stuck work.Read more →
Does LIATE always work?
+
No. LIATE — logarithmic, inverse trig, algebraic, trigonometric, exponential — is a classroom mnemonic for choosing u in integration by parts, not a theorem. It picks well most of the time, but it fails often enough that judgment stays in the loop. If the resulting ∫v du is harder than what you started with, swap the roles.Read more →
Why is trigonometric substitution written x = a sin θ instead of u = g(x)?
+
Because it runs backwards. Ordinary substitution names the new variable as a function of the old one; trigonometric substitution expresses the old variable through the new one, which is what lets a Pythagorean identity collapse the radical. The price is that returning to x needs an inverse trig function, a reference triangle, and a domain restriction on θ.Read more →