Visual Tools
Calculators
Tables
Mathematical Keyboard
Converters
Other Tools


Higher Order Derivatives


Differentiating the Derivative


The derivative f′f' is a function in its own right, and functions can be differentiated. Applying the differentiation process to f′f' produces the second derivative f′′f'', which measures how the slope of ff changes. Differentiating again yields f′′′f''', then f(4)f^{(4)}, and so on without limit—provided the relevant limits exist at each stage.

Each successive derivative captures a finer layer of a function's behavior. The first derivative controls direction. The second controls concavity. The third and beyond govern subtler aspects of curvature and, in physics, correspond to jerk, snap, and higher kinematic quantities. At the theoretical level, the entire collection of higher-order derivatives at a point encodes the local shape of a function through its Taylor series.

Key Terms

Higher-Order Derivative— f(n)(x)f^{(n)}(x), differentiating ff a total of nn times
Derivative— the first-order case from which all higher orders follow
Concavity— governed by the second derivative f′′f''
Inflection Point— where f′′f'' changes sign

See All Calculus Definitions →


Definition

You have already taken the derivative of a derivative.
Differentiate f(x)=x3f(x) = x^3 and you get f′(x)=3x2f'(x) = 3x^2, the slope of the curve at each point. Ask how fast that slope is changing and there is only one way to answer: differentiate 3x23x^2, which gives 6x6x. Nothing new was needed — the same operation, applied to its own result.
-5 -4 -3 -2 -1 1 2 3 4 5 -5 -4 -3 -2 -1 1 2 3 4 5 x y f(x) = x³ f′(x) = 3x²
The solid curve is f(x)=x3f(x) = x^3, the dashed one its derivative 3x23x^2; the straight line is the tangent at one point, and its slope is the dashed curve's height there. Differentiating the dashed curve in turn gives 6x6x. The same state is on the derivative visualizer.
The same move turns up in three different places.
In motion. If a position is s(t)=t3s(t) = t^3, its derivative is the velocity 3t23t^2, and the derivative of the velocity is the acceleration 6t6t.
time tposition t³velocity 3t²acceleration 6t
0000
1136
281212
3272718
In the shape of a curve. The slope of y=x3y = x^3 is 3x23x^2; whether that slope is shrinking or growing — whether the curve bends down or up — is the sign of its derivative, 6x6x.
In plain algebra. Keep differentiating x3x^3 and the powers step down until nothing is left.
startoncetwicethree timesfour times
x³3x²6x60
y = x^3 bends down left of 0 and up right of 0xy−2−112−6−4−2246bends down (6x < 0)bends up (6x > 0)y = x³: the slope 3x² falls, then rises; 6x tells which
Left of 00, 6x<06x < 0: the slope shrinks and the curve bends down. Right of 00, 6x>06x > 0: the slope grows and the curve bends up. The dot at 00 is where 6x6x changes sign.
What the three share is a rate of change of a rate of change.
Acceleration is how fast velocity changes; bending is how fast slope changes; each column of the chain is how fast the previous column changes. In every case a derivative is taken, and then the derivative of that result. The surface is different — seconds and metres, curves, powers of xx — and the operation underneath is the same.
The definition
The second derivative of ff is the derivative of f′f'. Each higher-order derivative is the derivative of the one before: the third is the derivative of f′′f'', and the nnth, f(n)f^{(n)}, is ff differentiated nn times.
Definition
f′′(x)=ddx[f′(x)]f''(x) = \frac{d}{dx}[f'(x)]
For f(x)=x3f(x) = x^3: f′′=6xf'' = 6x, f′′′=6f''' = 6, and every derivative after that is 00.
A higher-order derivative is a function, just as the first derivative is.
f′′(x)=6xf''(x) = 6x is a new function with its own graph; evaluated at a point it gives a number, f′′(2)=12f''(2) = 12. It is not a different kind of object from f′f' — only one step further down the same chain.
What the name buys: each fact about it is proved once and used everywhere.
Once "second derivative" is a thing with a name and a symbol, one result serves motion, curves and series at once.
once it has a namewhat it settles
the sign of f″which way a curve bends, and where an inflection is
f″ at a critical pointminimum or maximum, by the second derivative test
s″(t)acceleration, for any motion
every f⁽ⁿ⁾(a)the coefficients of a Taylor series
The chain also has a limit of its own.
COROLLARY
Each order depends on the one below it: f(n)f^{(n)} exists at a point only if f(n−1)f^{(n-1)} exists in a neighbourhood of it and is differentiable there.
The chain fails quickly for functions with corners, and the order at which it fails is what the smoothness classes below measure.
The rest of the page covers the notation for every order, the second derivative and its physical meaning, the patterns that repeated differentiation produces for polynomials, exponentials, sine and cosine, nth-derivative formulas, the link to Taylor series, and smoothness classes.

Notation for Higher-Order Derivatives

Notation

Notation for Higher-Order Derivatives

Four systems, all still in use. Which one a text picks depends on whether the variable of differentiation matters, whether it is time, and whether derivatives are being manipulated as objects.
f′f' and dydx\frac{dy}{dx} are defined on Derivatives. Everything below extends them past order one.
f′f' · f′′f'' · f(n)f^{(n)}
f prime, f double prime, f superscript n in parentheses
Lagrange's system. Primes count the order up to three; past that they stop being countable and a parenthetical superscript takes over: f(4)f^{(4)}, f(n)f^{(n)}. Compact, and silent about the variable — which is why it fails as soon as more than one is in play.
Casesf(0)=ff^{(0)} = f — the zeroth derivative is the function itself, which is what lets a Taylor series start its sum at n=0n = 0. Older European texts write low orders as roman numerals: fivf^{iv}, fvf^{v}.
Also writteny′y', y′′y'' when the function is named by its output rather than by ff. f′′′′f'''' turns up for the fourth, but rarely survives an editor.
Do not confuseThe parentheses are the whole point. fnf^n is a power, f∘nf^{\circ n} is composition with itself, f−1f^{-1} is the inverse. Four meanings compete for one superscript slot, and only the derivative brackets itself.
Same glyph elsewhereThe prime marks a transformed or corresponding object almost everywhere else — A′A' for a mapped point in geometry, x′x' for a transformed coordinate. Nothing to do with rates.
dnydxn\frac{d^n y}{dx^n}
d to the n y, d x to the n
Leibniz's system, extended. Reach for it when the variable of differentiation matters, or when the differential itself is in play. The whole symbol is one operator applied to yy — not a fraction with dnyd^n y over dxndx^n.
CasesSecond derivative: d2ydx2\frac{d^2 y}{dx^2}, read "d two y, d x squared", meaning ddx ⁣(dydx)\frac{d}{dx}\!\left(\frac{dy}{dx}\right). The operator form dndxnf\frac{d^n}{dx^n}f separates the instruction from the target, which is what makes it usable inside differentiation rules.
Also written∂ny/∂xn\partial^n y / \partial x^n once other variables are held fixed; the keyboard carries ∂\partial.
Do not confuseThe exponent sits in two different places: above the dd in the numerator, beside the xx in the denominator. Not a typographical accident — it records that dd is applied nn times while xx is the thing being squared, cubed, and so on in the dimensional bookkeeping.
y˙\dot{y} · y¨\ddot{y}
y dot, y double dot
Newton's notation. Each dot is one derivative with respect to time — never space. Standard in mechanics and differential equations, where the independent variable is always tt.
CasesOne dot, velocity. Two, acceleration. Three is the practical ceiling; beyond that the dots stop being countable and texts revert to y(n)y^{(n)}.
Also writteny˙=dydt\dot{y} = \frac{dy}{dt}, the Leibniz form it abbreviates.
Do not confuseA dot is not a generic derivative mark. x˙\dot{x} where xx varies over space is wrong, not merely unusual — the notation carries its variable inside it.
DnfD^n f
D to the n of f
Euler's operator form. DD means differentiate; the exponent counts applications. Write DxnfD_x^n f when several variables are in play. Used wherever derivatives are handled algebraically rather than computed.
CasesD0f=fD^0 f = f by convention, which is what makes DD usable inside a sum or a polynomial in DD — the basis of operator methods for linear differential equations.
Also writtenD\mathcal{D} where plain DD is needed for something else.
Do not confuseΔ\Delta is the difference operator, not the derivative: Δf=f(x+h)−f(x)\Delta f = f(x+h) - f(x). The two sit side by side in numerical analysis and are separated by a single limit.
Order Lagrange notation Leibniz notation Read aloud
1 f'(x) dy ⁄ dx "f prime" ;  "d y, d x"
2 f''(x) d2y ⁄ dx2 "f double prime" ;  "d two y, d x squared"
3 f'''(x) d3y ⁄ dx3 "f triple prime"
4 and beyond f(4)(x),  f(5)(x) d4y ⁄ dx4,  d5y ⁄ dx5 parentheses distinguish derivative order from an exponent
n (general) f(n)(x) dny ⁄ dxn the nth derivative — a single operator applied n times
-2-112-110xycPf″(c) = 2.60
f″(c) = 2.60: the slope is increasing

The first derivative says whether the curve rises; the second says whether the rise is speeding up. At the marker the tangent slopes are growing as x increases, the curve bends upward, and the readout f″(c) = 2.60 records how fast. Where the readout turns negative the bend has flipped. Watch the number and the bend change together on the concavity and inflection points tool.

The second derivative is the first one whose sign has a shape of its own on the graph.

The Second Derivative


The second derivative f′′(x)f''(x) measures the rate of change of the slope. Where f′′(x)>0f''(x) > 0, the slope f′(x)f'(x) is increasing—the function bends upward (concave up). Where f′′(x)<0f''(x) < 0, the slope is decreasing—the function bends downward (concave down).

Pitfall: Squaring the first derivative
Reading f′′(x)f''(x) or d2ydx2\frac{d^2y}{dx^2} as the square of the first derivative turns y=x3y = x^3 into (3x2)2=9x4(3x^2)^2 = 9x^4, which is never negative. Differentiating twice gives f′′(x)=6xf''(x) = 6x, and f′′(−1)=−6f''(-1) = -6: the curve bends down there.

This information is independent of whether ff itself is increasing or decreasing. A function can rise while decelerating (f′>0f' > 0, f′′<0f'' < 0) or fall while accelerating in the negative direction (f′<0f' < 0, f′′<0f'' < 0). The first and second derivatives describe different aspects of behavior.

The second derivative also powers the second derivative test for classifying critical points. At a point where f′(c)=0f'(c) = 0: if f′′(c)>0f''(c) > 0, the critical point is a local minimum; if f′′(c)<0f''(c) < 0, a local maximum; if f′′(c)=0f''(c) = 0, the test is inconclusive.

Inflection points—where concavity reverses—occur where f′′f'' changes sign. When f′′(c)f''(c) exists, the condition f′′(c)=0f''(c) = 0 is necessary but not sufficient (and f′′f'' may instead fail to exist, as for x1/3x^{1/3} at 00); the sign of f′′f'' must actually switch across cc.

The first derivative says which way a graph is heading; the second says which way it bends.

Physical Interpretation


In kinematics, the first three derivatives of position s(t)s(t) have standard names.

The first derivative s′(t)s'(t) is velocity: the rate of change of position. It tells how fast an object moves and in which direction.

The second derivative s′′(t)s''(t) is acceleration: the rate of change of velocity. Positive acceleration means speeding up (in the positive direction) or decelerating (in the negative direction). The sign of acceleration relative to the sign of velocity determines whether the object is speeding up or slowing down.

Pitfall: Reading negative acceleration as slowing down
Taking s′′(t)<0s''(t) < 0 to mean slowing down fails for s(t)=−t2s(t) = -t^2: at t=1t = 1, s′′(1)=−2s''(1) = -2, yet the speed ∣s′(t)∣=2t|s'(t)| = 2t grows from 22 at t=1t = 1 to 44 at t=2t = 2. Velocity −2-2 and acceleration −2-2 have the same sign, so the object is speeding up.

For the position s(t)=t3s(t) = t^3 from the first section, the velocity is 3t23t^2 and the acceleration is 6t6t. At t=2t = 2 the velocity is 1212 and the acceleration is 1212, both positive, and the table of values there shows the object covering more ground in each second than in the one before. Speed is the size of the velocity, ∣s′(t)∣|s'(t)|; it carries no direction, while velocity and acceleration both do.

The third derivative s′′′(t)s'''(t) is jerk: the rate of change of acceleration. Jerk is felt physically as a sudden push or lurch—smooth motion has low jerk, while abrupt starts and stops produce high jerk. Elevator design, roller coaster engineering, and vehicle ride comfort all involve controlling jerk.

Fact: Why bends start with a spiral
Joining straight track directly to a circular bend would make the sideways acceleration jump from 00 to v2R\frac{v^2}{R} in an instant, an infinite jerk. Railways and highways insert a spiral whose curvature grows in proportion to distance, so the acceleration builds at a steady rate.

Jerk also appears where the speed never changes. A train running at constant speed vv along straight track has no acceleration at all. On a circular bend of radius RR it has a sideways acceleration of v2R\frac{v^2}{R}, directed toward the centre of the circle, which passengers feel as a push toward the outside of the bend. Somewhere between the straight and the bend that acceleration has to appear, and the rate at which it appears is a jerk.

Beyond the third derivative, the terms snap (s(4)s^{(4)}), crackle (s(5)s^{(5)}), and pop (s(6)s^{(6)}) are used in specialized engineering contexts but rarely appear in standard calculus. The table below collects all six in order, with each name paired with what the derivative measures.
Order Derivative of position Standard name What it measures
1 s'(t) velocity rate of change of position; speed and direction of motion
2 s''(t) acceleration rate of change of velocity; force-related quantity in Newton's second law
3 s'''(t) jerk rate of change of acceleration; felt physically as a sudden push or lurch
4 s(4)(t) snap (or jounce) specialised engineering use; rarely appears in standard calculus
5 s(5)(t) crackle named by analogy with snap; specialised engineering use
6 s(6)(t) pop named by analogy with snap and crackle; specialised engineering use

Patterns in Repeated Differentiation — Polynomials


COROLLARY
Polynomials terminate under repeated differentiation. Each differentiation reduces the degree by one, so a polynomial of degree nn reaches a constant after nn differentiations and becomes zero after n+1n + 1.

For f(x)=x5f(x) = x^5:

Patterns in Repeated Differentiation — Polynomials
f′(x)=5x4,f′′(x)=20x3,f′′′(x)=60x2,f(4)(x)=120x,f(5)(x)=120,f(6)(x)=0f'(x) = 5x^4, \quad f''(x) = 20x^3, \quad f'''(x) = 60x^2, \quad f^{(4)}(x) = 120x, \quad f^{(5)}(x) = 120, \quad f^{(6)}(x) = 0

The coefficient at the nnth derivative of xnx^n is n!=n(n−1)(n−2)⋯1n! = n(n-1)(n-2) \cdots 1, accumulated from the power rule applied nn times. Specifically, dndxn[xn]=n!\frac{d^n}{dx^n}[x^n] = n! and dkdxk[xn]=0\frac{d^k}{dx^k}[x^n] = 0 for all k>nk > n.

For a general polynomial p(x)=anxn+⋯+a1x+a0p(x) = a_n x^n + \cdots + a_1 x + a_0, the nnth derivative is n!⋅ann! \cdot a_n, a constant. This relationship becomes central in Taylor series, where the coefficient ana_n is recovered as f(n)(a)n!\frac{f^{(n)}(a)}{n!}.

Patterns in Repeated Differentiation — Exponentials


The natural exponential exe^x is unchanged by differentiation:

nth Derivative of Natural Exponential
dndxn[ex]=ex\frac{d^n}{dx^n}[e^x] = e^x
Learn more about this formula: nth Derivative of Natural Exponential →

Every derivative of exe^x is exe^x. The only functions with this property are the constant multiples CexCe^x (including the trivial f(x)=0f(x) = 0).

For the general exponential eaxe^{ax}, the chain rule introduces a factor of aa at each step:

nth Derivative of Scaled Exponential
dndxn[eax]=aneax\frac{d^n}{dx^n}[e^{ax}] = a^n e^{ax}
Learn more about this formula: nth Derivative of Scaled Exponential →


Pitfall: Using the chain-rule factor only once
Writing d3dx3[e2x]=2e2x\frac{d^3}{dx^3}[e^{2x}] = 2e^{2x} keeps the factor 22 from the first step only. Differentiating three times gives 4e2x4e^{2x} after the second step and 8e2x8e^{2x} after the third, so the answer is 8e2x8e^{2x}.

Each differentiation multiplies by aa. After nn differentiations, the accumulated constant is ana^n. This pattern appears in solutions to differential equations, where eaxe^{ax} satisfies equations whose characteristic root is aa.

For axa^x with arbitrary base: since ax=exln⁡aa^x = e^{x \ln a}, the nnth derivative is (ln⁡a)n⋅ax(\ln a)^n \cdot a^x. The factor ln⁡a\ln a replaces aa in the exponential pattern.

Patterns in Repeated Differentiation — Sine and Cosine


The derivatives of sin⁡x\sin x cycle with period four:

Patterns in Repeated Differentiation — Sine and Cosine
sin⁡x→cos⁡x→−sin⁡x→−cos⁡x→sin⁡x→⋯\sin x \to \cos x \to -\sin x \to -\cos x \to \sin x \to \cdots

The nnth derivative of sin⁡x\sin x depends on nmod  4n \mod 4:

Patterns in Repeated Differentiation — Sine and Cosine
dndxn[sin⁡x]={sin⁡xn≡0(mod4)cos⁡xn≡1(mod4)−sin⁡xn≡2(mod4)−cos⁡xn≡3(mod4)\frac{d^n}{dx^n}[\sin x] = \begin{cases} \sin x & n \equiv 0 \pmod{4} \\ \cos x & n \equiv 1 \pmod{4} \\ -\sin x & n \equiv 2 \pmod{4} \\ -\cos x & n \equiv 3 \pmod{4} \end{cases}

A compact formula captures all four cases: dndxn[sin⁡x]=sin⁡(x+nπ2)\frac{d^n}{dx^n}[\sin x] = \sin\left(x + \frac{n\pi}{2}\right). The same holds for cosine: dndxn[cos⁡x]=cos⁡(x+nπ2)\frac{d^n}{dx^n}[\cos x] = \cos\left(x + \frac{n\pi}{2}\right).

nth Derivative of Sine
dndxn[sin⁡x]=sin⁡ ⁣(x+nπ2)\frac{d^n}{dx^n}[\sin x] = \sin\!\left(x + \frac{n\pi}{2}\right)
Learn more about this formula: nth Derivative of Sine →

nth Derivative of Cosine
dndxn[cos⁡x]=cos⁡ ⁣(x+nπ2)\frac{d^n}{dx^n}[\cos x] = \cos\!\left(x + \frac{n\pi}{2}\right)
Learn more about this formula: nth Derivative of Cosine →


Pitfall: Dropping the minus sign
Taking the derivative of cos⁡x\cos x to be sin⁡x\sin x makes the cycle sin⁡x→cos⁡x→sin⁡x\sin x \to \cos x \to \sin x, of length two, and gives d2dx2[sin⁡x]=sin⁡x\frac{d^2}{dx^2}[\sin x] = \sin x. With (cos⁡x)′=−sin⁡x(\cos x)' = -\sin x the second derivative is −sin⁡x-\sin x, and the cycle closes only after four steps.

For sin⁡(ax)\sin(ax), the chain rule introduces a factor of aa per differentiation: dndxn[sin⁡(ax)]=ansin⁡(ax+nπ2)\frac{d^n}{dx^n}[\sin(ax)] = a^n \sin\left(ax + \frac{n\pi}{2}\right). The cycle in the trigonometric part persists; only the amplitude grows as ana^n.

This four-fold periodicity distinguishes trigonometric derivatives from polynomial derivatives (which terminate) and exponential derivatives (which replicate).
sin x and its derivative cos x: the derivative is the same wave shifted left by pi/2xy−4−3−2−11234567−2−112shift π/2sin xcos x = (sin x)′each derivative moves the wave π/2 to the leftfour shifts make a full period: the 4-cycle(sin x)′ = sin(x + π/2): each derivative shifts the wave by π/2
Differentiating sine is a shift

The curves sin x and its derivative cos x are the same wave, one a quarter period ahead of the other: the peak of sin x at x = π/2 sits at x = 0 on cos x. That is (sin x)′ = sin(x + π/2). Each further derivative moves the wave another π/2 to the left, so four of them move it a full period 2π and bring back sin x, which is the four-step cycle sin, cos, −sin, −cos.

For sin(ax) the shift is the same; only the height is multiplied by a at each step.

The nth Derivative of Specific Forms


Several standard functions have known closed-form nnth derivatives.

For f(x)=1xf(x) = \frac{1}{x}: rewriting as x−1x^{-1} and applying the power rule repeatedly gives

nth Derivative of Reciprocal
dndxn ⁣[1x]=(−1)n n!xn+1\frac{d^n}{dx^n}\!\left[\frac{1}{x}\right] = \frac{(-1)^n\, n!}{x^{n+1}}
Learn more about this formula: nth Derivative of Reciprocal →

Each differentiation multiplies by one more negative integer, producing the factorial and the alternating sign.

For f(x)=ln⁡xf(x) = \ln x: since f′(x)=x−1f'(x) = x^{-1}, the higher derivatives follow the pattern above shifted by one:

nth Derivative of Natural Logarithm
dndxn[ln⁡x]=(−1)n−1 (n−1)!xn\frac{d^n}{dx^n}[\ln x] = \frac{(-1)^{n-1}\, (n-1)!}{x^n}
Learn more about this formula: nth Derivative of Natural Logarithm →

For f(x)=xmf(x) = x^m where mm is a positive integer and n≤mn \leq m:

nth Derivative of Power
dndxn[xm]=m!(m−n)! xm−n(n≤m)\frac{d^n}{dx^n}[x^m] = \frac{m!}{(m-n)!}\, x^{m-n} \quad (n \leq m)
Learn more about this formula: nth Derivative of Power →


The coefficient m!(m−n)!\frac{m!}{(m-n)!} is the falling factorial, counting the multipliers accumulated over nn applications of the power rule.

Fact: Half a derivative brings in π\pi
With factorials extended to fractions, (12)!=π2\left(\frac{1}{2}\right)! = \frac{\sqrt{\pi}}{2}, and the formula gives d1/2dx1/2[x]=2xπ\frac{d^{1/2}}{dx^{1/2}}[x] = \frac{2\sqrt{x}}{\sqrt{\pi}}. Applying the same half-derivative once more gives exactly 11, the ordinary derivative of xx.

Once the pattern is written as a single formula, the order nn looks like any other number in it. The question of what a derivative of order 12\frac{1}{2} would mean was asked almost as soon as the notation existed: in 1695 L'Hôpital put it to Leibniz in a letter, and Leibniz answered that it led to a paradox from which useful consequences would one day be drawn. An answer needs factorials of numbers that are not whole, and the gamma function supplies them.

These closed-form expressions are useful for computing specific high-order derivatives without performing each differentiation step individually.

Higher-Order Derivatives and Taylor Series


The Taylor series of ff centered at x=ax = a is

Taylor Series
f(x)=∑n=0∞f(n)(a)n!(x−a)nf(x) = \sum_{n=0}^{\infty} \frac{f^{(n)}(a)}{n!} (x - a)^n
Learn more about this formula: Taylor Series →


Pitfall: Leaving out the factorials
Using f(n)(a)f^{(n)}(a) as the coefficient without dividing by n!n! turns the cubic Taylor polynomial of sin⁡x\sin x at 00 into x−x3x - x^3, which gives 0.3750.375 at x=0.5x = 0.5. With f′′′(0)3!=−16\frac{f'''(0)}{3!} = -\frac{1}{6} it is x−x36≈0.47917x - \frac{x^3}{6} \approx 0.47917, close to sin⁡0.5≈0.47943\sin 0.5 \approx 0.47943.

Each coefficient depends on a higher-order derivative evaluated at the center point aa. The zeroth derivative f(0)(a)=f(a)f^{(0)}(a) = f(a) gives the constant term. The first derivative gives the linear term. The second derivative gives the quadratic correction. Each successive term captures finer detail about how ff deviates from the lower-order approximation.

The Taylor polynomial of degree kk truncates the series after k+1k + 1 terms, providing a polynomial approximation to ff near aa. For well-behaved functions such as sin⁡x\sin x, the approximation improves with kk—more derivatives typically mean a closer fit near aa, often over a wider interval.

The connection between higher-order derivatives and Taylor series gives these derivatives their deepest significance: the complete collection {f(n)(a)}n=0∞\{f^{(n)}(a)\}_{n=0}^{\infty} determines ff locally (for analytic functions). For such functions, knowing all derivatives at a single point reconstructs the entire function in a neighborhood of that point.
Taylor polynomials of sin x at 0 of degree 1, 3 and 5 fit on wider and wider intervalsxy−4−3−2−11234−2−112sin xdegree 1 (dashed)degree 3 (navy)degree 5 (amber)More derivatives at 0, closer fit: degrees 1, 3, 5 for sin x
Taylor polynomials of sin x at 0

The Taylor polynomials of sin x at 0 use the derivatives 0, 1, 0, −1, 0, 1, … there. Degree 1 is the line y = x, which follows the curve only near 0. Degree 3, x − x³/6, stays close until about ±1.5; degree 5 adds x⁵/120 and holds on to about ±2.5. Each additional derivative used at the single point 0 widens the stretch where the polynomial matches sin x.

Only odd powers appear because the even-order derivatives of sin x at 0 are all 0.
For analytic functions, the derivatives at one point rebuild the whole function around it.

Existence and Smoothness Classes


A function may be differentiable once but not twice. The function f(x)=x∣x∣f(x) = x|x| has f′(x)=2∣x∣f'(x) = 2|x|, which is continuous but not differentiable at x=0x = 0. So ff is in class C1C^1 (continuously differentiable) but not C2C^2.

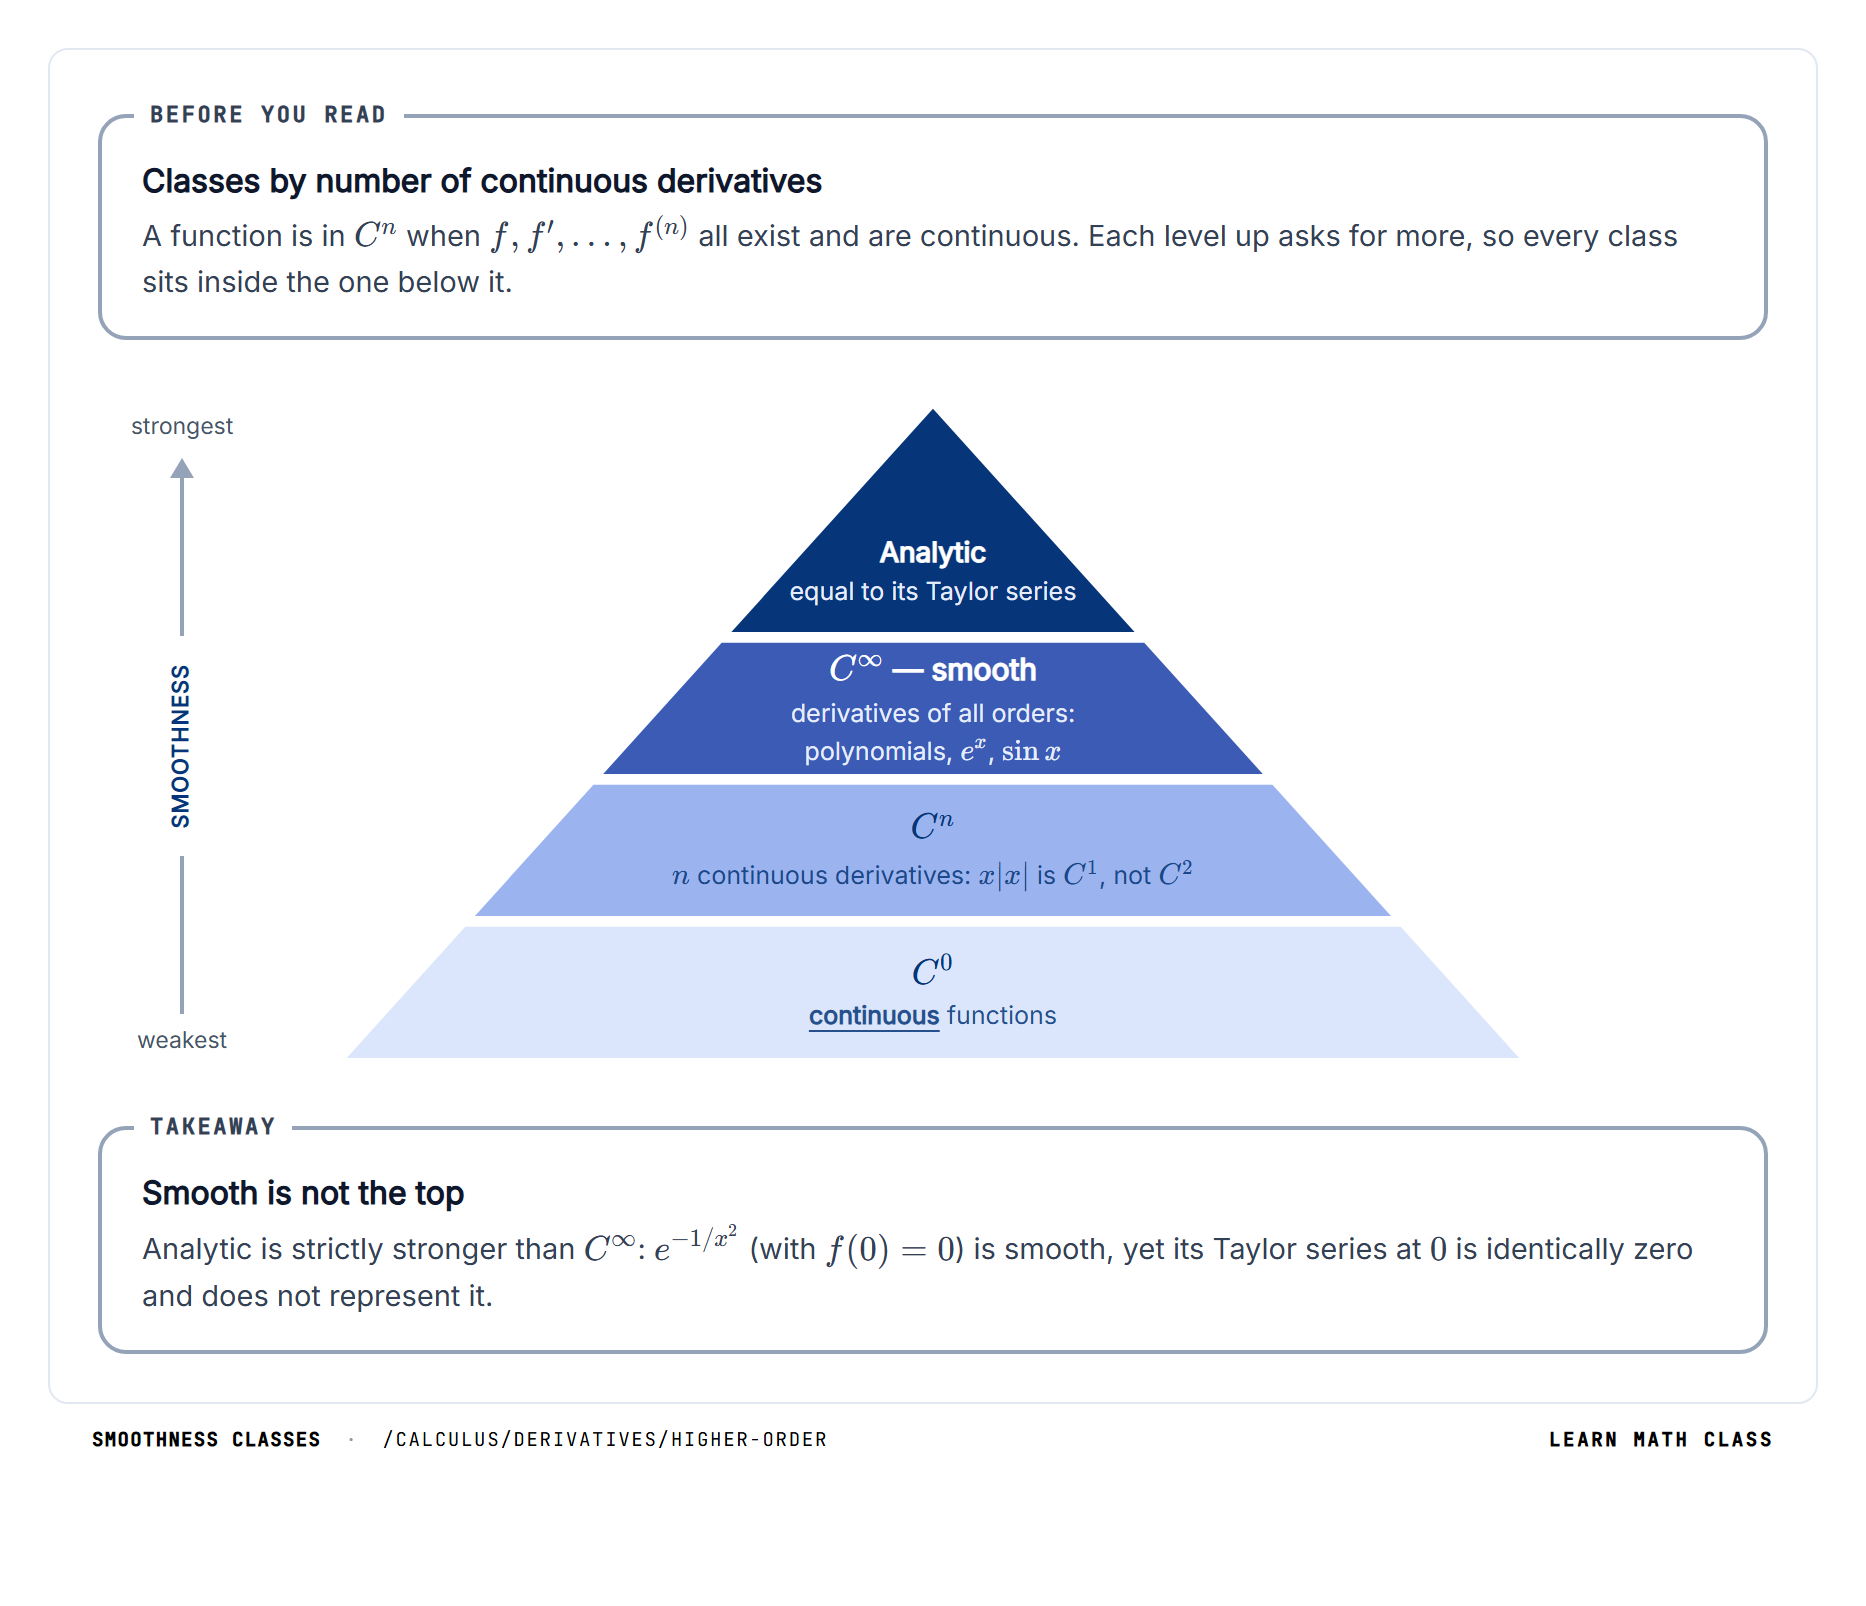
The smoothness classes organize functions by how many continuous derivatives they possess. A function belongs to CnC^n if f,f′,f′′,…,f(n)f, f', f'', \ldots, f^{(n)} all exist and are continuous. Class C0C^0 is simply continuous functions. Class C∞C^\infty consists of infinitely differentiable functions—called smooth functions—where derivatives of all orders exist and are continuous.

Polynomials, exe^x, sin⁡x\sin x, cos⁡x\cos x, and their compositions are all C∞C^\infty. Piecewise functions typically belong to a finite CnC^n class determined by how smoothly the pieces join at their boundaries: matching values gives C0C^0, matching first derivatives gives C1C^1, and so on.

There exist functions that are C∞C^\infty but not analytic—their Taylor series either diverges or converges to something other than the function itself. The standard example is f(x)=e−1/x2f(x) = e^{-1/x^2} for x≠0x \neq 0 and f(0)=0f(0) = 0: every derivative at x=0x = 0 is zero, so the Taylor series is identically zero, yet the function is not zero away from the origin.

THEOREM
Smooth does not automatically mean representable by a power series.

The table below lays out the main tiers — C⁰, the general Cⁿ, C∞, and the strictly stronger analytic class — alongside what each requires and characteristic examples.
x|x| looks smooth, but its derivative 2|x| has a corner at 0: C1 but not C2xy−2−112−3−2−112345f(x) = x|x|f′(x) = 2|x|corner in f′: f″(0) does not existx|x| has a continuous derivative with a corner: class C¹, not C²
Smooth to the eye, not twice differentiable

The section’s f(x) = x|x| bends smoothly through the origin; it is x² on the right and −x² on the left. Its derivative f′(x) = 2|x| is continuous, but it is a V with a corner at 0, and a corner has no derivative. So f′′(0) does not exist: f is in C¹ but not in C².

Joining x² and −x² matches values and first derivatives at 0, but not second derivatives, 2 and −2.
Class What it requires Examples
C0 f is continuous (no derivatives required) |x|; piecewise functions whose pieces match values at the boundary
Cn f, f', f'', … , f(n) all exist and are continuous x|x| belongs to C1 but not C2
C∞  (smooth) derivatives of all orders exist and are continuous polynomials, ex, sin x, cos x, and their compositions
Analytic C∞, and the Taylor series at every point converges to f near that point most elementary functions; counterexample f(x) = e−1 ⁄ x² (extended by f(0) = 0) is C∞ but not analytic at 0
DownloadPNG2×PDF
Before you read
Classes by number of continuous derivatives
A function is in CnC^n when f,f′,…,f(n)f, f', \ldots, f^{(n)} all exist and are continuous. Each level up asks for more, so every class sits inside the one below it.
strongestsmoothnessweakest
Analyticequal to its Taylor series
C∞C^\infty — smoothderivatives of all orders: polynomials, exe^x, sin⁡x\sin x
CnC^nnn continuous derivatives: x∣x∣x|x| is C1C^1, not C2C^2
C0C^0continuous functions
Takeaway
Smooth is not the top
Analytic is strictly stronger than C∞C^\infty: e−1/x2e^{-1/x^2} (with f(0)=0f(0) = 0) is smooth, yet its Taylor series at 00 is identically zero and does not represent it.
Smoothness classes·/calculus/derivatives/higher-orderLearn Math Class

nth Derivatives at a Glance


Different function families behave very differently under repeated differentiation: polynomials terminate, exponentials replicate, and trigonometric functions cycle. The table below collects the closed-form nth derivative for each standard function discussed above into a single reference card, with a brief note on what drives the pattern.
Function nth derivative Note
xm  (m a positive integer) m! ⁄ (m − n)! · xm − n  for n ≤ m falling factorial; becomes the constant m! when n = m, and zero for n > m
Polynomial of degree m m! · am  (when n = m);  0 (when n > m) terminates after m + 1 differentiations
1 ⁄ x (−1)n · n! ⁄ xn + 1 alternating sign accompanied by factorial growth in the numerator
ln x (−1)n − 1 · (n − 1)! ⁄ xn  (n ≥ 1) the 1 ⁄ x pattern shifted by one order, since (ln x)' = 1 ⁄ x
ex ex self-replicating; together with its constant multiples Cex, the only functions with this property
ea x an · ea x each differentiation multiplies by a, so the constant accumulates as an
ax (ln a)n · ax since ax = ex · ln a, ln a takes the role of the multiplier
sin x sin(x + n π ⁄ 2) four-fold cycle: sin → cos → −sin → −cos → sin
cos x cos(x + n π ⁄ 2) same four-fold cycle, starting from cosine
sin(a x) an · sin(a x + n π ⁄ 2) trigonometric cycle persists; amplitude grows as an

Common Pitfalls


Five mistakes cause many wrong answers with higher-order derivatives. Each is marked by a box where it happens in the sections above; here each is worked through in full, with the wrong and the right working side by side.

Squaring the first derivative

The second derivative is computed as the square of the first: f′′(x)f''(x) is read as (f′(x))2(f'(x))^2, or d2ydx2\frac{d^2y}{dx^2} as (dydx)2\left(\frac{dy}{dx}\right)^2.

Wrong working: for y=x3y = x^3, dydx=3x2\frac{dy}{dx} = 3x^2, so d2ydx2=(3x2)2=9x4\frac{d^2y}{dx^2} = (3x^2)^2 = 9x^4. This is never negative, so the curve would be concave up everywhere.

Right working: differentiate 3x23x^2 once more, d2ydx2=6x\frac{d^2y}{dx^2} = 6x. At x=−1x = -1 it is −6-6, so the curve bends down to the left of 00 and up to the right, as the first section shows.

Why it happens: in d2ydx2\frac{d^2y}{dx^2} the 22 looks like an exponent, and in f′′f'' the second prime looks like a repeat of the first; both suggest a product of two first derivatives.

How to check: compare the degrees. Each differentiation lowers the degree of a polynomial by one, so the second derivative of x3x^3 must have degree 11, not 44.

Reading negative acceleration as slowing down

The sign of s′′(t)s''(t) alone is taken to decide whether an object speeds up or slows down: a negative acceleration is read as braking, a positive one as speeding up.

Wrong working: for s(t)=−t2s(t) = -t^2, s′′(t)=−2<0s''(t) = -2 < 0, so the object is slowing down.

Right working: the velocity is s′(t)=−2ts'(t) = -2t, and for t>0t > 0 the speed is ∣s′(t)∣=2t|s'(t)| = 2t. At t=1t = 1 the speed is 22, at t=2t = 2 it is 44: the object speeds up. Velocity and acceleration are both negative, and when they have the same sign the speed grows.

Why it happens: in everyday speech "acceleration" means speeding up and "deceleration" slowing down. In calculus a negative acceleration only says that the velocity decreases, and a negative velocity that decreases gets larger in size.

How to check: compare the signs of s′(t)s'(t) and s′′(t)s''(t) at the moment in question, or compute the speed ∣s′(t)∣|s'(t)| at two nearby times.

Using the chain-rule factor only once

When eaxe^{ax} is differentiated several times, the factor aa from the chain rule is written once, as if it appeared only at the first step.

Wrong working: d3dx3[e2x]=2e2x\frac{d^3}{dx^3}[e^{2x}] = 2e^{2x}.

Right working: each step applies the chain rule again. ddx[e2x]=2e2x\frac{d}{dx}[e^{2x}] = 2e^{2x}, d2dx2[e2x]=4e2x\frac{d^2}{dx^2}[e^{2x}] = 4e^{2x}, d3dx3[e2x]=8e2x\frac{d^3}{dx^3}[e^{2x}] = 8e^{2x}, which is 23e2x2^3 e^{2x}, as the formula aneaxa^n e^{ax} says.

Why it happens: after the first step, 2e2x2e^{2x} looks like a constant times an exponential, and the exponential is then treated like exe^x, whose derivative is itself.

How to check: count the factors. Three differentiations bring in three chain-rule factors of 22, so the coefficient must be 2⋅2⋅2=82 \cdot 2 \cdot 2 = 8. The same count for axa^x gives (ln⁡a)n(\ln a)^n.

Dropping the minus sign

The derivative of cos⁡x\cos x is taken to be sin⁡x\sin x instead of −sin⁡x-\sin x. The error is carried into every later step, and the cycle comes out with the wrong length.

Wrong working: sin⁡x→cos⁡x→sin⁡x→cos⁡x\sin x \to \cos x \to \sin x \to \cos x, so d2dx2[sin⁡x]=sin⁡x\frac{d^2}{dx^2}[\sin x] = \sin x and d3dx3[sin⁡x]=cos⁡x\frac{d^3}{dx^3}[\sin x] = \cos x.

Right working: sin⁡x→cos⁡x→−sin⁡x→−cos⁡x→sin⁡x\sin x \to \cos x \to -\sin x \to -\cos x \to \sin x. So d2dx2[sin⁡x]=−sin⁡x\frac{d^2}{dx^2}[\sin x] = -\sin x, d3dx3[sin⁡x]=−cos⁡x\frac{d^3}{dx^3}[\sin x] = -\cos x, and the cycle closes after four steps.

Why it happens: the derivative of sin⁡x\sin x has no minus sign, and the derivative of cos⁡x\cos x is remembered by symmetry with it.

How to check: use the compact formula sin⁡(x+nπ2)\sin\left(x + \frac{n\pi}{2}\right); for n=2n = 2 it gives sin⁡(x+π)=−sin⁡x\sin(x + \pi) = -\sin x. Or test one point: sin⁡x\sin x has a maximum at x=π2x = \frac{\pi}{2}, so its second derivative cannot be positive there, and −sin⁡π2=−1-\sin\frac{\pi}{2} = -1 is negative.

Leaving out the factorials

In the Taylor series, the coefficient of (x−a)n(x - a)^n is taken to be f(n)(a)f^{(n)}(a), without the division by n!n!.

Wrong working: for sin⁡x\sin x at a=0a = 0, the values f(0),f′(0),f′′(0),f′′′(0)f(0), f'(0), f''(0), f'''(0) are 0,1,0,−10, 1, 0, -1, so the cubic Taylor polynomial is x−x3x - x^3. At x=0.5x = 0.5 it gives 0.3750.375.

Right working: divide each derivative by n!n!. The cubic term is −13!x3=−x36\frac{-1}{3!}x^3 = -\frac{x^3}{6}, and the polynomial is x−x36x - \frac{x^3}{6}. At x=0.5x = 0.5 it gives 0.5−0.02083≈0.479170.5 - 0.02083 \approx 0.47917, while sin⁡0.5≈0.47943\sin 0.5 \approx 0.47943.

Why it happens: the first two terms, f(a)f(a) and f′(a)(x−a)f'(a)(x - a), show no division, because 0!=1!=10! = 1! = 1, and the pattern seems to continue without it.

How to check: differentiate the polynomial nn times at the center; it must give back f(n)(a)f^{(n)}(a). The third derivative of x−x3x - x^3 is −6-6, not f′′′(0)=−1f'''(0) = -1; the third derivative of x−x36x - \frac{x^3}{6} is −1-1.

Higher-Order Derivatives FAQ

Why is the nth derivative written f⁽ⁿ⁾ with parentheses?

+
Because the superscript slot is already crowded. Without parentheses, fⁿ reads as a power, f∘ⁿ is n-fold composition, and f⁻¹ is the inverse — three other meanings competing for the same position. The parentheses mark the number as a derivative count and nothing else. Primes handle orders one through three; past that they stop being countable.Read more →

Why is the second derivative written d²y/dx² and not d²y/d²x?

+
Because the two exponents count different things. In the numerator, d² records that the operator d has been applied twice to y. In the denominator, dx² is really (dx)² — the increment dx squared, from the dimensional bookkeeping. The whole symbol is one operator applied to y, not a fraction of d²y over dx².Read more →

What is jerk in calculus?

+
Jerk is the third derivative of position with respect to time — the rate at which acceleration changes. You feel it as a sudden lurch rather than as speed or force, which is why elevator, roller-coaster, and vehicle design all work to keep it small. The fourth, fifth, and sixth derivatives are sometimes called snap, crackle, and pop.Read more →

What is the nth derivative of 1/x and ln x?

+
For 1/x the nth derivative is (−1)ⁿ·n!/x^(n+1); for ln x it is (−1)^(n−1)·(n−1)!/xⁿ. The two are the same pattern shifted by one step, because the first derivative of ln x is 1/x. Each differentiation multiplies by one more negative integer, which is where the factorial and the alternating sign both come from.Read more →

Is every smooth function equal to its Taylor series?

+
No. A function can have derivatives of every order and still not be analytic. The standard example is f(x) = e^(−1/x²) with f(0) = 0: every derivative at the origin is zero, so its Taylor series there is identically zero, yet the function is positive everywhere else. Smooth guarantees the series exists, not that it converges to f.Read more →